Start
This commit is contained in:

@@ -0,0 +1 @@
|
||||
ssh-zugang-raspberry-pi.txt
|
||||
@@ -0,0 +1,2 @@
|
||||
*.pyc
|
||||
config/exomy.yaml
|
||||
@@ -0,0 +1,203 @@
|
||||
cmake_minimum_required(VERSION 2.8.3)
|
||||
project(exomy)
|
||||
|
||||
## Compile as C++11, supported in ROS Kinetic and newer
|
||||
# add_compile_options(-std=c++11)
|
||||
|
||||
## Find catkin macros and libraries
|
||||
## if COMPONENTS list like find_package(catkin REQUIRED COMPONENTS xyz)
|
||||
## is used, also find other catkin packages
|
||||
find_package(catkin REQUIRED COMPONENTS
|
||||
rospy
|
||||
std_msgs
|
||||
sensor_msgs
|
||||
message_generation
|
||||
)
|
||||
|
||||
## System dependencies are found with CMake's conventions
|
||||
# find_package(Boost REQUIRED COMPONENTS system)
|
||||
# find_package(python-rpi.gpio REQUIRED)
|
||||
|
||||
|
||||
## Uncomment this if the package has a setup.py. This macro ensures
|
||||
## modules and global scripts declared therein get installed
|
||||
## See http://ros.org/doc/api/catkin/html/user_guide/setup_dot_py.html
|
||||
# catkin_python_setup()
|
||||
|
||||
################################################
|
||||
## Declare ROS messages, services and actions ##
|
||||
################################################
|
||||
|
||||
## To declare and build messages, services or actions from within this
|
||||
## package, follow these steps:
|
||||
## * Let MSG_DEP_SET be the set of packages whose message types you use in
|
||||
## your messages/services/actions (e.g. std_msgs, actionlib_msgs, ...).
|
||||
## * In the file package.xml:
|
||||
## * add a build_depend tag for "message_generation"
|
||||
## * add a build_depend and a exec_depend tag for each package in MSG_DEP_SET
|
||||
## * If MSG_DEP_SET isn't empty the following dependency has been pulled in
|
||||
## but can be declared for certainty nonetheless:
|
||||
## * add a exec_depend tag for "message_runtime"
|
||||
## * In this file (CMakeLists.txt):
|
||||
## * add "message_generation" and every package in MSG_DEP_SET to
|
||||
## find_package(catkin REQUIRED COMPONENTS ...)
|
||||
## * add "message_runtime" and every package in MSG_DEP_SET to
|
||||
## catkin_package(CATKIN_DEPENDS ...)
|
||||
## * uncomment the add_*_files sections below as needed
|
||||
## and list every .msg/.srv/.action file to be processed
|
||||
## * uncomment the generate_messages entry below
|
||||
## * add every package in MSG_DEP_SET to generate_messages(DEPENDENCIES ...)
|
||||
|
||||
## Generate messages in the 'msg' folder
|
||||
add_message_files(
|
||||
FILES
|
||||
RoverCommand.msg
|
||||
MotorCommands.msg
|
||||
Screen.msg
|
||||
)
|
||||
## Generate services in the 'srv' folder
|
||||
# add_service_files(
|
||||
# FILES
|
||||
# Service1.srv
|
||||
# Service2.srv
|
||||
# )
|
||||
|
||||
## Generate actions in the 'action' folder
|
||||
# add_action_files(
|
||||
# FILES
|
||||
# Action1.action
|
||||
# Action2.action
|
||||
# )
|
||||
|
||||
## Generate added messages and services with any dependencies listed here
|
||||
generate_messages(
|
||||
DEPENDENCIES
|
||||
sensor_msgs
|
||||
std_msgs
|
||||
)
|
||||
|
||||
################################################
|
||||
## Declare ROS dynamic reconfigure parameters ##
|
||||
################################################
|
||||
|
||||
## To declare and build dynamic reconfigure parameters within this
|
||||
## package, follow these steps:
|
||||
## * In the file package.xml:
|
||||
## * add a build_depend and a exec_depend tag for "dynamic_reconfigure"
|
||||
## * In this file (CMakeLists.txt):
|
||||
## * add "dynamic_reconfigure" to
|
||||
## find_package(catkin REQUIRED COMPONENTS ...)
|
||||
## * uncomment the "generate_dynamic_reconfigure_options" section below
|
||||
## and list every .cfg file to be processed
|
||||
|
||||
## Generate dynamic reconfigure parameters in the 'cfg' folder
|
||||
# generate_dynamic_reconfigure_options(
|
||||
# cfg/DynReconf1.cfg
|
||||
# cfg/DynReconf2.cfg
|
||||
# )
|
||||
|
||||
###################################
|
||||
## catkin specific configuration ##
|
||||
###################################
|
||||
## The catkin_package macro generates cmake config files for your package
|
||||
## Declare things to be passed to dependent projects
|
||||
## INCLUDE_DIRS: uncomment this if your package contains header files
|
||||
## LIBRARIES: libraries you create in this project that dependent projects also need
|
||||
## CATKIN_DEPENDS: catkin_packages dependent projects also need
|
||||
## DEPENDS: system dependencies of this project that dependent projects also need
|
||||
catkin_package(
|
||||
# INCLUDE_DIRS include
|
||||
# LIBRARIES exomy
|
||||
CATKIN_DEPENDS rospy std_msgs sensor_msgs message_runtime
|
||||
# DEPENDS python-rpi.gpio
|
||||
)
|
||||
|
||||
###########
|
||||
## Build ##
|
||||
###########
|
||||
|
||||
## Specify additional locations of header files
|
||||
## Your package locations should be listed before other locations
|
||||
include_directories(
|
||||
# include
|
||||
${catkin_INCLUDE_DIRS}
|
||||
)
|
||||
|
||||
## Declare a C++ library
|
||||
# add_library(${PROJECT_NAME}
|
||||
# src/${PROJECT_NAME}/exomy.cpp
|
||||
# )
|
||||
|
||||
## Add cmake target dependencies of the library
|
||||
## as an example, code may need to be generated before libraries
|
||||
## either from message generation or dynamic reconfigure
|
||||
# add_dependencies(${PROJECT_NAME} ${${PROJECT_NAME}_EXPORTED_TARGETS} ${catkin_EXPORTED_TARGETS})
|
||||
|
||||
## Declare a C++ executable
|
||||
## With catkin_make all packages are built within a single CMake context
|
||||
## The recommended prefix ensures that target names across packages don't collide
|
||||
# add_executable(${PROJECT_NAME}_node src/exomy_node.cpp)
|
||||
|
||||
## Rename C++ executable without prefix
|
||||
## The above recommended prefix causes long target names, the following renames the
|
||||
## target back to the shorter version for ease of user use
|
||||
## e.g. "rosrun someones_pkg node" instead of "rosrun someones_pkg someones_pkg_node"
|
||||
# set_target_properties(${PROJECT_NAME}_node PROPERTIES OUTPUT_NAME node PREFIX "")
|
||||
|
||||
## Add cmake target dependencies of the executable
|
||||
## same as for the library above
|
||||
# add_dependencies(${PROJECT_NAME}_node ${${PROJECT_NAME}_EXPORTED_TARGETS} ${catkin_EXPORTED_TARGETS})
|
||||
|
||||
## Specify libraries to link a library or executable target against
|
||||
# target_link_libraries(${PROJECT_NAME}_node
|
||||
# ${catkin_LIBRARIES}
|
||||
# ${python-rpi.gpio_LIBRARIES}
|
||||
# )
|
||||
|
||||
#############
|
||||
## Install ##
|
||||
#############
|
||||
|
||||
# all install targets should use catkin DESTINATION variables
|
||||
# See http://ros.org/doc/api/catkin/html/adv_user_guide/variables.html
|
||||
|
||||
## Mark executable scripts (Python etc.) for installation
|
||||
## in contrast to setup.py, you can choose the destination
|
||||
# install(PROGRAMS
|
||||
# scripts/my_python_script
|
||||
# DESTINATION ${CATKIN_PACKAGE_BIN_DESTINATION}
|
||||
# )
|
||||
|
||||
## Mark executables and/or libraries for installation
|
||||
# install(TARGETS ${PROJECT_NAME} ${PROJECT_NAME}_node
|
||||
# ARCHIVE DESTINATION ${CATKIN_PACKAGE_LIB_DESTINATION}
|
||||
# LIBRARY DESTINATION ${CATKIN_PACKAGE_LIB_DESTINATION}
|
||||
# RUNTIME DESTINATION ${CATKIN_PACKAGE_BIN_DESTINATION}
|
||||
# )
|
||||
|
||||
## Mark cpp header files for installation
|
||||
# install(DIRECTORY include/${PROJECT_NAME}/
|
||||
# DESTINATION ${CATKIN_PACKAGE_INCLUDE_DESTINATION}
|
||||
# FILES_MATCHING PATTERN "*.h"
|
||||
# PATTERN ".svn" EXCLUDE
|
||||
# )
|
||||
|
||||
## Mark other files for installation (e.g. launch and bag files, etc.)
|
||||
# install(FILES
|
||||
# # myfile1
|
||||
# # myfile2
|
||||
# DESTINATION ${CATKIN_PACKAGE_SHARE_DESTINATION}
|
||||
# )
|
||||
|
||||
#############
|
||||
## Testing ##
|
||||
#############
|
||||
|
||||
## Add gtest based cpp test target and link libraries
|
||||
# catkin_add_gtest(${PROJECT_NAME}-test test/test_exomy.cpp)
|
||||
# if(TARGET ${PROJECT_NAME}-test)
|
||||
# target_link_libraries(${PROJECT_NAME}-test ${PROJECT_NAME})
|
||||
# endif()
|
||||
|
||||
## Add folders to be run by python nosetests
|
||||
# catkin_add_nosetests(test)
|
||||
@@ -0,0 +1,674 @@
|
||||
GNU GENERAL PUBLIC LICENSE
|
||||
Version 3, 29 June 2007
|
||||
|
||||
Copyright (C) 2007 Free Software Foundation, Inc. <https://fsf.org/>
|
||||
Everyone is permitted to copy and distribute verbatim copies
|
||||
of this license document, but changing it is not allowed.
|
||||
|
||||
Preamble
|
||||
|
||||
The GNU General Public License is a free, copyleft license for
|
||||
software and other kinds of works.
|
||||
|
||||
The licenses for most software and other practical works are designed
|
||||
to take away your freedom to share and change the works. By contrast,
|
||||
the GNU General Public License is intended to guarantee your freedom to
|
||||
share and change all versions of a program--to make sure it remains free
|
||||
software for all its users. We, the Free Software Foundation, use the
|
||||
GNU General Public License for most of our software; it applies also to
|
||||
any other work released this way by its authors. You can apply it to
|
||||
your programs, too.
|
||||
|
||||
When we speak of free software, we are referring to freedom, not
|
||||
price. Our General Public Licenses are designed to make sure that you
|
||||
have the freedom to distribute copies of free software (and charge for
|
||||
them if you wish), that you receive source code or can get it if you
|
||||
want it, that you can change the software or use pieces of it in new
|
||||
free programs, and that you know you can do these things.
|
||||
|
||||
To protect your rights, we need to prevent others from denying you
|
||||
these rights or asking you to surrender the rights. Therefore, you have
|
||||
certain responsibilities if you distribute copies of the software, or if
|
||||
you modify it: responsibilities to respect the freedom of others.
|
||||
|
||||
For example, if you distribute copies of such a program, whether
|
||||
gratis or for a fee, you must pass on to the recipients the same
|
||||
freedoms that you received. You must make sure that they, too, receive
|
||||
or can get the source code. And you must show them these terms so they
|
||||
know their rights.
|
||||
|
||||
Developers that use the GNU GPL protect your rights with two steps:
|
||||
(1) assert copyright on the software, and (2) offer you this License
|
||||
giving you legal permission to copy, distribute and/or modify it.
|
||||
|
||||
For the developers' and authors' protection, the GPL clearly explains
|
||||
that there is no warranty for this free software. For both users' and
|
||||
authors' sake, the GPL requires that modified versions be marked as
|
||||
changed, so that their problems will not be attributed erroneously to
|
||||
authors of previous versions.
|
||||
|
||||
Some devices are designed to deny users access to install or run
|
||||
modified versions of the software inside them, although the manufacturer
|
||||
can do so. This is fundamentally incompatible with the aim of
|
||||
protecting users' freedom to change the software. The systematic
|
||||
pattern of such abuse occurs in the area of products for individuals to
|
||||
use, which is precisely where it is most unacceptable. Therefore, we
|
||||
have designed this version of the GPL to prohibit the practice for those
|
||||
products. If such problems arise substantially in other domains, we
|
||||
stand ready to extend this provision to those domains in future versions
|
||||
of the GPL, as needed to protect the freedom of users.
|
||||
|
||||
Finally, every program is threatened constantly by software patents.
|
||||
States should not allow patents to restrict development and use of
|
||||
software on general-purpose computers, but in those that do, we wish to
|
||||
avoid the special danger that patents applied to a free program could
|
||||
make it effectively proprietary. To prevent this, the GPL assures that
|
||||
patents cannot be used to render the program non-free.
|
||||
|
||||
The precise terms and conditions for copying, distribution and
|
||||
modification follow.
|
||||
|
||||
TERMS AND CONDITIONS
|
||||
|
||||
0. Definitions.
|
||||
|
||||
"This License" refers to version 3 of the GNU General Public License.
|
||||
|
||||
"Copyright" also means copyright-like laws that apply to other kinds of
|
||||
works, such as semiconductor masks.
|
||||
|
||||
"The Program" refers to any copyrightable work licensed under this
|
||||
License. Each licensee is addressed as "you". "Licensees" and
|
||||
"recipients" may be individuals or organizations.
|
||||
|
||||
To "modify" a work means to copy from or adapt all or part of the work
|
||||
in a fashion requiring copyright permission, other than the making of an
|
||||
exact copy. The resulting work is called a "modified version" of the
|
||||
earlier work or a work "based on" the earlier work.
|
||||
|
||||
A "covered work" means either the unmodified Program or a work based
|
||||
on the Program.
|
||||
|
||||
To "propagate" a work means to do anything with it that, without
|
||||
permission, would make you directly or secondarily liable for
|
||||
infringement under applicable copyright law, except executing it on a
|
||||
computer or modifying a private copy. Propagation includes copying,
|
||||
distribution (with or without modification), making available to the
|
||||
public, and in some countries other activities as well.
|
||||
|
||||
To "convey" a work means any kind of propagation that enables other
|
||||
parties to make or receive copies. Mere interaction with a user through
|
||||
a computer network, with no transfer of a copy, is not conveying.
|
||||
|
||||
An interactive user interface displays "Appropriate Legal Notices"
|
||||
to the extent that it includes a convenient and prominently visible
|
||||
feature that (1) displays an appropriate copyright notice, and (2)
|
||||
tells the user that there is no warranty for the work (except to the
|
||||
extent that warranties are provided), that licensees may convey the
|
||||
work under this License, and how to view a copy of this License. If
|
||||
the interface presents a list of user commands or options, such as a
|
||||
menu, a prominent item in the list meets this criterion.
|
||||
|
||||
1. Source Code.
|
||||
|
||||
The "source code" for a work means the preferred form of the work
|
||||
for making modifications to it. "Object code" means any non-source
|
||||
form of a work.
|
||||
|
||||
A "Standard Interface" means an interface that either is an official
|
||||
standard defined by a recognized standards body, or, in the case of
|
||||
interfaces specified for a particular programming language, one that
|
||||
is widely used among developers working in that language.
|
||||
|
||||
The "System Libraries" of an executable work include anything, other
|
||||
than the work as a whole, that (a) is included in the normal form of
|
||||
packaging a Major Component, but which is not part of that Major
|
||||
Component, and (b) serves only to enable use of the work with that
|
||||
Major Component, or to implement a Standard Interface for which an
|
||||
implementation is available to the public in source code form. A
|
||||
"Major Component", in this context, means a major essential component
|
||||
(kernel, window system, and so on) of the specific operating system
|
||||
(if any) on which the executable work runs, or a compiler used to
|
||||
produce the work, or an object code interpreter used to run it.
|
||||
|
||||
The "Corresponding Source" for a work in object code form means all
|
||||
the source code needed to generate, install, and (for an executable
|
||||
work) run the object code and to modify the work, including scripts to
|
||||
control those activities. However, it does not include the work's
|
||||
System Libraries, or general-purpose tools or generally available free
|
||||
programs which are used unmodified in performing those activities but
|
||||
which are not part of the work. For example, Corresponding Source
|
||||
includes interface definition files associated with source files for
|
||||
the work, and the source code for shared libraries and dynamically
|
||||
linked subprograms that the work is specifically designed to require,
|
||||
such as by intimate data communication or control flow between those
|
||||
subprograms and other parts of the work.
|
||||
|
||||
The Corresponding Source need not include anything that users
|
||||
can regenerate automatically from other parts of the Corresponding
|
||||
Source.
|
||||
|
||||
The Corresponding Source for a work in source code form is that
|
||||
same work.
|
||||
|
||||
2. Basic Permissions.
|
||||
|
||||
All rights granted under this License are granted for the term of
|
||||
copyright on the Program, and are irrevocable provided the stated
|
||||
conditions are met. This License explicitly affirms your unlimited
|
||||
permission to run the unmodified Program. The output from running a
|
||||
covered work is covered by this License only if the output, given its
|
||||
content, constitutes a covered work. This License acknowledges your
|
||||
rights of fair use or other equivalent, as provided by copyright law.
|
||||
|
||||
You may make, run and propagate covered works that you do not
|
||||
convey, without conditions so long as your license otherwise remains
|
||||
in force. You may convey covered works to others for the sole purpose
|
||||
of having them make modifications exclusively for you, or provide you
|
||||
with facilities for running those works, provided that you comply with
|
||||
the terms of this License in conveying all material for which you do
|
||||
not control copyright. Those thus making or running the covered works
|
||||
for you must do so exclusively on your behalf, under your direction
|
||||
and control, on terms that prohibit them from making any copies of
|
||||
your copyrighted material outside their relationship with you.
|
||||
|
||||
Conveying under any other circumstances is permitted solely under
|
||||
the conditions stated below. Sublicensing is not allowed; section 10
|
||||
makes it unnecessary.
|
||||
|
||||
3. Protecting Users' Legal Rights From Anti-Circumvention Law.
|
||||
|
||||
No covered work shall be deemed part of an effective technological
|
||||
measure under any applicable law fulfilling obligations under article
|
||||
11 of the WIPO copyright treaty adopted on 20 December 1996, or
|
||||
similar laws prohibiting or restricting circumvention of such
|
||||
measures.
|
||||
|
||||
When you convey a covered work, you waive any legal power to forbid
|
||||
circumvention of technological measures to the extent such circumvention
|
||||
is effected by exercising rights under this License with respect to
|
||||
the covered work, and you disclaim any intention to limit operation or
|
||||
modification of the work as a means of enforcing, against the work's
|
||||
users, your or third parties' legal rights to forbid circumvention of
|
||||
technological measures.
|
||||
|
||||
4. Conveying Verbatim Copies.
|
||||
|
||||
You may convey verbatim copies of the Program's source code as you
|
||||
receive it, in any medium, provided that you conspicuously and
|
||||
appropriately publish on each copy an appropriate copyright notice;
|
||||
keep intact all notices stating that this License and any
|
||||
non-permissive terms added in accord with section 7 apply to the code;
|
||||
keep intact all notices of the absence of any warranty; and give all
|
||||
recipients a copy of this License along with the Program.
|
||||
|
||||
You may charge any price or no price for each copy that you convey,
|
||||
and you may offer support or warranty protection for a fee.
|
||||
|
||||
5. Conveying Modified Source Versions.
|
||||
|
||||
You may convey a work based on the Program, or the modifications to
|
||||
produce it from the Program, in the form of source code under the
|
||||
terms of section 4, provided that you also meet all of these conditions:
|
||||
|
||||
a) The work must carry prominent notices stating that you modified
|
||||
it, and giving a relevant date.
|
||||
|
||||
b) The work must carry prominent notices stating that it is
|
||||
released under this License and any conditions added under section
|
||||
7. This requirement modifies the requirement in section 4 to
|
||||
"keep intact all notices".
|
||||
|
||||
c) You must license the entire work, as a whole, under this
|
||||
License to anyone who comes into possession of a copy. This
|
||||
License will therefore apply, along with any applicable section 7
|
||||
additional terms, to the whole of the work, and all its parts,
|
||||
regardless of how they are packaged. This License gives no
|
||||
permission to license the work in any other way, but it does not
|
||||
invalidate such permission if you have separately received it.
|
||||
|
||||
d) If the work has interactive user interfaces, each must display
|
||||
Appropriate Legal Notices; however, if the Program has interactive
|
||||
interfaces that do not display Appropriate Legal Notices, your
|
||||
work need not make them do so.
|
||||
|
||||
A compilation of a covered work with other separate and independent
|
||||
works, which are not by their nature extensions of the covered work,
|
||||
and which are not combined with it such as to form a larger program,
|
||||
in or on a volume of a storage or distribution medium, is called an
|
||||
"aggregate" if the compilation and its resulting copyright are not
|
||||
used to limit the access or legal rights of the compilation's users
|
||||
beyond what the individual works permit. Inclusion of a covered work
|
||||
in an aggregate does not cause this License to apply to the other
|
||||
parts of the aggregate.
|
||||
|
||||
6. Conveying Non-Source Forms.
|
||||
|
||||
You may convey a covered work in object code form under the terms
|
||||
of sections 4 and 5, provided that you also convey the
|
||||
machine-readable Corresponding Source under the terms of this License,
|
||||
in one of these ways:
|
||||
|
||||
a) Convey the object code in, or embodied in, a physical product
|
||||
(including a physical distribution medium), accompanied by the
|
||||
Corresponding Source fixed on a durable physical medium
|
||||
customarily used for software interchange.
|
||||
|
||||
b) Convey the object code in, or embodied in, a physical product
|
||||
(including a physical distribution medium), accompanied by a
|
||||
written offer, valid for at least three years and valid for as
|
||||
long as you offer spare parts or customer support for that product
|
||||
model, to give anyone who possesses the object code either (1) a
|
||||
copy of the Corresponding Source for all the software in the
|
||||
product that is covered by this License, on a durable physical
|
||||
medium customarily used for software interchange, for a price no
|
||||
more than your reasonable cost of physically performing this
|
||||
conveying of source, or (2) access to copy the
|
||||
Corresponding Source from a network server at no charge.
|
||||
|
||||
c) Convey individual copies of the object code with a copy of the
|
||||
written offer to provide the Corresponding Source. This
|
||||
alternative is allowed only occasionally and noncommercially, and
|
||||
only if you received the object code with such an offer, in accord
|
||||
with subsection 6b.
|
||||
|
||||
d) Convey the object code by offering access from a designated
|
||||
place (gratis or for a charge), and offer equivalent access to the
|
||||
Corresponding Source in the same way through the same place at no
|
||||
further charge. You need not require recipients to copy the
|
||||
Corresponding Source along with the object code. If the place to
|
||||
copy the object code is a network server, the Corresponding Source
|
||||
may be on a different server (operated by you or a third party)
|
||||
that supports equivalent copying facilities, provided you maintain
|
||||
clear directions next to the object code saying where to find the
|
||||
Corresponding Source. Regardless of what server hosts the
|
||||
Corresponding Source, you remain obligated to ensure that it is
|
||||
available for as long as needed to satisfy these requirements.
|
||||
|
||||
e) Convey the object code using peer-to-peer transmission, provided
|
||||
you inform other peers where the object code and Corresponding
|
||||
Source of the work are being offered to the general public at no
|
||||
charge under subsection 6d.
|
||||
|
||||
A separable portion of the object code, whose source code is excluded
|
||||
from the Corresponding Source as a System Library, need not be
|
||||
included in conveying the object code work.
|
||||
|
||||
A "User Product" is either (1) a "consumer product", which means any
|
||||
tangible personal property which is normally used for personal, family,
|
||||
or household purposes, or (2) anything designed or sold for incorporation
|
||||
into a dwelling. In determining whether a product is a consumer product,
|
||||
doubtful cases shall be resolved in favor of coverage. For a particular
|
||||
product received by a particular user, "normally used" refers to a
|
||||
typical or common use of that class of product, regardless of the status
|
||||
of the particular user or of the way in which the particular user
|
||||
actually uses, or expects or is expected to use, the product. A product
|
||||
is a consumer product regardless of whether the product has substantial
|
||||
commercial, industrial or non-consumer uses, unless such uses represent
|
||||
the only significant mode of use of the product.
|
||||
|
||||
"Installation Information" for a User Product means any methods,
|
||||
procedures, authorization keys, or other information required to install
|
||||
and execute modified versions of a covered work in that User Product from
|
||||
a modified version of its Corresponding Source. The information must
|
||||
suffice to ensure that the continued functioning of the modified object
|
||||
code is in no case prevented or interfered with solely because
|
||||
modification has been made.
|
||||
|
||||
If you convey an object code work under this section in, or with, or
|
||||
specifically for use in, a User Product, and the conveying occurs as
|
||||
part of a transaction in which the right of possession and use of the
|
||||
User Product is transferred to the recipient in perpetuity or for a
|
||||
fixed term (regardless of how the transaction is characterized), the
|
||||
Corresponding Source conveyed under this section must be accompanied
|
||||
by the Installation Information. But this requirement does not apply
|
||||
if neither you nor any third party retains the ability to install
|
||||
modified object code on the User Product (for example, the work has
|
||||
been installed in ROM).
|
||||
|
||||
The requirement to provide Installation Information does not include a
|
||||
requirement to continue to provide support service, warranty, or updates
|
||||
for a work that has been modified or installed by the recipient, or for
|
||||
the User Product in which it has been modified or installed. Access to a
|
||||
network may be denied when the modification itself materially and
|
||||
adversely affects the operation of the network or violates the rules and
|
||||
protocols for communication across the network.
|
||||
|
||||
Corresponding Source conveyed, and Installation Information provided,
|
||||
in accord with this section must be in a format that is publicly
|
||||
documented (and with an implementation available to the public in
|
||||
source code form), and must require no special password or key for
|
||||
unpacking, reading or copying.
|
||||
|
||||
7. Additional Terms.
|
||||
|
||||
"Additional permissions" are terms that supplement the terms of this
|
||||
License by making exceptions from one or more of its conditions.
|
||||
Additional permissions that are applicable to the entire Program shall
|
||||
be treated as though they were included in this License, to the extent
|
||||
that they are valid under applicable law. If additional permissions
|
||||
apply only to part of the Program, that part may be used separately
|
||||
under those permissions, but the entire Program remains governed by
|
||||
this License without regard to the additional permissions.
|
||||
|
||||
When you convey a copy of a covered work, you may at your option
|
||||
remove any additional permissions from that copy, or from any part of
|
||||
it. (Additional permissions may be written to require their own
|
||||
removal in certain cases when you modify the work.) You may place
|
||||
additional permissions on material, added by you to a covered work,
|
||||
for which you have or can give appropriate copyright permission.
|
||||
|
||||
Notwithstanding any other provision of this License, for material you
|
||||
add to a covered work, you may (if authorized by the copyright holders of
|
||||
that material) supplement the terms of this License with terms:
|
||||
|
||||
a) Disclaiming warranty or limiting liability differently from the
|
||||
terms of sections 15 and 16 of this License; or
|
||||
|
||||
b) Requiring preservation of specified reasonable legal notices or
|
||||
author attributions in that material or in the Appropriate Legal
|
||||
Notices displayed by works containing it; or
|
||||
|
||||
c) Prohibiting misrepresentation of the origin of that material, or
|
||||
requiring that modified versions of such material be marked in
|
||||
reasonable ways as different from the original version; or
|
||||
|
||||
d) Limiting the use for publicity purposes of names of licensors or
|
||||
authors of the material; or
|
||||
|
||||
e) Declining to grant rights under trademark law for use of some
|
||||
trade names, trademarks, or service marks; or
|
||||
|
||||
f) Requiring indemnification of licensors and authors of that
|
||||
material by anyone who conveys the material (or modified versions of
|
||||
it) with contractual assumptions of liability to the recipient, for
|
||||
any liability that these contractual assumptions directly impose on
|
||||
those licensors and authors.
|
||||
|
||||
All other non-permissive additional terms are considered "further
|
||||
restrictions" within the meaning of section 10. If the Program as you
|
||||
received it, or any part of it, contains a notice stating that it is
|
||||
governed by this License along with a term that is a further
|
||||
restriction, you may remove that term. If a license document contains
|
||||
a further restriction but permits relicensing or conveying under this
|
||||
License, you may add to a covered work material governed by the terms
|
||||
of that license document, provided that the further restriction does
|
||||
not survive such relicensing or conveying.
|
||||
|
||||
If you add terms to a covered work in accord with this section, you
|
||||
must place, in the relevant source files, a statement of the
|
||||
additional terms that apply to those files, or a notice indicating
|
||||
where to find the applicable terms.
|
||||
|
||||
Additional terms, permissive or non-permissive, may be stated in the
|
||||
form of a separately written license, or stated as exceptions;
|
||||
the above requirements apply either way.
|
||||
|
||||
8. Termination.
|
||||
|
||||
You may not propagate or modify a covered work except as expressly
|
||||
provided under this License. Any attempt otherwise to propagate or
|
||||
modify it is void, and will automatically terminate your rights under
|
||||
this License (including any patent licenses granted under the third
|
||||
paragraph of section 11).
|
||||
|
||||
However, if you cease all violation of this License, then your
|
||||
license from a particular copyright holder is reinstated (a)
|
||||
provisionally, unless and until the copyright holder explicitly and
|
||||
finally terminates your license, and (b) permanently, if the copyright
|
||||
holder fails to notify you of the violation by some reasonable means
|
||||
prior to 60 days after the cessation.
|
||||
|
||||
Moreover, your license from a particular copyright holder is
|
||||
reinstated permanently if the copyright holder notifies you of the
|
||||
violation by some reasonable means, this is the first time you have
|
||||
received notice of violation of this License (for any work) from that
|
||||
copyright holder, and you cure the violation prior to 30 days after
|
||||
your receipt of the notice.
|
||||
|
||||
Termination of your rights under this section does not terminate the
|
||||
licenses of parties who have received copies or rights from you under
|
||||
this License. If your rights have been terminated and not permanently
|
||||
reinstated, you do not qualify to receive new licenses for the same
|
||||
material under section 10.
|
||||
|
||||
9. Acceptance Not Required for Having Copies.
|
||||
|
||||
You are not required to accept this License in order to receive or
|
||||
run a copy of the Program. Ancillary propagation of a covered work
|
||||
occurring solely as a consequence of using peer-to-peer transmission
|
||||
to receive a copy likewise does not require acceptance. However,
|
||||
nothing other than this License grants you permission to propagate or
|
||||
modify any covered work. These actions infringe copyright if you do
|
||||
not accept this License. Therefore, by modifying or propagating a
|
||||
covered work, you indicate your acceptance of this License to do so.
|
||||
|
||||
10. Automatic Licensing of Downstream Recipients.
|
||||
|
||||
Each time you convey a covered work, the recipient automatically
|
||||
receives a license from the original licensors, to run, modify and
|
||||
propagate that work, subject to this License. You are not responsible
|
||||
for enforcing compliance by third parties with this License.
|
||||
|
||||
An "entity transaction" is a transaction transferring control of an
|
||||
organization, or substantially all assets of one, or subdividing an
|
||||
organization, or merging organizations. If propagation of a covered
|
||||
work results from an entity transaction, each party to that
|
||||
transaction who receives a copy of the work also receives whatever
|
||||
licenses to the work the party's predecessor in interest had or could
|
||||
give under the previous paragraph, plus a right to possession of the
|
||||
Corresponding Source of the work from the predecessor in interest, if
|
||||
the predecessor has it or can get it with reasonable efforts.
|
||||
|
||||
You may not impose any further restrictions on the exercise of the
|
||||
rights granted or affirmed under this License. For example, you may
|
||||
not impose a license fee, royalty, or other charge for exercise of
|
||||
rights granted under this License, and you may not initiate litigation
|
||||
(including a cross-claim or counterclaim in a lawsuit) alleging that
|
||||
any patent claim is infringed by making, using, selling, offering for
|
||||
sale, or importing the Program or any portion of it.
|
||||
|
||||
11. Patents.
|
||||
|
||||
A "contributor" is a copyright holder who authorizes use under this
|
||||
License of the Program or a work on which the Program is based. The
|
||||
work thus licensed is called the contributor's "contributor version".
|
||||
|
||||
A contributor's "essential patent claims" are all patent claims
|
||||
owned or controlled by the contributor, whether already acquired or
|
||||
hereafter acquired, that would be infringed by some manner, permitted
|
||||
by this License, of making, using, or selling its contributor version,
|
||||
but do not include claims that would be infringed only as a
|
||||
consequence of further modification of the contributor version. For
|
||||
purposes of this definition, "control" includes the right to grant
|
||||
patent sublicenses in a manner consistent with the requirements of
|
||||
this License.
|
||||
|
||||
Each contributor grants you a non-exclusive, worldwide, royalty-free
|
||||
patent license under the contributor's essential patent claims, to
|
||||
make, use, sell, offer for sale, import and otherwise run, modify and
|
||||
propagate the contents of its contributor version.
|
||||
|
||||
In the following three paragraphs, a "patent license" is any express
|
||||
agreement or commitment, however denominated, not to enforce a patent
|
||||
(such as an express permission to practice a patent or covenant not to
|
||||
sue for patent infringement). To "grant" such a patent license to a
|
||||
party means to make such an agreement or commitment not to enforce a
|
||||
patent against the party.
|
||||
|
||||
If you convey a covered work, knowingly relying on a patent license,
|
||||
and the Corresponding Source of the work is not available for anyone
|
||||
to copy, free of charge and under the terms of this License, through a
|
||||
publicly available network server or other readily accessible means,
|
||||
then you must either (1) cause the Corresponding Source to be so
|
||||
available, or (2) arrange to deprive yourself of the benefit of the
|
||||
patent license for this particular work, or (3) arrange, in a manner
|
||||
consistent with the requirements of this License, to extend the patent
|
||||
license to downstream recipients. "Knowingly relying" means you have
|
||||
actual knowledge that, but for the patent license, your conveying the
|
||||
covered work in a country, or your recipient's use of the covered work
|
||||
in a country, would infringe one or more identifiable patents in that
|
||||
country that you have reason to believe are valid.
|
||||
|
||||
If, pursuant to or in connection with a single transaction or
|
||||
arrangement, you convey, or propagate by procuring conveyance of, a
|
||||
covered work, and grant a patent license to some of the parties
|
||||
receiving the covered work authorizing them to use, propagate, modify
|
||||
or convey a specific copy of the covered work, then the patent license
|
||||
you grant is automatically extended to all recipients of the covered
|
||||
work and works based on it.
|
||||
|
||||
A patent license is "discriminatory" if it does not include within
|
||||
the scope of its coverage, prohibits the exercise of, or is
|
||||
conditioned on the non-exercise of one or more of the rights that are
|
||||
specifically granted under this License. You may not convey a covered
|
||||
work if you are a party to an arrangement with a third party that is
|
||||
in the business of distributing software, under which you make payment
|
||||
to the third party based on the extent of your activity of conveying
|
||||
the work, and under which the third party grants, to any of the
|
||||
parties who would receive the covered work from you, a discriminatory
|
||||
patent license (a) in connection with copies of the covered work
|
||||
conveyed by you (or copies made from those copies), or (b) primarily
|
||||
for and in connection with specific products or compilations that
|
||||
contain the covered work, unless you entered into that arrangement,
|
||||
or that patent license was granted, prior to 28 March 2007.
|
||||
|
||||
Nothing in this License shall be construed as excluding or limiting
|
||||
any implied license or other defenses to infringement that may
|
||||
otherwise be available to you under applicable patent law.
|
||||
|
||||
12. No Surrender of Others' Freedom.
|
||||
|
||||
If conditions are imposed on you (whether by court order, agreement or
|
||||
otherwise) that contradict the conditions of this License, they do not
|
||||
excuse you from the conditions of this License. If you cannot convey a
|
||||
covered work so as to satisfy simultaneously your obligations under this
|
||||
License and any other pertinent obligations, then as a consequence you may
|
||||
not convey it at all. For example, if you agree to terms that obligate you
|
||||
to collect a royalty for further conveying from those to whom you convey
|
||||
the Program, the only way you could satisfy both those terms and this
|
||||
License would be to refrain entirely from conveying the Program.
|
||||
|
||||
13. Use with the GNU Affero General Public License.
|
||||
|
||||
Notwithstanding any other provision of this License, you have
|
||||
permission to link or combine any covered work with a work licensed
|
||||
under version 3 of the GNU Affero General Public License into a single
|
||||
combined work, and to convey the resulting work. The terms of this
|
||||
License will continue to apply to the part which is the covered work,
|
||||
but the special requirements of the GNU Affero General Public License,
|
||||
section 13, concerning interaction through a network will apply to the
|
||||
combination as such.
|
||||
|
||||
14. Revised Versions of this License.
|
||||
|
||||
The Free Software Foundation may publish revised and/or new versions of
|
||||
the GNU General Public License from time to time. Such new versions will
|
||||
be similar in spirit to the present version, but may differ in detail to
|
||||
address new problems or concerns.
|
||||
|
||||
Each version is given a distinguishing version number. If the
|
||||
Program specifies that a certain numbered version of the GNU General
|
||||
Public License "or any later version" applies to it, you have the
|
||||
option of following the terms and conditions either of that numbered
|
||||
version or of any later version published by the Free Software
|
||||
Foundation. If the Program does not specify a version number of the
|
||||
GNU General Public License, you may choose any version ever published
|
||||
by the Free Software Foundation.
|
||||
|
||||
If the Program specifies that a proxy can decide which future
|
||||
versions of the GNU General Public License can be used, that proxy's
|
||||
public statement of acceptance of a version permanently authorizes you
|
||||
to choose that version for the Program.
|
||||
|
||||
Later license versions may give you additional or different
|
||||
permissions. However, no additional obligations are imposed on any
|
||||
author or copyright holder as a result of your choosing to follow a
|
||||
later version.
|
||||
|
||||
15. Disclaimer of Warranty.
|
||||
|
||||
THERE IS NO WARRANTY FOR THE PROGRAM, TO THE EXTENT PERMITTED BY
|
||||
APPLICABLE LAW. EXCEPT WHEN OTHERWISE STATED IN WRITING THE COPYRIGHT
|
||||
HOLDERS AND/OR OTHER PARTIES PROVIDE THE PROGRAM "AS IS" WITHOUT WARRANTY
|
||||
OF ANY KIND, EITHER EXPRESSED OR IMPLIED, INCLUDING, BUT NOT LIMITED TO,
|
||||
THE IMPLIED WARRANTIES OF MERCHANTABILITY AND FITNESS FOR A PARTICULAR
|
||||
PURPOSE. THE ENTIRE RISK AS TO THE QUALITY AND PERFORMANCE OF THE PROGRAM
|
||||
IS WITH YOU. SHOULD THE PROGRAM PROVE DEFECTIVE, YOU ASSUME THE COST OF
|
||||
ALL NECESSARY SERVICING, REPAIR OR CORRECTION.
|
||||
|
||||
16. Limitation of Liability.
|
||||
|
||||
IN NO EVENT UNLESS REQUIRED BY APPLICABLE LAW OR AGREED TO IN WRITING
|
||||
WILL ANY COPYRIGHT HOLDER, OR ANY OTHER PARTY WHO MODIFIES AND/OR CONVEYS
|
||||
THE PROGRAM AS PERMITTED ABOVE, BE LIABLE TO YOU FOR DAMAGES, INCLUDING ANY
|
||||
GENERAL, SPECIAL, INCIDENTAL OR CONSEQUENTIAL DAMAGES ARISING OUT OF THE
|
||||
USE OR INABILITY TO USE THE PROGRAM (INCLUDING BUT NOT LIMITED TO LOSS OF
|
||||
DATA OR DATA BEING RENDERED INACCURATE OR LOSSES SUSTAINED BY YOU OR THIRD
|
||||
PARTIES OR A FAILURE OF THE PROGRAM TO OPERATE WITH ANY OTHER PROGRAMS),
|
||||
EVEN IF SUCH HOLDER OR OTHER PARTY HAS BEEN ADVISED OF THE POSSIBILITY OF
|
||||
SUCH DAMAGES.
|
||||
|
||||
17. Interpretation of Sections 15 and 16.
|
||||
|
||||
If the disclaimer of warranty and limitation of liability provided
|
||||
above cannot be given local legal effect according to their terms,
|
||||
reviewing courts shall apply local law that most closely approximates
|
||||
an absolute waiver of all civil liability in connection with the
|
||||
Program, unless a warranty or assumption of liability accompanies a
|
||||
copy of the Program in return for a fee.
|
||||
|
||||
END OF TERMS AND CONDITIONS
|
||||
|
||||
How to Apply These Terms to Your New Programs
|
||||
|
||||
If you develop a new program, and you want it to be of the greatest
|
||||
possible use to the public, the best way to achieve this is to make it
|
||||
free software which everyone can redistribute and change under these terms.
|
||||
|
||||
To do so, attach the following notices to the program. It is safest
|
||||
to attach them to the start of each source file to most effectively
|
||||
state the exclusion of warranty; and each file should have at least
|
||||
the "copyright" line and a pointer to where the full notice is found.
|
||||
|
||||
<one line to give the program's name and a brief idea of what it does.>
|
||||
Copyright (C) <year> <name of author>
|
||||
|
||||
This program is free software: you can redistribute it and/or modify
|
||||
it under the terms of the GNU General Public License as published by
|
||||
the Free Software Foundation, either version 3 of the License, or
|
||||
(at your option) any later version.
|
||||
|
||||
This program is distributed in the hope that it will be useful,
|
||||
but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||
MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||
GNU General Public License for more details.
|
||||
|
||||
You should have received a copy of the GNU General Public License
|
||||
along with this program. If not, see <https://www.gnu.org/licenses/>.
|
||||
|
||||
Also add information on how to contact you by electronic and paper mail.
|
||||
|
||||
If the program does terminal interaction, make it output a short
|
||||
notice like this when it starts in an interactive mode:
|
||||
|
||||
<program> Copyright (C) <year> <name of author>
|
||||
This program comes with ABSOLUTELY NO WARRANTY; for details type `show w'.
|
||||
This is free software, and you are welcome to redistribute it
|
||||
under certain conditions; type `show c' for details.
|
||||
|
||||
The hypothetical commands `show w' and `show c' should show the appropriate
|
||||
parts of the General Public License. Of course, your program's commands
|
||||
might be different; for a GUI interface, you would use an "about box".
|
||||
|
||||
You should also get your employer (if you work as a programmer) or school,
|
||||
if any, to sign a "copyright disclaimer" for the program, if necessary.
|
||||
For more information on this, and how to apply and follow the GNU GPL, see
|
||||
<https://www.gnu.org/licenses/>.
|
||||
|
||||
The GNU General Public License does not permit incorporating your program
|
||||
into proprietary programs. If your program is a subroutine library, you
|
||||
may consider it more useful to permit linking proprietary applications with
|
||||
the library. If this is what you want to do, use the GNU Lesser General
|
||||
Public License instead of this License. But first, please read
|
||||
<https://www.gnu.org/licenses/why-not-lgpl.html>.
|
||||
@@ -0,0 +1,34 @@
|
||||
# ExoMy - Software Repository
|
||||
This repository contains the software to run Exomy. The [wiki](https://github.com/esa-prl/ExoMy/wiki) explains you how to use it.
|
||||
|
||||
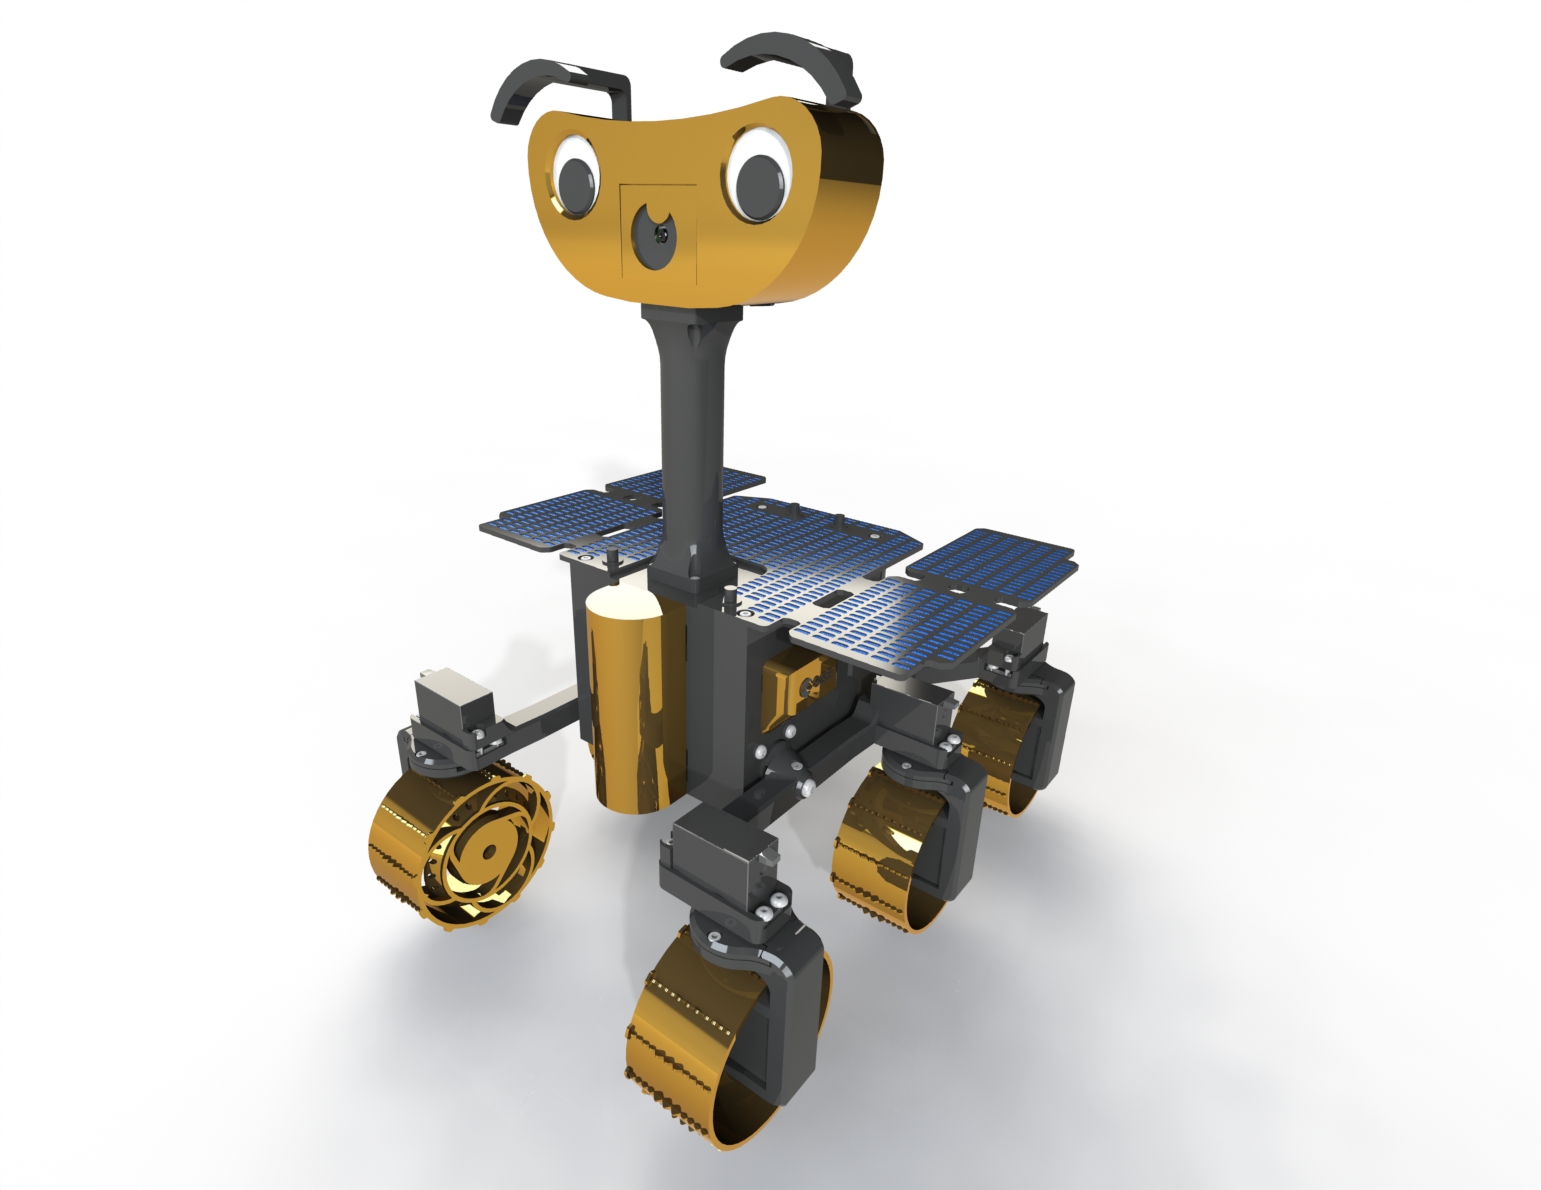
|
||||
|
||||
# ExoMy Project Structure
|
||||
|
||||
### [Website](https://esa-prl.github.io/ExoMy/)
|
||||
There is a website about ExoMy. It does not help you build it, but is still nice to look at.
|
||||
|
||||
### [Wiki](https://github.com/esa-prl/ExoMy/wiki)
|
||||
The [wiki](https://github.com/esa-prl/ExoMy/wiki) contains step by step instructions on how the 3D-printed rover ExoMy can be built, controlled and customized.
|
||||
|
||||
### [Documentation Repository](https://github.com/esa-prl/ExoMy)
|
||||
This repository contains all the files of the documentation of ExoMy. Just click on [*Releases*](https://github.com/esa-prl/ExoMy/releases) and download the files of the latest release. They are explained further in the [wiki](https://github.com/esa-prl/ExoMy/wiki).
|
||||
|
||||
### Social Media
|
||||
<!-- Add icon library -->
|
||||
<link rel="stylesheet" href="https://use.fontawesome.com/releases/v5.13.1/css/all.css">
|
||||
|
||||
<!-- Add font awesome icons -->
|
||||
<p>
|
||||
<img src="https://github.com/esa-prl/ExoMy/wiki/images/social_media_icons/discord-brands.svg" width="20px">
|
||||
<a href="https://discord.gg/gZk62gg"> Join the Community!</a>
|
||||
</p>
|
||||
<p>
|
||||
<img src="https://github.com/esa-prl/ExoMy/wiki/images/social_media_icons/twitter-square-brands.svg" width="20px">
|
||||
<a href="https://twitter.com/exomy_rover"> @ExoMy_Rover</a>
|
||||
</p>
|
||||
<p>
|
||||
<img src="https://github.com/esa-prl/ExoMy/wiki/images/social_media_icons/instagram-square-brands.svg" width="20px">
|
||||
<a href="https://www.instagram.com/exomy_rover/"> @ExoMy_Rover</a>
|
||||
</p>
|
||||
|
||||
@@ -0,0 +1,45 @@
|
||||
# Naming conventions:
|
||||
#
|
||||
# fl - front left | fr - front right
|
||||
# cl - center left | cr - center right
|
||||
# rl - rear left | rr - rear right
|
||||
|
||||
# Pin numbers for motors on PWM board
|
||||
pin_drive_fl: 14
|
||||
pin_steer_fl: 12
|
||||
|
||||
pin_drive_fr: 2
|
||||
pin_steer_fr: 0
|
||||
|
||||
pin_drive_cl: 6
|
||||
pin_steer_cl: 7
|
||||
|
||||
pin_drive_cr: 4
|
||||
pin_steer_cr: 5
|
||||
|
||||
pin_drive_rl: 15
|
||||
pin_steer_rl: 13
|
||||
|
||||
pin_drive_rr: 3
|
||||
pin_steer_rr: 1
|
||||
|
||||
## PWM values
|
||||
# Those values highly depend on the motors and pwm board used
|
||||
# Check out the wiki for further explanation
|
||||
|
||||
# PWM values for the neutral steering position
|
||||
steer_pwm_neutral_fl: 300
|
||||
steer_pwm_neutral_fr: 300
|
||||
steer_pwm_neutral_cl: 300
|
||||
steer_pwm_neutral_cr: 300
|
||||
steer_pwm_neutral_rl: 300
|
||||
steer_pwm_neutral_rr: 300
|
||||
|
||||
# PWW range around steering neutral position
|
||||
steer_pwm_range: 250
|
||||
|
||||
# PWM value for the stop position of driving motors
|
||||
drive_pwm_neutral: 307
|
||||
|
||||
# PWW range around driving neutral position
|
||||
drive_pwm_range: 100
|
||||
@@ -0,0 +1,36 @@
|
||||
# Base image
|
||||
FROM ros:melodic
|
||||
|
||||
ENV TZ=Europe/Amsterdam
|
||||
RUN ln -snf /usr/share/zoneinfo/$TZ /etc/localtime && echo $TZ > /etc/timezone
|
||||
|
||||
# Basic tools
|
||||
RUN apt-get update && \
|
||||
apt-get install vim nano git tmux wget curl python-pip net-tools iputils-ping -y
|
||||
|
||||
# Install additional ros packages
|
||||
RUN apt-get update && apt-get install ros-melodic-rosbridge-server ros-melodic-joy -y
|
||||
RUN pip install adafruit-pca9685
|
||||
|
||||
|
||||
# Install packages for web application
|
||||
RUN curl -sL https://deb.nodesource.com/setup_12.x | bash -
|
||||
RUN apt-get update && \
|
||||
apt-get install nodejs -y
|
||||
RUN npm install http-server -g
|
||||
|
||||
# Install packages for camera use
|
||||
RUN apt-get update && \
|
||||
apt-get install ros-melodic-web-video-server ros-melodic-usb-cam -y
|
||||
|
||||
# Add ros sourcing to bashrc
|
||||
RUN echo ". /opt/ros/melodic/setup.bash" >> ~/.bashrc
|
||||
|
||||
# Create Ros workspace
|
||||
ENV EXOMY_WS=/root/exomy_ws
|
||||
RUN mkdir -p $EXOMY_WS/src
|
||||
|
||||
WORKDIR /root
|
||||
|
||||
COPY ./entrypoint.sh /
|
||||
ENTRYPOINT ["/entrypoint.sh"]
|
||||
@@ -0,0 +1,27 @@
|
||||
#!/bin/bash
|
||||
if [[ $1 == "config" ]]
|
||||
then
|
||||
cd /root/exomy_ws/src/exomy/scripts
|
||||
bash
|
||||
elif [[ $1 == "autostart" ]]
|
||||
then
|
||||
source /opt/ros/melodic/setup.bash
|
||||
cd /root/exomy_ws
|
||||
catkin_make
|
||||
http-server src/exomy/gui -p 8000 &
|
||||
|
||||
source devel/setup.bash
|
||||
roslaunch exomy exomy.launch
|
||||
|
||||
bash
|
||||
elif [[ $1 == "devel" ]]
|
||||
then
|
||||
cd /root/exomy_ws
|
||||
source /opt/ros/melodic/setup.bash
|
||||
# catkin_make
|
||||
# source devel/setup.bash
|
||||
bash
|
||||
else
|
||||
bash
|
||||
fi
|
||||
|
||||
@@ -0,0 +1,75 @@
|
||||
#!/bin/bash
|
||||
# run_exomy- A script to run containers for dedicated functions of exomy
|
||||
|
||||
help_text="Usage: "$0" [MODE] [OPTIONS]
|
||||
A script to run ExoMy in different configurations
|
||||
Options:
|
||||
-a, --autostart Toggles autostart mode on or off
|
||||
-c, --config Runs the motor configuration of ExoMy
|
||||
-d, --devel Runs the development mode to change some code of ExoMy
|
||||
-h, --help Shows this text
|
||||
"
|
||||
|
||||
### Main
|
||||
# Initialize parameters
|
||||
container_name="exomy"
|
||||
image_name="exomy"
|
||||
|
||||
# Process parameters
|
||||
if [ "$1" != "" ]; then
|
||||
case $1 in
|
||||
-a | --autostart)
|
||||
container_name="${container_name}_autostart"
|
||||
start_command="autostart"
|
||||
options="--restart always"
|
||||
|
||||
;;
|
||||
-s | --stop_autostart)
|
||||
docker container stop "${container_name}_autostart"
|
||||
exit
|
||||
;;
|
||||
-c | --config)
|
||||
container_name="${container_name}_config"
|
||||
start_command="config"
|
||||
options="--rm"
|
||||
;;
|
||||
-d | --devel)
|
||||
container_name="${container_name}_devel"
|
||||
start_command="devel"
|
||||
options="--restart always"
|
||||
;;
|
||||
-h | --help ) echo "$help_text"
|
||||
exit
|
||||
;;
|
||||
* ) echo "ERROR: Not a valid mode!"
|
||||
echo "$help_text"
|
||||
exit 1
|
||||
esac
|
||||
else
|
||||
echo "ERROR: You need to specify a mode!"
|
||||
echo "$help_text"
|
||||
exit
|
||||
fi
|
||||
|
||||
# Build docker image from Dockerfile in directory
|
||||
directory=$( dirname "$0" )
|
||||
docker build -t $image_name $directory
|
||||
|
||||
# Stop any of the 3 containers if running
|
||||
RUNNING_CONTAINERS=$( docker container ls -a -q --filter ancestor=exomy )
|
||||
if [ -n "$RUNNING_CONTAINERS" ]; then
|
||||
docker rm -f "$RUNNING_CONTAINERS"
|
||||
fi
|
||||
|
||||
# Run docker container
|
||||
docker run \
|
||||
-it \
|
||||
-v ~/ExoMy_Software:/root/exomy_ws/src/exomy \
|
||||
-p 8000:8000 \
|
||||
-p 8080:8080 \
|
||||
-p 9090:9090 \
|
||||
--privileged \
|
||||
${options} \
|
||||
--name "${container_name}" \
|
||||
"${image_name}" \
|
||||
"${start_command}"
|
||||
@@ -0,0 +1,146 @@
|
||||
<!DOCTYPE html>
|
||||
<html>
|
||||
|
||||
<head>
|
||||
<meta charset="utf-8" />
|
||||
|
||||
<script type="text/javascript" src="http://static.robotwebtools.org/roslibjs/current/roslib.min.js"></script>
|
||||
<script src="./node_modules/nipplejs/dist/nipplejs.js"></script>
|
||||
<script type="text/javascript" type="text/javascript">
|
||||
var publishImmidiately = true;
|
||||
var host_url = window.location.hostname;
|
||||
console.log(host_url);
|
||||
var watchdog_handle;
|
||||
|
||||
var ros = new ROSLIB.Ros({
|
||||
url: 'ws://' + host_url + ':9090'
|
||||
});
|
||||
|
||||
// Initialize Axes and Buttons arrays
|
||||
var axes = [0, 0, 0, 0, 0, 0];
|
||||
var buttons = [0, 0, 0, 0, 0, 0, 0, 0, 0, 0, 0, 0];
|
||||
|
||||
ros.on('connection', function () {
|
||||
document.getElementById("status").innerHTML = "Connected";
|
||||
});
|
||||
|
||||
ros.on('error', function (error) {
|
||||
document.getElementById("status").innerHTML = "Error";
|
||||
});
|
||||
|
||||
ros.on('close', function () {
|
||||
document.getElementById("status").innerHTML = "Closed";
|
||||
});
|
||||
|
||||
createJoystick = function () {
|
||||
var options = {
|
||||
zone: document.getElementById('joy_container'),
|
||||
threshold: 0.1,
|
||||
position: { left: '50%', top: '50%' },
|
||||
mode: 'static',
|
||||
size: 150,
|
||||
color: 'black'
|
||||
};
|
||||
manager = nipplejs.create(options);
|
||||
|
||||
self.manager.on('start', function (event, nipple) {
|
||||
});
|
||||
|
||||
self.manager.on('move', function (event, nipple) {
|
||||
var max_distance = 75;
|
||||
var x = -Math.cos(nipple.angle.radian) * nipple.distance / max_distance;
|
||||
var y = Math.sin(nipple.angle.radian) * nipple.distance / max_distance;
|
||||
axes = [x, y, 0, 0, 0, 0]
|
||||
|
||||
// nipplejs is triggering events when joystick moves each pixel
|
||||
// we need delay between consecutive messege publications to
|
||||
// prevent system from being flooded by messages
|
||||
// events triggered earlier than 50ms after last publication will be dropped
|
||||
|
||||
if (publishImmidiately) {
|
||||
publishImmidiately = false;
|
||||
joy_event()
|
||||
window.clearInterval(watchdog_handle)
|
||||
watchdog_handle = window.setInterval(joy_event, 50)
|
||||
|
||||
setTimeout(function () {
|
||||
publishImmidiately = true;
|
||||
}, 50);
|
||||
}
|
||||
//joy_event()
|
||||
//window.clearInterval()
|
||||
//window.setInterval(joy_event, 500)
|
||||
});
|
||||
|
||||
self.manager.on('end', function () {
|
||||
window.clearInterval(watchdog_handle)
|
||||
axes = [0, 0, 0, 0, 0, 0]
|
||||
joy_event()
|
||||
console.log('End function called')
|
||||
});
|
||||
}
|
||||
window.onload = function () {
|
||||
createJoystick();
|
||||
// Video output
|
||||
stream_url = '//' + host_url + ':8080/stream?topic=/pi_cam/image_raw';
|
||||
console.log(stream_url);
|
||||
document.getElementById("video_output").src = stream_url;
|
||||
}
|
||||
|
||||
joy_listener = new ROSLIB.Topic({
|
||||
ros: ros,
|
||||
name: "/joy",
|
||||
messageType: 'sensor_msgs/Joy'
|
||||
});
|
||||
|
||||
joy_event = function () {
|
||||
var joy = new ROSLIB.Message({
|
||||
axes: axes,
|
||||
buttons: buttons
|
||||
});
|
||||
joy_listener.publish(joy);
|
||||
console.log(axes)
|
||||
console.log(buttons)
|
||||
}
|
||||
|
||||
button_clicked = function (button_index) {
|
||||
// The desired button index can be found by listening to the /joy ros message
|
||||
// or by checking in the wiki for the gamepad mapping.
|
||||
// Set axes to 0 to prevent driving during mode change.
|
||||
axes = [0, 0, 0, 0, 0, 0];
|
||||
buttons[button_index] = 1;
|
||||
joy_event();
|
||||
// After the command is sent set the index back to 0
|
||||
buttons[button_index] = 0;
|
||||
}
|
||||
|
||||
</script>
|
||||
<link rel="stylesheet" type="text/css" href="style.css">
|
||||
|
||||
</head>
|
||||
|
||||
<body>
|
||||
<main>
|
||||
<div class="wrapper">
|
||||
<div class="left" id="left">
|
||||
<div class="joy_container" id="joy_container"></div>
|
||||
</div>
|
||||
|
||||
<div class="middle" id="middle">
|
||||
<div class="image_container">
|
||||
<img id="video_output" style="object-fit:cover; width:100%;"></img>
|
||||
</div>
|
||||
</div>
|
||||
<div class="right" id="right">
|
||||
<div class="button_container">
|
||||
<button class="button buttonY" onclick="button_clicked(3)">CRABBING</button>
|
||||
<button class="button buttonX" onclick="button_clicked(0)">SPOT TURN</button>
|
||||
<button class="button buttonA" onclick="button_clicked(1)">ACKERMANN</button>
|
||||
<button class="button buttonStart" onclick="button_clicked(9)">MOTORS</button>
|
||||
</div>
|
||||
</div>
|
||||
</div>
|
||||
</main>
|
||||
|
||||
|
||||
</html>
|
||||
+386
@@ -0,0 +1,386 @@
|
||||
<a name="0.8.5"></a>
|
||||
## [0.8.5](https://github.com/yoannmoinet/nipplejs/compare/v0.8.4...v0.8.5) (2020-01-27)
|
||||
|
||||
|
||||
|
||||
<a name="0.8.4"></a>
|
||||
## [0.8.4](https://github.com/yoannmoinet/nipplejs/compare/v0.7.3...v0.8.4) (2019-11-28)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* allow older typescript ([c164597](https://github.com/yoannmoinet/nipplejs/commit/c164597))
|
||||
* better lockX and lockY mecanism ([8355fb8](https://github.com/yoannmoinet/nipplejs/commit/8355fb8)), closes [#111](https://github.com/yoannmoinet/nipplejs/issues/111)
|
||||
* joystick in 'dynamic' mode gets stuck on iOS ([94bb784](https://github.com/yoannmoinet/nipplejs/commit/94bb784)), closes [#94](https://github.com/yoannmoinet/nipplejs/issues/94)
|
||||
* released outside will be considered inside ([9a8a7b4](https://github.com/yoannmoinet/nipplejs/commit/9a8a7b4)), closes [#109](https://github.com/yoannmoinet/nipplejs/issues/109)
|
||||
* reset direction when below the threshold ([6f41b38](https://github.com/yoannmoinet/nipplejs/commit/6f41b38)), closes [#110](https://github.com/yoannmoinet/nipplejs/issues/110)
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* add an options to use with dynamic pages ([8258501](https://github.com/yoannmoinet/nipplejs/commit/8258501))
|
||||
* add raw data on move for data-only usage ([c818fb2](https://github.com/yoannmoinet/nipplejs/commit/c818fb2)), closes [#54](https://github.com/yoannmoinet/nipplejs/issues/54)
|
||||
* add unit vector representation to move event output ([a4496fe](https://github.com/yoannmoinet/nipplejs/commit/a4496fe))
|
||||
* upgrade dev experience with webpack and es6 ([cc1e824](https://github.com/yoannmoinet/nipplejs/commit/cc1e824))
|
||||
|
||||
|
||||
|
||||
<a name="0.7.3"></a>
|
||||
## [0.7.3](https://github.com/yoannmoinet/nipplejs/compare/v0.7.2...v0.7.3) (2018-12-11)
|
||||
|
||||
|
||||
|
||||
<a name="0.7.2"></a>
|
||||
## [0.7.2](https://github.com/yoannmoinet/nipplejs/compare/v0.7.1...v0.7.2) (2018-12-11)
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* Add TypeScript Definitions ([#85](https://github.com/yoannmoinet/nipplejs/issues/85)) ([0b1f4ae](https://github.com/yoannmoinet/nipplejs/commit/0b1f4ae)), closes [#21](https://github.com/yoannmoinet/nipplejs/issues/21)
|
||||
|
||||
|
||||
|
||||
<a name="0.7.1"></a>
|
||||
## [0.7.1](https://github.com/yoannmoinet/nipplejs/compare/v0.7.0...v0.7.1) (2018-06-06)
|
||||
|
||||
|
||||
|
||||
<a name="0.7.0"></a>
|
||||
# [0.7.0](https://github.com/yoannmoinet/nipplejs/compare/v0.6.8...v0.7.0) (2018-06-06)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* register touchcancel and pointercancel events ([2c541a6](https://github.com/yoannmoinet/nipplejs/commit/2c541a6))
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* **joystick:** add lockX and lockY options ([6baba97](https://github.com/yoannmoinet/nipplejs/commit/6baba97))
|
||||
|
||||
|
||||
|
||||
<a name="0.6.8"></a>
|
||||
## [0.6.8](https://github.com/yoannmoinet/nipplejs/compare/v0.6.7...v0.6.8) (2017-12-19)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* add touchcancel handling as touchend for events coming from outside ([ebc501e](https://github.com/yoannmoinet/nipplejs/commit/ebc501e)), closes [#61](https://github.com/yoannmoinet/nipplejs/issues/61) [#57](https://github.com/yoannmoinet/nipplejs/issues/57) [#33](https://github.com/yoannmoinet/nipplejs/issues/33) [#31](https://github.com/yoannmoinet/nipplejs/issues/31) [#30](https://github.com/yoannmoinet/nipplejs/issues/30)
|
||||
* update manager with changing identifier ([45ec1d7](https://github.com/yoannmoinet/nipplejs/commit/45ec1d7)), closes [#64](https://github.com/yoannmoinet/nipplejs/issues/64)
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* add restJoystick option ([55b6482](https://github.com/yoannmoinet/nipplejs/commit/55b6482))
|
||||
|
||||
|
||||
|
||||
<a name="0.6.7"></a>
|
||||
## [0.6.7](https://github.com/yoannmoinet/nipplejs/compare/v0.6.6...v0.6.7) (2016-10-27)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **events:** trigger events with the correct id and not identifier ([17f0fe6](https://github.com/yoannmoinet/nipplejs/commit/17f0fe6))
|
||||
* **identifier:** better identifier management ([ff44916](https://github.com/yoannmoinet/nipplejs/commit/ff44916))
|
||||
* update dependencies ([73bcda9](https://github.com/yoannmoinet/nipplejs/commit/73bcda9))
|
||||
|
||||
|
||||
|
||||
<a name="0.6.6"></a>
|
||||
## [0.6.6](https://github.com/yoannmoinet/nipplejs/compare/v0.6.5...v0.6.6) (2016-08-23)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **bin:** adapt slashes to windows if needed ([7dffd7c](https://github.com/yoannmoinet/nipplejs/commit/7dffd7c))
|
||||
* **bin:** add missing space ([48f6a1f](https://github.com/yoannmoinet/nipplejs/commit/48f6a1f))
|
||||
* **bin:** make the copyToGhPages script windows compatible ([11da89a](https://github.com/yoannmoinet/nipplejs/commit/11da89a))
|
||||
* **dataOnly:** conserve chainability even with dataOnly ([d1eddd0](https://github.com/yoannmoinet/nipplejs/commit/d1eddd0))
|
||||
|
||||
|
||||
|
||||
<a name="0.6.5"></a>
|
||||
## [0.6.5](https://github.com/yoannmoinet/nipplejs/compare/v0.6.4...v0.6.5) (2016-08-15)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **collection:** avoid any native touch action on the `options.zone` ([bea2c42](https://github.com/yoannmoinet/nipplejs/commit/bea2c42))
|
||||
|
||||
|
||||
|
||||
<a name="0.6.4"></a>
|
||||
## [0.6.4](https://github.com/yoannmoinet/nipplejs/compare/v0.6.3...v0.6.4) (2016-07-20)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **nipple:** remove size of container and apply on children only ([0033342](https://github.com/yoannmoinet/nipplejs/commit/0033342)), closes [#32](https://github.com/yoannmoinet/nipplejs/issues/32)
|
||||
|
||||
|
||||
|
||||
<a name="0.6.3"></a>
|
||||
## [0.6.3](https://github.com/yoannmoinet/nipplejs/compare/v0.6.2...v0.6.3) (2016-05-29)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **manager:** add missing closing bracket ([9b99637](https://github.com/yoannmoinet/nipplejs/commit/9b99637))
|
||||
* **resize:** listen to resize via event instead of global handler ([14c28f1](https://github.com/yoannmoinet/nipplejs/commit/14c28f1))
|
||||
|
||||
|
||||
|
||||
<a name="0.6.2"></a>
|
||||
## [0.6.2](https://github.com/yoannmoinet/nipplejs/compare/v0.6.1...v0.6.2) (2015-12-31)
|
||||
|
||||
|
||||
|
||||
<a name="0.6.1"></a>
|
||||
## [0.6.1](https://github.com/yoannmoinet/nipplejs/compare/v0.6.0...v0.6.1) (2015-12-26)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **collection:** trigger `start` event before any potential direction ([c5441fd](https://github.com/yoannmoinet/nipplejs/commit/c5441fd))
|
||||
* **nipple:** fragment control of previous directions ([790fa26](https://github.com/yoannmoinet/nipplejs/commit/790fa26)), closes [#25](https://github.com/yoannmoinet/nipplejs/issues/25)
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* **nipple:** add `resetDirection()` to cancel previous directions ([66f6e3b](https://github.com/yoannmoinet/nipplejs/commit/66f6e3b))
|
||||
|
||||
|
||||
|
||||
<a name="0.6.0"></a>
|
||||
# [0.6.0](https://github.com/yoannmoinet/nipplejs/compare/v0.5.6...v0.6.0) (2015-11-29)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* clean identifier if not found in any collection ([3496395](https://github.com/yoannmoinet/nipplejs/commit/3496395))
|
||||
* handle scrolling offset by resetting zone's box ([6ccd0b5](https://github.com/yoannmoinet/nipplejs/commit/6ccd0b5))
|
||||
* remove useless injections ([a0b1d7e](https://github.com/yoannmoinet/nipplejs/commit/a0b1d7e))
|
||||
* return the found nipple in `get()` ([439aa69](https://github.com/yoannmoinet/nipplejs/commit/439aa69))
|
||||
* unbind document when collection is manually destroyed ([6e66b62](https://github.com/yoannmoinet/nipplejs/commit/6e66b62))
|
||||
* **nipple:** call off() after triggering ([bf8e5c3](https://github.com/yoannmoinet/nipplejs/commit/bf8e5c3))
|
||||
* **nipple:** only trigger itself, not its manager ([6b39786](https://github.com/yoannmoinet/nipplejs/commit/6b39786))
|
||||
* **super:** move internal declarations where needed ([a4c79c2](https://github.com/yoannmoinet/nipplejs/commit/a4c79c2))
|
||||
* **utils:** return object on u.extend ([9197c00](https://github.com/yoannmoinet/nipplejs/commit/9197c00))
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* **nipple:** add an incremental id to absolutely differentiate each ([598a5eb](https://github.com/yoannmoinet/nipplejs/commit/598a5eb))
|
||||
* **utils:** add u.map to execute fn in array or single element ([515aa5d](https://github.com/yoannmoinet/nipplejs/commit/515aa5d))
|
||||
* **utils:** add u.safeExtend to only replace existent attributes ([5212ffe](https://github.com/yoannmoinet/nipplejs/commit/5212ffe))
|
||||
|
||||
|
||||
### Performance Improvements
|
||||
|
||||
* safety clean if nipple isn't found in collection ([ca20985](https://github.com/yoannmoinet/nipplejs/commit/ca20985))
|
||||
|
||||
|
||||
|
||||
<a name="0.5.6"></a>
|
||||
## [0.5.6](https://github.com/yoannmoinet/nipplejs/compare/v0.5.5...v0.5.6) (2015-11-09)
|
||||
|
||||
|
||||
|
||||
<a name="0.5.5"></a>
|
||||
## [0.5.5](https://github.com/yoannmoinet/nipplejs/compare/v0.5.4...v0.5.5) (2015-11-09)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **manager:** allow multitouch to be more than 1 ([7569536](https://github.com/yoannmoinet/nipplejs/commit/7569536))
|
||||
* **manager:** clean the start process, no duplicate ([7e30551](https://github.com/yoannmoinet/nipplejs/commit/7e30551))
|
||||
* **manager:** remove handler only if last touch ([1f03064](https://github.com/yoannmoinet/nipplejs/commit/1f03064))
|
||||
|
||||
|
||||
|
||||
<a name="0.5.4"></a>
|
||||
## [0.5.4](https://github.com/yoannmoinet/nipplejs/compare/v0.5.3...v0.5.4) (2015-11-08)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **manager:** better handle identifiers ([54b3cff](https://github.com/yoannmoinet/nipplejs/commit/54b3cff)), closes [#16](https://github.com/yoannmoinet/nipplejs/issues/16)
|
||||
* **nipple:** use `document.body.contains` for IE11 doesn't shortcut ([6e5b80a](https://github.com/yoannmoinet/nipplejs/commit/6e5b80a)), closes [#17](https://github.com/yoannmoinet/nipplejs/issues/17)
|
||||
|
||||
|
||||
|
||||
<a name="0.5.3"></a>
|
||||
## [0.5.3](https://github.com/yoannmoinet/nipplejs/compare/v0.5.2...v0.5.3) (2015-10-04)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **manager:** add back pressure variable... oups ([a46982f](https://github.com/yoannmoinet/nipplejs/commit/a46982f))
|
||||
|
||||
|
||||
|
||||
<a name="0.5.2"></a>
|
||||
## [0.5.2](https://github.com/yoannmoinet/nipplejs/compare/v0.5.1...v0.5.2) (2015-10-04)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **manager:** correctly unbind all events when destroying manager ([e3f96ef](https://github.com/yoannmoinet/nipplejs/commit/e3f96ef))
|
||||
* **utils:** handle touch based on their event's type ([406a7b2](https://github.com/yoannmoinet/nipplejs/commit/406a7b2))
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* **manager:** better pressure management cross-plateform ([d867812](https://github.com/yoannmoinet/nipplejs/commit/d867812))
|
||||
|
||||
|
||||
|
||||
<a name="0.5.1"></a>
|
||||
## [0.5.1](https://github.com/yoannmoinet/nipplejs/compare/v0.5.0...v0.5.1) (2015-10-03)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **nipple:** remove useless backPosition ([4c76adc](https://github.com/yoannmoinet/nipplejs/commit/4c76adc))
|
||||
* **super:** better inheritance ([4a3a8dc](https://github.com/yoannmoinet/nipplejs/commit/4a3a8dc))
|
||||
|
||||
|
||||
|
||||
<a name="0.5.0"></a>
|
||||
# [0.5.0](https://github.com/yoannmoinet/nipplejs/compare/v0.4.2...v0.5.0) (2015-09-29)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **manager:** add default pressure at 0 ([1cb31d0](https://github.com/yoannmoinet/nipplejs/commit/1cb31d0))
|
||||
* **nipple:** control dom presence before add or remove ([7cc1d8c](https://github.com/yoannmoinet/nipplejs/commit/7cc1d8c))
|
||||
* **nipple:** return the manager's known object in event triggers ([2deb42c](https://github.com/yoannmoinet/nipplejs/commit/2deb42c))
|
||||
* remove useless rimraf ([26db70f](https://github.com/yoannmoinet/nipplejs/commit/26db70f))
|
||||
* **npm:** add rimraf as a dev dependency ([deb7acc](https://github.com/yoannmoinet/nipplejs/commit/deb7acc)), closes [#12](https://github.com/yoannmoinet/nipplejs/issues/12)
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* **manager:** handle resize and reinit positions ([261fb59](https://github.com/yoannmoinet/nipplejs/commit/261fb59))
|
||||
* **nipple:** remove position offset ([be59bc4](https://github.com/yoannmoinet/nipplejs/commit/be59bc4))
|
||||
* add dataOnly option ([2f527b1](https://github.com/yoannmoinet/nipplejs/commit/2f527b1))
|
||||
* add two modes, static and semi ([347feaa](https://github.com/yoannmoinet/nipplejs/commit/347feaa))
|
||||
* **manager:** add destroy method ([295654f](https://github.com/yoannmoinet/nipplejs/commit/295654f))
|
||||
* **manager:** expose nippleOptions ([968103c](https://github.com/yoannmoinet/nipplejs/commit/968103c))
|
||||
* **nipple:** add destroy method ([713e505](https://github.com/yoannmoinet/nipplejs/commit/713e505))
|
||||
* **off:** allow unsubscribing on all events at once ([c30bfad](https://github.com/yoannmoinet/nipplejs/commit/c30bfad))
|
||||
|
||||
|
||||
|
||||
<a name="0.4.2"></a>
|
||||
## [0.4.2](https://github.com/yoannmoinet/nipplejs/compare/v0.4.1...v0.4.2) (2015-09-15)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* correctly return directions ([871d782](https://github.com/yoannmoinet/nipplejs/commit/871d782))
|
||||
|
||||
|
||||
|
||||
<a name="0.4.1"></a>
|
||||
## [0.4.1](https://github.com/yoannmoinet/nipplejs/compare/v0.4.0...v0.4.1) (2015-09-15)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* return the computed direction ([b3d80b3](https://github.com/yoannmoinet/nipplejs/commit/b3d80b3))
|
||||
|
||||
|
||||
|
||||
<a name="0.4.0"></a>
|
||||
# [0.4.0](https://github.com/yoannmoinet/nipplejs/compare/v0.3.1...v0.4.0) (2015-09-15)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **manager:** streamline events triggered ([76941ec](https://github.com/yoannmoinet/nipplejs/commit/76941ec))
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* **nipple:** add a callback after show and hide ([5b24124](https://github.com/yoannmoinet/nipplejs/commit/5b24124))
|
||||
* **nipple:** add the positions to the instance ([fac981b](https://github.com/yoannmoinet/nipplejs/commit/fac981b))
|
||||
* **off:** allow unsubscribing of a type at once ([cbbefca](https://github.com/yoannmoinet/nipplejs/commit/cbbefca))
|
||||
* **on:** pass the target in the event ([bc0630d](https://github.com/yoannmoinet/nipplejs/commit/bc0630d))
|
||||
* add more events for both nipple and manager ([f7966b9](https://github.com/yoannmoinet/nipplejs/commit/f7966b9))
|
||||
* add support for both mouse and touch at the same time ([e8fcba2](https://github.com/yoannmoinet/nipplejs/commit/e8fcba2))
|
||||
* add support for pressure ([80e7770](https://github.com/yoannmoinet/nipplejs/commit/80e7770)), closes [#10](https://github.com/yoannmoinet/nipplejs/issues/10)
|
||||
* attach values to each instance of nipple ([c5bf9ab](https://github.com/yoannmoinet/nipplejs/commit/c5bf9ab))
|
||||
* limit the number of simultaneous nipples ([801e91d](https://github.com/yoannmoinet/nipplejs/commit/801e91d))
|
||||
* support multitouch correctly ([33bbe23](https://github.com/yoannmoinet/nipplejs/commit/33bbe23)), closes [#2](https://github.com/yoannmoinet/nipplejs/issues/2) [#6](https://github.com/yoannmoinet/nipplejs/issues/6)
|
||||
|
||||
|
||||
|
||||
<a name="0.3.1"></a>
|
||||
## [0.3.1](https://github.com/yoannmoinet/nipplejs/compare/v0.3.0...v0.3.1) (2015-09-07)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **on:** allows multiple spaces in event string ([b89bd0e](https://github.com/yoannmoinet/nipplejs/commit/b89bd0e))
|
||||
* **on:** removes variable name clash. ([3d70a3c](https://github.com/yoannmoinet/nipplejs/commit/3d70a3c))
|
||||
|
||||
|
||||
|
||||
<a name="0.3.0"></a>
|
||||
# [0.3.0](https://github.com/yoannmoinet/nipplejs/compare/v0.2.1...v0.3.0) (2015-09-06)
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* offset angle by 180 for units circle ([3002014](https://github.com/yoannmoinet/nipplejs/commit/3002014))
|
||||
* support IE PointerEvents ([ed65d1e](https://github.com/yoannmoinet/nipplejs/commit/ed65d1e)), closes [#1](https://github.com/yoannmoinet/nipplejs/issues/1)
|
||||
|
||||
|
||||
|
||||
<a name="0.2.1"></a>
|
||||
## [0.2.1](https://github.com/yoannmoinet/nipplejs/compare/v0.2.0...v0.2.1) (2015-09-06)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* correct chrome's clientBoundingBox ([b94bc43](https://github.com/yoannmoinet/nipplejs/commit/b94bc43))
|
||||
|
||||
|
||||
|
||||
<a name="0.2.0"></a>
|
||||
# [0.2.0](https://github.com/yoannmoinet/nipplejs/compare/v0.1.1...v0.2.0) (2015-09-06)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* **on:** return self to allow chain ([f068cc9](https://github.com/yoannmoinet/nipplejs/commit/f068cc9))
|
||||
|
||||
|
||||
### Features
|
||||
|
||||
* **on:** let listen to multiple events ([d19ad97](https://github.com/yoannmoinet/nipplejs/commit/d19ad97))
|
||||
* **on, off:** allow to chain calls ([c82c580](https://github.com/yoannmoinet/nipplejs/commit/c82c580))
|
||||
* **trigger:** trigger only if different direction ([9e334ba](https://github.com/yoannmoinet/nipplejs/commit/9e334ba))
|
||||
|
||||
|
||||
|
||||
<a name="0.1.1"></a>
|
||||
## [0.1.1](https://github.com/yoannmoinet/nipplejs/compare/v0.1.0...v0.1.1) (2015-09-06)
|
||||
|
||||
|
||||
### Bug Fixes
|
||||
|
||||
* add scroll offset ([7b36fb6](https://github.com/yoannmoinet/nipplejs/commit/7b36fb6))
|
||||
* remove useless log ([b958cbf](https://github.com/yoannmoinet/nipplejs/commit/b958cbf))
|
||||
* send data to start event ([c1f1688](https://github.com/yoannmoinet/nipplejs/commit/c1f1688))
|
||||
|
||||
|
||||
|
||||
<a name="0.1.0"></a>
|
||||
# 0.1.0 (2015-09-05)
|
||||
|
||||
|
||||
|
||||
+22
@@ -0,0 +1,22 @@
|
||||
The MIT License (MIT)
|
||||
|
||||
Copyright (c) 2014 Yoann Moinet <yoann.moinet@gmail.com>
|
||||
|
||||
Permission is hereby granted, free of charge, to any person obtaining a copy
|
||||
of this software and associated documentation files (the "Software"), to deal
|
||||
in the Software without restriction, including without limitation the rights
|
||||
to use, copy, modify, merge, publish, distribute, sublicense, and/or sell
|
||||
copies of the Software, and to permit persons to whom the Software is
|
||||
furnished to do so, subject to the following conditions:
|
||||
|
||||
The above copyright notice and this permission notice shall be included in all
|
||||
copies or substantial portions of the Software.
|
||||
|
||||
THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR
|
||||
IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY,
|
||||
FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE
|
||||
AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER
|
||||
LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM,
|
||||
OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN THE
|
||||
SOFTWARE.
|
||||
|
||||
+631
@@ -0,0 +1,631 @@
|
||||

|
||||
> A vanilla virtual joystick for touch capable interfaces
|
||||
|
||||
|
||||
[](https://npmjs.org/package/nipplejs)
|
||||
[](https://npmjs.org/package/nipplejs)
|
||||
|
||||
# Table Of Contents
|
||||
<details>
|
||||
|
||||
<!-- toc -->
|
||||
|
||||
- [Install](#install)
|
||||
- [Demo](#demo)
|
||||
- [Usage](#usage)
|
||||
- [Options](#options)
|
||||
* [`options.zone` defaults to 'body'](#optionszone-defaults-to-body)
|
||||
* [`options.color` defaults to 'white'](#optionscolor-defaults-to-white)
|
||||
* [`options.size` defaults to 100](#optionssize-defaults-to-100)
|
||||
* [`options.threshold` defaults to 0.1](#optionsthreshold-defaults-to-01)
|
||||
* [`options.fadeTime` defaults to 250](#optionsfadetime-defaults-to-250)
|
||||
* [`options.multitouch` defaults to false](#optionsmultitouch-defaults-to-false)
|
||||
* [`options.maxNumberOfNipples` defaults to 1](#optionsmaxnumberofnipples-defaults-to-1)
|
||||
* [`options.dataOnly` defaults to false](#optionsdataonly-defaults-to-false)
|
||||
* [`options.position` defaults to `{top: 0, left: 0}`](#optionsposition-defaults-to-top-0-left-0)
|
||||
* [`options.mode` defaults to 'dynamic'.](#optionsmode-defaults-to-dynamic)
|
||||
+ [`'dynamic'`](#dynamic)
|
||||
+ [`'semi'`](#semi)
|
||||
+ [`'static'`](#static)
|
||||
* [`options.restJoystick` defaults to true](#optionsrestjoystick-defaults-to-true)
|
||||
* [`options.restOpacity` defaults to 0.5](#optionsrestopacity-defaults-to-05)
|
||||
* [`options.catchDistance` defaults to 200](#optionscatchdistance-defaults-to-200)
|
||||
- [API](#api)
|
||||
* [NippleJS instance (manager)](#nipplejs-instance-manager)
|
||||
+ [`manager.on(type, handler)`](#managerontype-handler)
|
||||
+ [`manager.off([type, handler])`](#managerofftype-handler)
|
||||
+ [`manager.get(identifier)`](#managergetidentifier)
|
||||
+ [`manager.destroy()`](#managerdestroy)
|
||||
+ [`manager.ids`](#managerids)
|
||||
+ [`manager.id`](#managerid)
|
||||
* [nipple instance (joystick)](#nipple-instance-joystick)
|
||||
* [`joystick.on`, `joystick.off`](#joystickon-joystickoff)
|
||||
* [`joystick.el`](#joystickel)
|
||||
* [`joystick.show([cb])`](#joystickshowcb)
|
||||
* [`joystick.hide([cb])`](#joystickhidecb)
|
||||
* [`joystick.add()`](#joystickadd)
|
||||
* [`joystick.remove()`](#joystickremove)
|
||||
* [`joystick.destroy()`](#joystickdestroy)
|
||||
* [`joystick.setPosition(cb, { x, y })`](#joysticksetpositioncb--x-y-)
|
||||
* [`joystick.identifier`](#joystickidentifier)
|
||||
* [`joystick.trigger(type [, data])`](#joysticktriggertype--data)
|
||||
* [`joystick.position`](#joystickposition)
|
||||
* [`joystick.frontPosition`](#joystickfrontposition)
|
||||
* [`joystick.ui`](#joystickui)
|
||||
- [Events](#events)
|
||||
* [manager only](#manager-only)
|
||||
+ [`added`](#added)
|
||||
+ [`removed`](#removed)
|
||||
* [manager and joysticks](#manager-and-joysticks)
|
||||
+ [`start`](#start)
|
||||
+ [`end`](#end)
|
||||
+ [`move`](#move)
|
||||
+ [`dir`](#dir)
|
||||
+ [`plain`](#plain)
|
||||
+ [`shown`](#shown)
|
||||
+ [`hidden`](#hidden)
|
||||
+ [`destroyed`](#destroyed)
|
||||
+ [`pressure`](#pressure)
|
||||
- [Contributing](#contributing)
|
||||
+ [Commits](#commits)
|
||||
+ [Style](#style)
|
||||
+ [Workflow](#workflow)
|
||||
+ [Build](#build)
|
||||
|
||||
<!-- tocstop -->
|
||||
</details>
|
||||
|
||||
## Install
|
||||
|
||||
```bash
|
||||
npm install nipplejs --save
|
||||
```
|
||||
|
||||
----
|
||||
|
||||
## Demo
|
||||
Check out the [demo here](http://yoannmoinet.github.io/nipplejs/#demo).
|
||||
|
||||
----
|
||||
|
||||
## Usage
|
||||
|
||||
Import it the way you want into your project :
|
||||
|
||||
```javascript
|
||||
// CommonJS
|
||||
var manager = require('nipplejs').create(options);
|
||||
```
|
||||
|
||||
```javascript
|
||||
// AMD
|
||||
define(['nipplejs'], function (nipplejs) {
|
||||
var manager = nipplejs.create(options);
|
||||
});
|
||||
```
|
||||
|
||||
```javascript
|
||||
// Module
|
||||
import nipplejs from 'nipplejs';
|
||||
```
|
||||
|
||||
```html
|
||||
<!-- Global -->
|
||||
<script src="./nipplejs.js"></script>
|
||||
<script>
|
||||
var manager = nipplejs.create(options);
|
||||
</script>
|
||||
```
|
||||
|
||||
**:warning: NB :warning:** Your joystick's container **has** to have its CSS `position` property set, either `absolute`, `relative`, `static`, ....
|
||||
|
||||
----
|
||||
|
||||
## Options
|
||||
You can configure your joystick in different ways :
|
||||
|
||||
```javascript
|
||||
var options = {
|
||||
zone: Element, // active zone
|
||||
color: String,
|
||||
size: Integer,
|
||||
threshold: Float, // before triggering a directional event
|
||||
fadeTime: Integer, // transition time
|
||||
multitouch: Boolean,
|
||||
maxNumberOfNipples: Number, // when multitouch, what is too many?
|
||||
dataOnly: Boolean, // no dom element whatsoever
|
||||
position: Object, // preset position for 'static' mode
|
||||
mode: String, // 'dynamic', 'static' or 'semi'
|
||||
restJoystick: Boolean,
|
||||
restOpacity: Number, // opacity when not 'dynamic' and rested
|
||||
lockX: Boolean, // only move on the X axis
|
||||
lockY: Boolean, // only move on the Y axis
|
||||
catchDistance: Number, // distance to recycle previous joystick in
|
||||
// 'semi' mode
|
||||
dynamicPage: Boolean, // Enable if the page has dynamically visible elements
|
||||
};
|
||||
```
|
||||
|
||||
All options are optional :sunglasses:.
|
||||
|
||||
### `options.zone` defaults to 'body'
|
||||
The dom element in which all your joysticks will be injected.
|
||||
|
||||
```html
|
||||
<div id="zone_joystick"></div>
|
||||
|
||||
<script type="text/javascript" src="./nipplejs.js"></script>
|
||||
<script type="text/javascript">
|
||||
var options = {
|
||||
zone: document.getElementById('zone_joystick'),
|
||||
};
|
||||
var manager = nipplejs.create(options);
|
||||
</script>
|
||||
```
|
||||
|
||||
This zone also serve as the mouse/touch events handler.
|
||||
|
||||
It represents the zone where all your joysticks will be active.
|
||||
|
||||
### `options.color` defaults to 'white'
|
||||
The background color of your joystick's elements.
|
||||
|
||||
Can be any valid CSS color.
|
||||
|
||||
### `options.size` defaults to 100
|
||||
The size in pixel of the outer circle.
|
||||
|
||||
The inner circle is 50% of this size.
|
||||
|
||||
### `options.threshold` defaults to 0.1
|
||||
This is the strength needed to trigger a directional event.
|
||||
|
||||
Basically, the center is 0 and the outer is 1.
|
||||
|
||||
You need to at least go to 0.1 to trigger a directional event.
|
||||
|
||||
### `options.fadeTime` defaults to 250
|
||||
The time it takes for joystick to fade-out and fade-in when activated or de-activated.
|
||||
|
||||
### `options.multitouch` defaults to false
|
||||
Enable the multitouch capabilities.
|
||||
|
||||
If, for reasons, you need to have multiple nipples in the same zone.
|
||||
|
||||
Otherwise, it will only get one, and all new touches won't do a thing.
|
||||
|
||||
Please note that multitouch is off when in `static` or `semi` modes.
|
||||
|
||||
### `options.maxNumberOfNipples` defaults to 1
|
||||
If you need to, you can also control the maximum number of instances that could be created.
|
||||
|
||||
Obviously in a multitouch configuration.
|
||||
|
||||
### `options.dataOnly` defaults to false
|
||||
The library won't draw anything in the DOM and will only trigger events with data.
|
||||
|
||||
### `options.position` defaults to `{top: 0, left: 0}`
|
||||
An object that will determine the position of a `static` mode.
|
||||
|
||||
You can pass any of the four `top`, `right`, `bottom` and `left`.
|
||||
|
||||
They will be applied as any css property.
|
||||
|
||||
Ex :
|
||||
- `{top: '50px', left: '50px'}`
|
||||
- `{left: '10%', bottom: '10%'}`
|
||||
|
||||
### `options.mode` defaults to 'dynamic'.
|
||||
Three modes are possible :
|
||||
|
||||
#### `'dynamic'`
|
||||
- a new joystick is created at each new touch.
|
||||
- the joystick gets destroyed when released.
|
||||
- **can** be multitouch.
|
||||
|
||||
#### `'semi'`
|
||||
- new joystick is created at each new touch farther than `options.catchDistance` of any previously created joystick.
|
||||
- the joystick is faded-out when released but not destroyed.
|
||||
- when touch is made **inside** the `options.catchDistance` a new direction is triggered immediately.
|
||||
- when touch is made **outside** the `options.catchDistance` the previous joystick is destroyed and a new one is created.
|
||||
- **cannot** be multitouch.
|
||||
|
||||
#### `'static'`
|
||||
- a joystick is positioned immediately at `options.position`.
|
||||
- one joystick per zone.
|
||||
- each new touch triggers a new direction.
|
||||
- **cannot** be multitouch.
|
||||
|
||||
### `options.restJoystick` defaults to true
|
||||
Reset the joystick's position when it enters the rest state.
|
||||
|
||||
### `options.restOpacity` defaults to 0.5
|
||||
The opacity to apply when the joystick is in a rest position.
|
||||
|
||||
### `options.catchDistance` defaults to 200
|
||||
This is only useful in the `semi` mode, and determine at which distance we recycle the previous joystick.
|
||||
|
||||
At 200 (px), if you press the zone into a rayon of 200px around the previously displayed joystick,
|
||||
it will act as a `static` one.
|
||||
|
||||
### `options.lockX` defaults to false
|
||||
Locks joystick's movement to the x (horizontal) axis
|
||||
|
||||
### `options.lockY` defaults to false
|
||||
Locks joystick's movement to the y (vertical) axis
|
||||
|
||||
### `options.dynamicPage` defaults to true
|
||||
Enable if the page has dynamically visible elements such as for Vue, React, Angular or simply some CSS hiding or showing some DOM.
|
||||
|
||||
----
|
||||
|
||||
## API
|
||||
|
||||
### NippleJS instance (manager)
|
||||
|
||||
Your manager has the following signature :
|
||||
|
||||
```javascript
|
||||
{
|
||||
on: Function, // handle internal event
|
||||
off: Function, // un-handle internal event
|
||||
get: Function, // get a specific joystick
|
||||
destroy: Function, // destroy everything
|
||||
ids: Array // array of assigned ids
|
||||
id: Number // id of the manager
|
||||
options: {
|
||||
zone: Element, // reactive zone
|
||||
multitouch: Boolean,
|
||||
maxNumberOfNipples: Number,
|
||||
mode: String,
|
||||
position: Object,
|
||||
catchDistance: Number,
|
||||
size: Number,
|
||||
threshold: Number,
|
||||
color: String,
|
||||
fadeTime: Number,
|
||||
dataOnly: Boolean,
|
||||
restJoystick: Boolean,
|
||||
restOpacity: Number
|
||||
}
|
||||
}
|
||||
```
|
||||
|
||||
#### `manager.on(type, handler)`
|
||||
|
||||
If you wish to listen to internal events like :
|
||||
|
||||
```javascript
|
||||
manager.on('event#1 event#2', function (evt, data) {
|
||||
// Do something.
|
||||
});
|
||||
```
|
||||
|
||||
Note that you can listen to multiple events at once by separating
|
||||
them either with a space or a comma (or both, I don't care).
|
||||
|
||||
#### `manager.off([type, handler])`
|
||||
|
||||
To remove an event handler :
|
||||
|
||||
```javascript
|
||||
manager.off('event', handler);
|
||||
```
|
||||
|
||||
If you call off without arguments, all handlers will be removed.
|
||||
|
||||
If you don't specify the handler but just a type, all handlers for that type will be removed.
|
||||
|
||||
#### `manager.get(identifier)`
|
||||
|
||||
A helper to get an instance via its identifier.
|
||||
|
||||
```javascript
|
||||
// Will return the nipple instantiated by the touch identified by 0
|
||||
manager.get(0);
|
||||
```
|
||||
|
||||
#### `manager.destroy()`
|
||||
|
||||
Gently remove all nipples from the DOM and unbind all events.
|
||||
|
||||
```javascript
|
||||
manager.destroy();
|
||||
```
|
||||
|
||||
#### `manager.ids`
|
||||
|
||||
The array of nipples' ids under this manager.
|
||||
|
||||
#### `manager.id`
|
||||
|
||||
The incremented id of this manager.
|
||||
|
||||
### nipple instance (joystick)
|
||||
|
||||
Each joystick has the following signature :
|
||||
|
||||
```javascript
|
||||
{
|
||||
on: Function,
|
||||
off: Function,
|
||||
el: Element,
|
||||
show: Function, // fade-in
|
||||
hide: Function, // fade-out
|
||||
add: Function, // inject into dom
|
||||
remove: Function, // remove from dom
|
||||
destroy: Function,
|
||||
setPosition: Function,
|
||||
identifier: Number,
|
||||
trigger: Function,
|
||||
position: { // position of the center
|
||||
x: Number,
|
||||
y: Number
|
||||
},
|
||||
frontPosition: { // position of the front part
|
||||
x: Number,
|
||||
y: Number
|
||||
},
|
||||
ui: {
|
||||
el: Element,
|
||||
front: Element,
|
||||
back: Element
|
||||
},
|
||||
options: {
|
||||
color: String,
|
||||
size: Number,
|
||||
threshold: Number,
|
||||
fadeTime: Number
|
||||
}
|
||||
}
|
||||
```
|
||||
|
||||
### `joystick.on`, `joystick.off`
|
||||
|
||||
The same as the manager.
|
||||
|
||||
### `joystick.el`
|
||||
|
||||
Dom element in which the joystick gets created.
|
||||
|
||||
```html
|
||||
<div class="nipple">
|
||||
<div class="front"></div>
|
||||
<div class="back"></div>
|
||||
</div>
|
||||
```
|
||||
|
||||
### `joystick.show([cb])`
|
||||
|
||||
Will show the joystick at the last known place.
|
||||
|
||||
You can pass a callback that will be executed at the end of the fade-in animation.
|
||||
|
||||
### `joystick.hide([cb])`
|
||||
|
||||
Will fade-out the joystick.
|
||||
|
||||
You can pass a callback that will be executed at the end of the fade-out animation.
|
||||
|
||||
### `joystick.add()`
|
||||
|
||||
Add the joystick's element to the dom.
|
||||
|
||||
### `joystick.remove()`
|
||||
|
||||
Remove the joystick's element from the dom.
|
||||
|
||||
### `joystick.destroy()`
|
||||
|
||||
Gently remove this nipple from the DOM and unbind all related events.
|
||||
|
||||
### `joystick.setPosition(cb, { x, y })`
|
||||
|
||||
Set the joystick to the specified position, where x and y are distances away from the center in pixels. This does not trigger joystick events.
|
||||
|
||||
### `joystick.identifier`
|
||||
|
||||
Returns the unique identifier of the joystick.
|
||||
|
||||
Tied to its touch's identifier.
|
||||
|
||||
### `joystick.trigger(type [, data])`
|
||||
|
||||
Trigger an internal event from the joystick.
|
||||
|
||||
The same as `on` you can trigger multiple events at the same time.
|
||||
|
||||
### `joystick.position`
|
||||
|
||||
The absolute position of the center of the joystick.
|
||||
|
||||
### `joystick.frontPosition`
|
||||
|
||||
The absolute position of the back part of the joystick's ui.
|
||||
|
||||
### `joystick.ui`
|
||||
|
||||
The object that store its ui elements
|
||||
|
||||
```html
|
||||
{
|
||||
el: <div class="nipple"></div>
|
||||
back: <div class="back"></div>
|
||||
front: <div class="front"></div>
|
||||
}
|
||||
```
|
||||
|
||||
----
|
||||
|
||||
## Events
|
||||
|
||||
You can listen events both on the manager and all the joysticks.
|
||||
|
||||
But some of them are specific to its instance.
|
||||
|
||||
If you need to listen to each joystick, for example, you can :
|
||||
|
||||
```javascript
|
||||
manager.on('added', function (evt, nipple) {
|
||||
nipple.on('start move end dir plain', function (evt) {
|
||||
// DO EVERYTHING
|
||||
});
|
||||
}).on('removed', function (evt, nipple) {
|
||||
nipple.off('start move end dir plain');
|
||||
});
|
||||
```
|
||||
|
||||
### manager only
|
||||
|
||||
#### `added`
|
||||
|
||||
A joystick just got added.
|
||||
|
||||
Will pass the instance alongside the event.
|
||||
|
||||
#### `removed`
|
||||
|
||||
A joystick just got removed.
|
||||
|
||||
Fired at the end of the fade-out animation.
|
||||
|
||||
Will pass the instance alongside the event.
|
||||
|
||||
Won't be trigger in a `dataOnly` configuration.
|
||||
|
||||
### manager and joysticks
|
||||
|
||||
Other events are available on both the manager and joysticks.
|
||||
|
||||
When listening on the manager,
|
||||
you can also target **a joystick in particular** by prefixing
|
||||
the event with its identifier, **`0:start`** for example.
|
||||
|
||||
Else you'll get all events from all the joysticks.
|
||||
|
||||
#### `start`
|
||||
|
||||
A joystick is activated. (the user pressed on the active zone)
|
||||
|
||||
Will pass the instance alongside the event.
|
||||
|
||||
#### `end`
|
||||
|
||||
A joystick is de-activated. (the user released the active zone)
|
||||
|
||||
Will pass the instance alongside the event.
|
||||
|
||||
#### `move`
|
||||
|
||||
A joystick is moved.
|
||||
|
||||
Comes with data :
|
||||
|
||||
```javascript
|
||||
{
|
||||
identifier: 0, // the identifier of the touch/mouse that triggered it
|
||||
position: { // absolute position of the center in pixels
|
||||
x: 125,
|
||||
y: 95
|
||||
},
|
||||
force: 0.2, // strength in %
|
||||
distance: 25.4, // distance from center in pixels
|
||||
pressure: 0.1, // the pressure applied by the touch
|
||||
angle: {
|
||||
radian: 1.5707963268, // angle in radian
|
||||
degree: 90
|
||||
},
|
||||
vector: { // force unit vector
|
||||
x: 0.508,
|
||||
y: 3.110602869834277e-17
|
||||
},
|
||||
raw: { // note: angle is the same, beyond the 50 pixel limit
|
||||
distance: 25.4, // distance which continues beyond the 50 pixel limit
|
||||
position: { // position of the finger/mouse in pixels, beyond joystick limits
|
||||
x: 125,
|
||||
y: 95
|
||||
}
|
||||
},
|
||||
instance: Nipple // the nipple instance that triggered the event
|
||||
}
|
||||
```
|
||||
|
||||
#### `dir`
|
||||
|
||||
When a direction is reached after the threshold.
|
||||
|
||||
Direction are split with a 45° angle.
|
||||
|
||||
```javascript
|
||||
// \ UP /
|
||||
// \ /
|
||||
// LEFT RIGHT
|
||||
// / \
|
||||
// /DOWN \
|
||||
```
|
||||
|
||||
You can also listen to specific direction like :
|
||||
|
||||
- `dir:up`
|
||||
- `dir:down`
|
||||
- `dir:right`
|
||||
- `dir:left`
|
||||
|
||||
In this configuration only one direction is triggered at a time.
|
||||
|
||||
#### `plain`
|
||||
|
||||
When a plain direction is reached after the threshold.
|
||||
|
||||
Plain directions are split with a 90° angle.
|
||||
|
||||
```javascript
|
||||
// UP |
|
||||
// ------ LEFT | RIGHT
|
||||
// DOWN |
|
||||
```
|
||||
|
||||
You can also listen to specific plain direction like :
|
||||
|
||||
- `plain:up`
|
||||
- `plain:down`
|
||||
- `plain:right`
|
||||
- `plain:left`
|
||||
|
||||
In this configuration two directions can be triggered at a time,
|
||||
because the user could be both `up` and `left` for example.
|
||||
|
||||
#### `shown`
|
||||
|
||||
Is triggered at the end of the fade-in animation.
|
||||
|
||||
Will pass the instance alongside the event.
|
||||
|
||||
Won't be trigger in a `dataOnly` configuration.
|
||||
|
||||
#### `hidden`
|
||||
|
||||
Is triggered at the end of the fade-out animation.
|
||||
|
||||
Will pass the instance alongside the event.
|
||||
|
||||
Won't be trigger in a `dataOnly` configuration.
|
||||
|
||||
#### `destroyed`
|
||||
|
||||
Is triggered at the end of destroy.
|
||||
|
||||
Will pass the instance alongside the event.
|
||||
|
||||
#### `pressure`
|
||||
|
||||
> MBP's [**Force Touch**](http://www.apple.com/macbook-pro/features-retina/#interact), iOS's [**3D Touch**](http://www.apple.com/iphone-6s/3d-touch/), Microsoft's [**pressure**](https://msdn.microsoft.com/en-us/library/hh772360%28v=vs.85%29.aspx) or MDN's [**force**](https://developer.mozilla.org/en-US/docs/Web/API/Touch/force)
|
||||
|
||||
Is triggered when the pressure on the joystick is changed.
|
||||
|
||||
The value, between 0 and 1, is sent back alongside the event.
|
||||
|
||||
----
|
||||
|
||||
## Contributing
|
||||
You can follow [this document](./CONTRIBUTING.md) to help you get started.
|
||||
+1
File diff suppressed because one or more lines are too long
+89
@@ -0,0 +1,89 @@
|
||||
{
|
||||
"_from": "nipplejs",
|
||||
"_id": "nipplejs@0.8.5",
|
||||
"_inBundle": false,
|
||||
"_integrity": "sha512-2G7warzUh4jIdmzSIDRCeXJUl/QrZyJ0QwFgI0V1lM34HLNsIqEX6uY0NY4V3wBDHNsub3me1cbFb/FJpWE/5g==",
|
||||
"_location": "/nipplejs",
|
||||
"_phantomChildren": {},
|
||||
"_requested": {
|
||||
"type": "tag",
|
||||
"registry": true,
|
||||
"raw": "nipplejs",
|
||||
"name": "nipplejs",
|
||||
"escapedName": "nipplejs",
|
||||
"rawSpec": "",
|
||||
"saveSpec": null,
|
||||
"fetchSpec": "latest"
|
||||
},
|
||||
"_requiredBy": [
|
||||
"#USER",
|
||||
"/"
|
||||
],
|
||||
"_resolved": "https://registry.npmjs.org/nipplejs/-/nipplejs-0.8.5.tgz",
|
||||
"_shasum": "9b16bd1fc70afadc35b09355b86dad65d863bafa",
|
||||
"_spec": "nipplejs",
|
||||
"_where": "/root/catkin_ws/src/robot_gui_bridge/gui",
|
||||
"author": {
|
||||
"name": "Yoann Moinet",
|
||||
"email": "yo@nnmoi.net",
|
||||
"url": "https://yoannmoi.net"
|
||||
},
|
||||
"browser": "./dist/nipplejs.js",
|
||||
"bugs": {
|
||||
"url": "https://github.com/yoannmoinet/nipplejs/issues"
|
||||
},
|
||||
"bundleDependencies": false,
|
||||
"dependencies": {},
|
||||
"deprecated": false,
|
||||
"description": "A virtual joystick for touch capable interfaces",
|
||||
"devDependencies": {
|
||||
"@babel/core": "7.5.5",
|
||||
"@babel/preset-env": "7.5.5",
|
||||
"babel-loader": "8.0.6",
|
||||
"babel-plugin-add-module-exports": "1.0.2",
|
||||
"casperjs": "1.1.4",
|
||||
"concat-cli": "4.0.0",
|
||||
"conventional-changelog": "1.1.0",
|
||||
"eslint": "5.10.0",
|
||||
"eslint-loader": "2.2.1",
|
||||
"expect.js": "0.3.1",
|
||||
"markdown-toc": "1.2.0",
|
||||
"mocha": "5.2.0",
|
||||
"phantomjs-prebuilt": "2.1.16",
|
||||
"webpack": "4.39.2",
|
||||
"webpack-cli": "3.3.7",
|
||||
"webpack-dev-server": "3.8.0"
|
||||
},
|
||||
"directories": {
|
||||
"lib": "src",
|
||||
"test": "test",
|
||||
"example": "example"
|
||||
},
|
||||
"files": [
|
||||
"dist/*",
|
||||
"src/*",
|
||||
"types/*"
|
||||
],
|
||||
"homepage": "https://github.com/yoannmoinet/nipplejs",
|
||||
"license": "MIT",
|
||||
"main": "./dist/nipplejs.js",
|
||||
"module": "./src/index.js",
|
||||
"name": "nipplejs",
|
||||
"repository": {
|
||||
"type": "git",
|
||||
"url": "git+https://github.com/yoannmoinet/nipplejs.git"
|
||||
},
|
||||
"scripts": {
|
||||
"build": "webpack --config webpack.config.js",
|
||||
"build:dev": "webpack-dev-server --config webpack.config.js",
|
||||
"changelog": "node ./bin/changelog.js",
|
||||
"copyGh": "node ./bin/copyToGhPages.js",
|
||||
"postversion": "npm run changelog",
|
||||
"prepare": "NODE_ENV=production npm run build",
|
||||
"start": "npm run build:dev -- --progress --watch",
|
||||
"test": "casperjs test ./test/nipplejs.casper.js",
|
||||
"toc": "markdown-toc -i README.md"
|
||||
},
|
||||
"types": "./types/index.d.ts",
|
||||
"version": "0.8.5"
|
||||
}
|
||||
+579
@@ -0,0 +1,579 @@
|
||||
import Nipple from './nipple';
|
||||
import Super from './super';
|
||||
import * as u from './utils';
|
||||
|
||||
///////////////////////////
|
||||
/// THE COLLECTION ///
|
||||
///////////////////////////
|
||||
|
||||
function Collection (manager, options) {
|
||||
var self = this;
|
||||
self.nipples = [];
|
||||
self.idles = [];
|
||||
self.actives = [];
|
||||
self.ids = [];
|
||||
self.pressureIntervals = {};
|
||||
self.manager = manager;
|
||||
self.id = Collection.id;
|
||||
Collection.id += 1;
|
||||
|
||||
// Defaults
|
||||
self.defaults = {
|
||||
zone: document.body,
|
||||
multitouch: false,
|
||||
maxNumberOfNipples: 10,
|
||||
mode: 'dynamic',
|
||||
position: {top: 0, left: 0},
|
||||
catchDistance: 200,
|
||||
size: 100,
|
||||
threshold: 0.1,
|
||||
color: 'white',
|
||||
fadeTime: 250,
|
||||
dataOnly: false,
|
||||
restJoystick: true,
|
||||
restOpacity: 0.5,
|
||||
lockX: false,
|
||||
lockY: false,
|
||||
dynamicPage: false
|
||||
};
|
||||
|
||||
self.config(options);
|
||||
|
||||
// Overwrites
|
||||
if (self.options.mode === 'static' || self.options.mode === 'semi') {
|
||||
self.options.multitouch = false;
|
||||
}
|
||||
|
||||
if (!self.options.multitouch) {
|
||||
self.options.maxNumberOfNipples = 1;
|
||||
}
|
||||
|
||||
self.updateBox();
|
||||
self.prepareNipples();
|
||||
self.bindings();
|
||||
self.begin();
|
||||
|
||||
return self.nipples;
|
||||
}
|
||||
|
||||
Collection.prototype = new Super();
|
||||
Collection.constructor = Collection;
|
||||
Collection.id = 0;
|
||||
|
||||
Collection.prototype.prepareNipples = function () {
|
||||
var self = this;
|
||||
var nips = self.nipples;
|
||||
|
||||
// Public API Preparation.
|
||||
nips.on = self.on.bind(self);
|
||||
nips.off = self.off.bind(self);
|
||||
nips.options = self.options;
|
||||
nips.destroy = self.destroy.bind(self);
|
||||
nips.ids = self.ids;
|
||||
nips.id = self.id;
|
||||
nips.processOnMove = self.processOnMove.bind(self);
|
||||
nips.processOnEnd = self.processOnEnd.bind(self);
|
||||
nips.get = function (id) {
|
||||
if (id === undefined) {
|
||||
return nips[0];
|
||||
}
|
||||
for (var i = 0, max = nips.length; i < max; i += 1) {
|
||||
if (nips[i].identifier === id) {
|
||||
return nips[i];
|
||||
}
|
||||
}
|
||||
return false;
|
||||
};
|
||||
};
|
||||
|
||||
Collection.prototype.bindings = function () {
|
||||
var self = this;
|
||||
// Touch start event.
|
||||
self.bindEvt(self.options.zone, 'start');
|
||||
// Avoid native touch actions (scroll, zoom etc...) on the zone.
|
||||
self.options.zone.style.touchAction = 'none';
|
||||
self.options.zone.style.msTouchAction = 'none';
|
||||
};
|
||||
|
||||
Collection.prototype.begin = function () {
|
||||
var self = this;
|
||||
var opts = self.options;
|
||||
|
||||
// We place our static nipple
|
||||
// if needed.
|
||||
if (opts.mode === 'static') {
|
||||
var nipple = self.createNipple(
|
||||
opts.position,
|
||||
self.manager.getIdentifier()
|
||||
);
|
||||
// Add it to the dom.
|
||||
nipple.add();
|
||||
// Store it in idles.
|
||||
self.idles.push(nipple);
|
||||
}
|
||||
};
|
||||
|
||||
// Nipple Factory
|
||||
Collection.prototype.createNipple = function (position, identifier) {
|
||||
var self = this;
|
||||
var scroll = u.getScroll();
|
||||
var toPutOn = {};
|
||||
var opts = self.options;
|
||||
|
||||
if (position.x && position.y) {
|
||||
toPutOn = {
|
||||
x: position.x -
|
||||
(scroll.x + self.box.left),
|
||||
y: position.y -
|
||||
(scroll.y + self.box.top)
|
||||
};
|
||||
} else if (
|
||||
position.top ||
|
||||
position.right ||
|
||||
position.bottom ||
|
||||
position.left
|
||||
) {
|
||||
|
||||
// We need to compute the position X / Y of the joystick.
|
||||
var dumb = document.createElement('DIV');
|
||||
dumb.style.display = 'hidden';
|
||||
dumb.style.top = position.top;
|
||||
dumb.style.right = position.right;
|
||||
dumb.style.bottom = position.bottom;
|
||||
dumb.style.left = position.left;
|
||||
dumb.style.position = 'absolute';
|
||||
|
||||
opts.zone.appendChild(dumb);
|
||||
var dumbBox = dumb.getBoundingClientRect();
|
||||
opts.zone.removeChild(dumb);
|
||||
|
||||
toPutOn = position;
|
||||
position = {
|
||||
x: dumbBox.left + scroll.x,
|
||||
y: dumbBox.top + scroll.y
|
||||
};
|
||||
}
|
||||
|
||||
var nipple = new Nipple(self, {
|
||||
color: opts.color,
|
||||
size: opts.size,
|
||||
threshold: opts.threshold,
|
||||
fadeTime: opts.fadeTime,
|
||||
dataOnly: opts.dataOnly,
|
||||
restJoystick: opts.restJoystick,
|
||||
restOpacity: opts.restOpacity,
|
||||
mode: opts.mode,
|
||||
identifier: identifier,
|
||||
position: position,
|
||||
zone: opts.zone,
|
||||
frontPosition: {
|
||||
x: 0,
|
||||
y: 0
|
||||
}
|
||||
});
|
||||
|
||||
if (!opts.dataOnly) {
|
||||
u.applyPosition(nipple.ui.el, toPutOn);
|
||||
u.applyPosition(nipple.ui.front, nipple.frontPosition);
|
||||
}
|
||||
self.nipples.push(nipple);
|
||||
self.trigger('added ' + nipple.identifier + ':added', nipple);
|
||||
self.manager.trigger('added ' + nipple.identifier + ':added', nipple);
|
||||
|
||||
self.bindNipple(nipple);
|
||||
|
||||
return nipple;
|
||||
};
|
||||
|
||||
Collection.prototype.updateBox = function () {
|
||||
var self = this;
|
||||
self.box = self.options.zone.getBoundingClientRect();
|
||||
};
|
||||
|
||||
Collection.prototype.bindNipple = function (nipple) {
|
||||
var self = this;
|
||||
var type;
|
||||
// Bubble up identified events.
|
||||
var handler = function (evt, data) {
|
||||
// Identify the event type with the nipple's id.
|
||||
type = evt.type + ' ' + data.id + ':' + evt.type;
|
||||
self.trigger(type, data);
|
||||
};
|
||||
|
||||
// When it gets destroyed.
|
||||
nipple.on('destroyed', self.onDestroyed.bind(self));
|
||||
|
||||
// Other events that will get bubbled up.
|
||||
nipple.on('shown hidden rested dir plain', handler);
|
||||
nipple.on('dir:up dir:right dir:down dir:left', handler);
|
||||
nipple.on('plain:up plain:right plain:down plain:left', handler);
|
||||
};
|
||||
|
||||
Collection.prototype.pressureFn = function (touch, nipple, identifier) {
|
||||
var self = this;
|
||||
var previousPressure = 0;
|
||||
clearInterval(self.pressureIntervals[identifier]);
|
||||
// Create an interval that will read the pressure every 100ms
|
||||
self.pressureIntervals[identifier] = setInterval(function () {
|
||||
var pressure = touch.force || touch.pressure ||
|
||||
touch.webkitForce || 0;
|
||||
if (pressure !== previousPressure) {
|
||||
nipple.trigger('pressure', pressure);
|
||||
self.trigger('pressure ' +
|
||||
nipple.identifier + ':pressure', pressure);
|
||||
previousPressure = pressure;
|
||||
}
|
||||
}.bind(self), 100);
|
||||
};
|
||||
|
||||
Collection.prototype.onstart = function (evt) {
|
||||
var self = this;
|
||||
var opts = self.options;
|
||||
var origEvt = evt;
|
||||
evt = u.prepareEvent(evt);
|
||||
|
||||
// Update the box position
|
||||
self.updateBox();
|
||||
|
||||
var process = function (touch) {
|
||||
// If we can create new nipples
|
||||
// meaning we don't have more active nipples than we should.
|
||||
if (self.actives.length < opts.maxNumberOfNipples) {
|
||||
self.processOnStart(touch);
|
||||
}
|
||||
else if(origEvt.type.match(/^touch/)){
|
||||
// zombies occur when end event is not received on Safari
|
||||
// first touch removed before second touch, we need to catch up...
|
||||
// so remove where touches in manager that no longer exist
|
||||
Object.keys(self.manager.ids).forEach(function(k){
|
||||
if(Object.values(origEvt.touches).findIndex(function(t){return t.identifier===k;}) < 0){
|
||||
// manager has id that doesn't exist in touches
|
||||
var e = [evt[0]];
|
||||
e.identifier = k;
|
||||
self.processOnEnd(e);
|
||||
}
|
||||
});
|
||||
if(self.actives.length < opts.maxNumberOfNipples){
|
||||
self.processOnStart(touch);
|
||||
}
|
||||
}
|
||||
};
|
||||
|
||||
u.map(evt, process);
|
||||
|
||||
// We ask upstream to bind the document
|
||||
// on 'move' and 'end'
|
||||
self.manager.bindDocument();
|
||||
return false;
|
||||
};
|
||||
|
||||
Collection.prototype.processOnStart = function (evt) {
|
||||
var self = this;
|
||||
var opts = self.options;
|
||||
var indexInIdles;
|
||||
var identifier = self.manager.getIdentifier(evt);
|
||||
var pressure = evt.force || evt.pressure || evt.webkitForce || 0;
|
||||
var position = {
|
||||
x: evt.pageX,
|
||||
y: evt.pageY
|
||||
};
|
||||
|
||||
var nipple = self.getOrCreate(identifier, position);
|
||||
|
||||
// Update its touch identifier
|
||||
if (nipple.identifier !== identifier) {
|
||||
self.manager.removeIdentifier(nipple.identifier);
|
||||
}
|
||||
nipple.identifier = identifier;
|
||||
|
||||
var process = function (nip) {
|
||||
// Trigger the start.
|
||||
nip.trigger('start', nip);
|
||||
self.trigger('start ' + nip.id + ':start', nip);
|
||||
|
||||
nip.show();
|
||||
if (pressure > 0) {
|
||||
self.pressureFn(evt, nip, nip.identifier);
|
||||
}
|
||||
// Trigger the first move event.
|
||||
self.processOnMove(evt);
|
||||
};
|
||||
|
||||
// Transfer it from idles to actives.
|
||||
if ((indexInIdles = self.idles.indexOf(nipple)) >= 0) {
|
||||
self.idles.splice(indexInIdles, 1);
|
||||
}
|
||||
|
||||
// Store the nipple in the actives array
|
||||
self.actives.push(nipple);
|
||||
self.ids.push(nipple.identifier);
|
||||
|
||||
if (opts.mode !== 'semi') {
|
||||
process(nipple);
|
||||
} else {
|
||||
// In semi we check the distance of the touch
|
||||
// to decide if we have to reset the nipple
|
||||
var distance = u.distance(position, nipple.position);
|
||||
if (distance <= opts.catchDistance) {
|
||||
process(nipple);
|
||||
} else {
|
||||
nipple.destroy();
|
||||
self.processOnStart(evt);
|
||||
return;
|
||||
}
|
||||
}
|
||||
|
||||
return nipple;
|
||||
};
|
||||
|
||||
Collection.prototype.getOrCreate = function (identifier, position) {
|
||||
var self = this;
|
||||
var opts = self.options;
|
||||
var nipple;
|
||||
|
||||
// If we're in static or semi, we might already have an active.
|
||||
if (/(semi|static)/.test(opts.mode)) {
|
||||
// Get the active one.
|
||||
// TODO: Multi-touche for semi and static will start here.
|
||||
// Return the nearest one.
|
||||
nipple = self.idles[0];
|
||||
if (nipple) {
|
||||
self.idles.splice(0, 1);
|
||||
return nipple;
|
||||
}
|
||||
|
||||
if (opts.mode === 'semi') {
|
||||
// If we're in semi mode, we need to create one.
|
||||
return self.createNipple(position, identifier);
|
||||
}
|
||||
|
||||
// eslint-disable-next-line no-console
|
||||
console.warn('Coudln\'t find the needed nipple.');
|
||||
return false;
|
||||
}
|
||||
// In dynamic, we create a new one.
|
||||
nipple = self.createNipple(position, identifier);
|
||||
return nipple;
|
||||
};
|
||||
|
||||
Collection.prototype.processOnMove = function (evt) {
|
||||
var self = this;
|
||||
var opts = self.options;
|
||||
var identifier = self.manager.getIdentifier(evt);
|
||||
var nipple = self.nipples.get(identifier);
|
||||
|
||||
// If we're moving without pressing
|
||||
// it's that we went out the active zone
|
||||
if (!u.isPressed(evt)) {
|
||||
this.processOnEnd(evt);
|
||||
return;
|
||||
}
|
||||
|
||||
if (!nipple) {
|
||||
// This is here just for safety.
|
||||
// It shouldn't happen.
|
||||
// eslint-disable-next-line no-console
|
||||
console.error('Found zombie joystick with ID ' + identifier);
|
||||
self.manager.removeIdentifier(identifier);
|
||||
return;
|
||||
}
|
||||
|
||||
if (opts.dynamicPage) {
|
||||
var scroll = u.getScroll();
|
||||
pos = nipple.el.getBoundingClientRect();
|
||||
nipple.position = {
|
||||
x: scroll.x + pos.left,
|
||||
y: scroll.y + pos.top
|
||||
};
|
||||
}
|
||||
|
||||
nipple.identifier = identifier;
|
||||
|
||||
var size = nipple.options.size / 2;
|
||||
var pos = {
|
||||
x: evt.pageX,
|
||||
y: evt.pageY
|
||||
};
|
||||
|
||||
if (opts.lockX){
|
||||
pos.y = nipple.position.y;
|
||||
}
|
||||
if (opts.lockY) {
|
||||
pos.x = nipple.position.x;
|
||||
}
|
||||
|
||||
var dist = u.distance(pos, nipple.position);
|
||||
var angle = u.angle(pos, nipple.position);
|
||||
var rAngle = u.radians(angle);
|
||||
var force = dist / size;
|
||||
|
||||
var raw = {
|
||||
distance: dist,
|
||||
position: pos
|
||||
};
|
||||
|
||||
// If distance is bigger than nipple's size
|
||||
// we clamp the position.
|
||||
if (dist > size) {
|
||||
dist = size;
|
||||
pos = u.findCoord(nipple.position, dist, angle);
|
||||
}
|
||||
|
||||
var xPosition = pos.x - nipple.position.x;
|
||||
var yPosition = pos.y - nipple.position.y;
|
||||
|
||||
nipple.frontPosition = {
|
||||
x: xPosition,
|
||||
y: yPosition
|
||||
};
|
||||
|
||||
if (!opts.dataOnly) {
|
||||
u.applyPosition(nipple.ui.front, nipple.frontPosition);
|
||||
}
|
||||
|
||||
// Prepare event's datas.
|
||||
var toSend = {
|
||||
identifier: nipple.identifier,
|
||||
position: pos,
|
||||
force: force,
|
||||
pressure: evt.force || evt.pressure || evt.webkitForce || 0,
|
||||
distance: dist,
|
||||
angle: {
|
||||
radian: rAngle,
|
||||
degree: angle
|
||||
},
|
||||
vector: {
|
||||
x: xPosition / size,
|
||||
y: - yPosition / size
|
||||
},
|
||||
raw: raw,
|
||||
instance: nipple,
|
||||
lockX: opts.lockX,
|
||||
lockY: opts.lockY
|
||||
};
|
||||
|
||||
// Compute the direction's datas.
|
||||
toSend = nipple.computeDirection(toSend);
|
||||
|
||||
// Offset angles to follow units circle.
|
||||
toSend.angle = {
|
||||
radian: u.radians(180 - angle),
|
||||
degree: 180 - angle
|
||||
};
|
||||
|
||||
// Send everything to everyone.
|
||||
nipple.trigger('move', toSend);
|
||||
self.trigger('move ' + nipple.id + ':move', toSend);
|
||||
};
|
||||
|
||||
Collection.prototype.processOnEnd = function (evt) {
|
||||
var self = this;
|
||||
var opts = self.options;
|
||||
var identifier = self.manager.getIdentifier(evt);
|
||||
var nipple = self.nipples.get(identifier);
|
||||
var removedIdentifier = self.manager.removeIdentifier(nipple.identifier);
|
||||
|
||||
if (!nipple) {
|
||||
return;
|
||||
}
|
||||
|
||||
if (!opts.dataOnly) {
|
||||
nipple.hide(function () {
|
||||
if (opts.mode === 'dynamic') {
|
||||
nipple.trigger('removed', nipple);
|
||||
self.trigger('removed ' + nipple.id + ':removed', nipple);
|
||||
self.manager
|
||||
.trigger('removed ' + nipple.id + ':removed', nipple);
|
||||
nipple.destroy();
|
||||
}
|
||||
});
|
||||
}
|
||||
|
||||
// Clear the pressure interval reader
|
||||
clearInterval(self.pressureIntervals[nipple.identifier]);
|
||||
|
||||
// Reset the direciton of the nipple, to be able to trigger a new direction
|
||||
// on start.
|
||||
nipple.resetDirection();
|
||||
|
||||
nipple.trigger('end', nipple);
|
||||
self.trigger('end ' + nipple.id + ':end', nipple);
|
||||
|
||||
// Remove identifier from our bank.
|
||||
if (self.ids.indexOf(nipple.identifier) >= 0) {
|
||||
self.ids.splice(self.ids.indexOf(nipple.identifier), 1);
|
||||
}
|
||||
|
||||
// Clean our actives array.
|
||||
if (self.actives.indexOf(nipple) >= 0) {
|
||||
self.actives.splice(self.actives.indexOf(nipple), 1);
|
||||
}
|
||||
|
||||
if (/(semi|static)/.test(opts.mode)) {
|
||||
// Transfer nipple from actives to idles
|
||||
// if we're in semi or static mode.
|
||||
self.idles.push(nipple);
|
||||
} else if (self.nipples.indexOf(nipple) >= 0) {
|
||||
// Only if we're not in semi or static mode
|
||||
// we can remove the instance.
|
||||
self.nipples.splice(self.nipples.indexOf(nipple), 1);
|
||||
}
|
||||
|
||||
// We unbind move and end.
|
||||
self.manager.unbindDocument();
|
||||
|
||||
// We add back the identifier of the idle nipple;
|
||||
if (/(semi|static)/.test(opts.mode)) {
|
||||
self.manager.ids[removedIdentifier.id] = removedIdentifier.identifier;
|
||||
}
|
||||
};
|
||||
|
||||
// Remove destroyed nipple from the lists
|
||||
Collection.prototype.onDestroyed = function(evt, nipple) {
|
||||
var self = this;
|
||||
if (self.nipples.indexOf(nipple) >= 0) {
|
||||
self.nipples.splice(self.nipples.indexOf(nipple), 1);
|
||||
}
|
||||
if (self.actives.indexOf(nipple) >= 0) {
|
||||
self.actives.splice(self.actives.indexOf(nipple), 1);
|
||||
}
|
||||
if (self.idles.indexOf(nipple) >= 0) {
|
||||
self.idles.splice(self.idles.indexOf(nipple), 1);
|
||||
}
|
||||
if (self.ids.indexOf(nipple.identifier) >= 0) {
|
||||
self.ids.splice(self.ids.indexOf(nipple.identifier), 1);
|
||||
}
|
||||
|
||||
// Remove the identifier from our bank
|
||||
self.manager.removeIdentifier(nipple.identifier);
|
||||
|
||||
// We unbind move and end.
|
||||
self.manager.unbindDocument();
|
||||
};
|
||||
|
||||
// Cleanly destroy the manager
|
||||
Collection.prototype.destroy = function () {
|
||||
var self = this;
|
||||
self.unbindEvt(self.options.zone, 'start');
|
||||
|
||||
// Destroy nipples.
|
||||
self.nipples.forEach(function(nipple) {
|
||||
nipple.destroy();
|
||||
});
|
||||
|
||||
// Clean 3DTouch intervals.
|
||||
for (var i in self.pressureIntervals) {
|
||||
if (self.pressureIntervals.hasOwnProperty(i)) {
|
||||
clearInterval(self.pressureIntervals[i]);
|
||||
}
|
||||
}
|
||||
|
||||
// Notify the manager passing the instance
|
||||
self.trigger('destroyed', self.nipples);
|
||||
// We unbind move and end.
|
||||
self.manager.unbindDocument();
|
||||
// Unbind everything.
|
||||
self.off();
|
||||
};
|
||||
|
||||
export default Collection;
|
||||
+9
@@ -0,0 +1,9 @@
|
||||
import Manager from './manager';
|
||||
|
||||
const factory = new Manager();
|
||||
export default {
|
||||
create: function (options) {
|
||||
return factory.create(options);
|
||||
},
|
||||
factory: factory
|
||||
};
|
||||
+225
@@ -0,0 +1,225 @@
|
||||
import Collection from './collection';
|
||||
import Super from './super';
|
||||
import * as u from './utils';
|
||||
|
||||
///////////////////////
|
||||
/// MANAGER ///
|
||||
///////////////////////
|
||||
|
||||
function Manager (options) {
|
||||
var self = this;
|
||||
self.ids = {};
|
||||
self.index = 0;
|
||||
self.collections = [];
|
||||
|
||||
self.config(options);
|
||||
self.prepareCollections();
|
||||
|
||||
// Listen for resize, to reposition every joysticks
|
||||
var resizeTimer;
|
||||
u.bindEvt(window, 'resize', function (evt) {
|
||||
clearTimeout(resizeTimer);
|
||||
resizeTimer = setTimeout(function () {
|
||||
var pos;
|
||||
var scroll = u.getScroll();
|
||||
self.collections.forEach(function (collection) {
|
||||
collection.forEach(function (nipple) {
|
||||
pos = nipple.el.getBoundingClientRect();
|
||||
nipple.position = {
|
||||
x: scroll.x + pos.left,
|
||||
y: scroll.y + pos.top
|
||||
};
|
||||
});
|
||||
});
|
||||
}, 100);
|
||||
});
|
||||
|
||||
return self.collections;
|
||||
}
|
||||
|
||||
Manager.prototype = new Super();
|
||||
Manager.constructor = Manager;
|
||||
|
||||
Manager.prototype.prepareCollections = function () {
|
||||
var self = this;
|
||||
// Public API Preparation.
|
||||
self.collections.create = self.create.bind(self);
|
||||
// Listen to anything
|
||||
self.collections.on = self.on.bind(self);
|
||||
// Unbind general events
|
||||
self.collections.off = self.off.bind(self);
|
||||
// Destroy everything
|
||||
self.collections.destroy = self.destroy.bind(self);
|
||||
// Get any nipple
|
||||
self.collections.get = function (id) {
|
||||
var nipple;
|
||||
// Use .every() to break the loop as soon as found.
|
||||
self.collections.every(function (collection) {
|
||||
nipple = collection.get(id);
|
||||
return nipple ? false : true;
|
||||
});
|
||||
return nipple;
|
||||
};
|
||||
};
|
||||
|
||||
Manager.prototype.create = function (options) {
|
||||
return this.createCollection(options);
|
||||
};
|
||||
|
||||
// Collection Factory
|
||||
Manager.prototype.createCollection = function (options) {
|
||||
var self = this;
|
||||
var collection = new Collection(self, options);
|
||||
|
||||
self.bindCollection(collection);
|
||||
self.collections.push(collection);
|
||||
|
||||
return collection;
|
||||
};
|
||||
|
||||
Manager.prototype.bindCollection = function (collection) {
|
||||
var self = this;
|
||||
var type;
|
||||
// Bubble up identified events.
|
||||
var handler = function (evt, data) {
|
||||
// Identify the event type with the nipple's identifier.
|
||||
type = evt.type + ' ' + data.id + ':' + evt.type;
|
||||
self.trigger(type, data);
|
||||
};
|
||||
|
||||
// When it gets destroyed we clean.
|
||||
collection.on('destroyed', self.onDestroyed.bind(self));
|
||||
|
||||
// Other events that will get bubbled up.
|
||||
collection.on('shown hidden rested dir plain', handler);
|
||||
collection.on('dir:up dir:right dir:down dir:left', handler);
|
||||
collection.on('plain:up plain:right plain:down plain:left', handler);
|
||||
};
|
||||
|
||||
Manager.prototype.bindDocument = function () {
|
||||
var self = this;
|
||||
// Bind only if not already binded
|
||||
if (!self.binded) {
|
||||
self.bindEvt(document, 'move')
|
||||
.bindEvt(document, 'end');
|
||||
self.binded = true;
|
||||
}
|
||||
};
|
||||
|
||||
Manager.prototype.unbindDocument = function (force) {
|
||||
var self = this;
|
||||
// If there are no touch left
|
||||
// unbind the document.
|
||||
if (!Object.keys(self.ids).length || force === true) {
|
||||
self.unbindEvt(document, 'move')
|
||||
.unbindEvt(document, 'end');
|
||||
self.binded = false;
|
||||
}
|
||||
};
|
||||
|
||||
Manager.prototype.getIdentifier = function (evt) {
|
||||
var id;
|
||||
// If no event, simple increment
|
||||
if (!evt) {
|
||||
id = this.index;
|
||||
} else {
|
||||
// Extract identifier from event object.
|
||||
// Unavailable in mouse events so replaced by latest increment.
|
||||
id = evt.identifier === undefined ? evt.pointerId : evt.identifier;
|
||||
if (id === undefined) {
|
||||
id = this.latest || 0;
|
||||
}
|
||||
}
|
||||
|
||||
if (this.ids[id] === undefined) {
|
||||
this.ids[id] = this.index;
|
||||
this.index += 1;
|
||||
}
|
||||
|
||||
// Keep the latest id used in case we're using an unidentified mouseEvent
|
||||
this.latest = id;
|
||||
return this.ids[id];
|
||||
};
|
||||
|
||||
Manager.prototype.removeIdentifier = function (identifier) {
|
||||
var removed = {};
|
||||
for (var id in this.ids) {
|
||||
if (this.ids[id] === identifier) {
|
||||
removed.id = id;
|
||||
removed.identifier = this.ids[id];
|
||||
delete this.ids[id];
|
||||
break;
|
||||
}
|
||||
}
|
||||
return removed;
|
||||
};
|
||||
|
||||
Manager.prototype.onmove = function (evt) {
|
||||
var self = this;
|
||||
self.onAny('move', evt);
|
||||
return false;
|
||||
};
|
||||
|
||||
Manager.prototype.onend = function (evt) {
|
||||
var self = this;
|
||||
self.onAny('end', evt);
|
||||
return false;
|
||||
};
|
||||
|
||||
Manager.prototype.oncancel = function (evt) {
|
||||
var self = this;
|
||||
self.onAny('end', evt);
|
||||
return false;
|
||||
};
|
||||
|
||||
Manager.prototype.onAny = function (which, evt) {
|
||||
var self = this;
|
||||
var id;
|
||||
var processFn = 'processOn' + which.charAt(0).toUpperCase() +
|
||||
which.slice(1);
|
||||
evt = u.prepareEvent(evt);
|
||||
var processColl = function (e, id, coll) {
|
||||
if (coll.ids.indexOf(id) >= 0) {
|
||||
coll[processFn](e);
|
||||
// Mark the event to avoid cleaning it later.
|
||||
e._found_ = true;
|
||||
}
|
||||
};
|
||||
var processEvt = function (e) {
|
||||
id = self.getIdentifier(e);
|
||||
u.map(self.collections, processColl.bind(null, e, id));
|
||||
// If the event isn't handled by any collection,
|
||||
// we need to clean its identifier.
|
||||
if (!e._found_) {
|
||||
self.removeIdentifier(id);
|
||||
}
|
||||
};
|
||||
|
||||
u.map(evt, processEvt);
|
||||
|
||||
return false;
|
||||
};
|
||||
|
||||
// Cleanly destroy the manager
|
||||
Manager.prototype.destroy = function () {
|
||||
var self = this;
|
||||
self.unbindDocument(true);
|
||||
self.ids = {};
|
||||
self.index = 0;
|
||||
self.collections.forEach(function(collection) {
|
||||
collection.destroy();
|
||||
});
|
||||
self.off();
|
||||
};
|
||||
|
||||
// When a collection gets destroyed
|
||||
// we clean behind.
|
||||
Manager.prototype.onDestroyed = function (evt, coll) {
|
||||
var self = this;
|
||||
if (self.collections.indexOf(coll) < 0) {
|
||||
return false;
|
||||
}
|
||||
self.collections.splice(self.collections.indexOf(coll), 1);
|
||||
};
|
||||
|
||||
export default Manager;
|
||||
+405
@@ -0,0 +1,405 @@
|
||||
import Super from './super';
|
||||
import * as u from './utils';
|
||||
|
||||
///////////////////////
|
||||
/// THE NIPPLE ///
|
||||
///////////////////////
|
||||
|
||||
function Nipple (collection, options) {
|
||||
this.identifier = options.identifier;
|
||||
this.position = options.position;
|
||||
this.frontPosition = options.frontPosition;
|
||||
this.collection = collection;
|
||||
|
||||
// Defaults
|
||||
this.defaults = {
|
||||
size: 100,
|
||||
threshold: 0.1,
|
||||
color: 'white',
|
||||
fadeTime: 250,
|
||||
dataOnly: false,
|
||||
restJoystick: true,
|
||||
restOpacity: 0.5,
|
||||
mode: 'dynamic',
|
||||
zone: document.body,
|
||||
lockX: false,
|
||||
lockY: false
|
||||
};
|
||||
|
||||
this.config(options);
|
||||
|
||||
// Overwrites
|
||||
if (this.options.mode === 'dynamic') {
|
||||
this.options.restOpacity = 0;
|
||||
}
|
||||
|
||||
this.id = Nipple.id;
|
||||
Nipple.id += 1;
|
||||
this.buildEl()
|
||||
.stylize();
|
||||
|
||||
// Nipple's API.
|
||||
this.instance = {
|
||||
el: this.ui.el,
|
||||
on: this.on.bind(this),
|
||||
off: this.off.bind(this),
|
||||
show: this.show.bind(this),
|
||||
hide: this.hide.bind(this),
|
||||
add: this.addToDom.bind(this),
|
||||
remove: this.removeFromDom.bind(this),
|
||||
destroy: this.destroy.bind(this),
|
||||
setPosition:this.setPosition.bind(this),
|
||||
resetDirection: this.resetDirection.bind(this),
|
||||
computeDirection: this.computeDirection.bind(this),
|
||||
trigger: this.trigger.bind(this),
|
||||
position: this.position,
|
||||
frontPosition: this.frontPosition,
|
||||
ui: this.ui,
|
||||
identifier: this.identifier,
|
||||
id: this.id,
|
||||
options: this.options
|
||||
};
|
||||
|
||||
return this.instance;
|
||||
}
|
||||
|
||||
Nipple.prototype = new Super();
|
||||
Nipple.constructor = Nipple;
|
||||
Nipple.id = 0;
|
||||
|
||||
// Build the dom element of the Nipple instance.
|
||||
Nipple.prototype.buildEl = function (options) {
|
||||
this.ui = {};
|
||||
|
||||
if (this.options.dataOnly) {
|
||||
return this;
|
||||
}
|
||||
|
||||
this.ui.el = document.createElement('div');
|
||||
this.ui.back = document.createElement('div');
|
||||
this.ui.front = document.createElement('div');
|
||||
|
||||
this.ui.el.className = 'nipple collection_' + this.collection.id;
|
||||
this.ui.back.className = 'back';
|
||||
this.ui.front.className = 'front';
|
||||
|
||||
this.ui.el.setAttribute('id', 'nipple_' + this.collection.id +
|
||||
'_' + this.id);
|
||||
|
||||
this.ui.el.appendChild(this.ui.back);
|
||||
this.ui.el.appendChild(this.ui.front);
|
||||
|
||||
return this;
|
||||
};
|
||||
|
||||
// Apply CSS to the Nipple instance.
|
||||
Nipple.prototype.stylize = function () {
|
||||
if (this.options.dataOnly) {
|
||||
return this;
|
||||
}
|
||||
var animTime = this.options.fadeTime + 'ms';
|
||||
var borderStyle = u.getVendorStyle('borderRadius', '50%');
|
||||
var transitStyle = u.getTransitionStyle('transition', 'opacity', animTime);
|
||||
var styles = {};
|
||||
styles.el = {
|
||||
position: 'absolute',
|
||||
opacity: this.options.restOpacity,
|
||||
display: 'block',
|
||||
'zIndex': 999
|
||||
};
|
||||
|
||||
styles.back = {
|
||||
position: 'absolute',
|
||||
display: 'block',
|
||||
width: this.options.size + 'px',
|
||||
height: this.options.size + 'px',
|
||||
marginLeft: -this.options.size / 2 + 'px',
|
||||
marginTop: -this.options.size / 2 + 'px',
|
||||
background: this.options.color,
|
||||
'opacity': '.5'
|
||||
};
|
||||
|
||||
styles.front = {
|
||||
width: this.options.size / 2 + 'px',
|
||||
height: this.options.size / 2 + 'px',
|
||||
position: 'absolute',
|
||||
display: 'block',
|
||||
marginLeft: -this.options.size / 4 + 'px',
|
||||
marginTop: -this.options.size / 4 + 'px',
|
||||
background: this.options.color,
|
||||
'opacity': '.5'
|
||||
};
|
||||
|
||||
u.extend(styles.el, transitStyle);
|
||||
u.extend(styles.back, borderStyle);
|
||||
u.extend(styles.front, borderStyle);
|
||||
|
||||
this.applyStyles(styles);
|
||||
|
||||
return this;
|
||||
};
|
||||
|
||||
Nipple.prototype.applyStyles = function (styles) {
|
||||
// Apply styles
|
||||
for (var i in this.ui) {
|
||||
if (this.ui.hasOwnProperty(i)) {
|
||||
for (var j in styles[i]) {
|
||||
this.ui[i].style[j] = styles[i][j];
|
||||
}
|
||||
}
|
||||
}
|
||||
|
||||
return this;
|
||||
};
|
||||
|
||||
// Inject the Nipple instance into DOM.
|
||||
Nipple.prototype.addToDom = function () {
|
||||
// We're not adding it if we're dataOnly or already in dom.
|
||||
if (this.options.dataOnly || document.body.contains(this.ui.el)) {
|
||||
return this;
|
||||
}
|
||||
this.options.zone.appendChild(this.ui.el);
|
||||
return this;
|
||||
};
|
||||
|
||||
// Remove the Nipple instance from DOM.
|
||||
Nipple.prototype.removeFromDom = function () {
|
||||
if (this.options.dataOnly || !document.body.contains(this.ui.el)) {
|
||||
return this;
|
||||
}
|
||||
this.options.zone.removeChild(this.ui.el);
|
||||
return this;
|
||||
};
|
||||
|
||||
// Entirely destroy this nipple
|
||||
Nipple.prototype.destroy = function () {
|
||||
clearTimeout(this.removeTimeout);
|
||||
clearTimeout(this.showTimeout);
|
||||
clearTimeout(this.restTimeout);
|
||||
this.trigger('destroyed', this.instance);
|
||||
this.removeFromDom();
|
||||
this.off();
|
||||
};
|
||||
|
||||
// Fade in the Nipple instance.
|
||||
Nipple.prototype.show = function (cb) {
|
||||
var self = this;
|
||||
|
||||
if (self.options.dataOnly) {
|
||||
return self;
|
||||
}
|
||||
|
||||
clearTimeout(self.removeTimeout);
|
||||
clearTimeout(self.showTimeout);
|
||||
clearTimeout(self.restTimeout);
|
||||
|
||||
self.addToDom();
|
||||
|
||||
self.restCallback();
|
||||
|
||||
setTimeout(function () {
|
||||
self.ui.el.style.opacity = 1;
|
||||
}, 0);
|
||||
|
||||
self.showTimeout = setTimeout(function () {
|
||||
self.trigger('shown', self.instance);
|
||||
if (typeof cb === 'function') {
|
||||
cb.call(this);
|
||||
}
|
||||
}, self.options.fadeTime);
|
||||
|
||||
return self;
|
||||
};
|
||||
|
||||
// Fade out the Nipple instance.
|
||||
Nipple.prototype.hide = function (cb) {
|
||||
var self = this;
|
||||
|
||||
if (self.options.dataOnly) {
|
||||
return self;
|
||||
}
|
||||
|
||||
self.ui.el.style.opacity = self.options.restOpacity;
|
||||
|
||||
clearTimeout(self.removeTimeout);
|
||||
clearTimeout(self.showTimeout);
|
||||
clearTimeout(self.restTimeout);
|
||||
|
||||
self.removeTimeout = setTimeout(
|
||||
function () {
|
||||
var display = self.options.mode === 'dynamic' ? 'none' : 'block';
|
||||
self.ui.el.style.display = display;
|
||||
if (typeof cb === 'function') {
|
||||
cb.call(self);
|
||||
}
|
||||
|
||||
self.trigger('hidden', self.instance);
|
||||
},
|
||||
self.options.fadeTime
|
||||
);
|
||||
if (self.options.restJoystick) {
|
||||
self.setPosition(cb, { x: 0, y: 0 });
|
||||
}
|
||||
|
||||
return self;
|
||||
};
|
||||
|
||||
// Set the nipple to the specified position
|
||||
Nipple.prototype.setPosition = function (cb, position) {
|
||||
var self = this;
|
||||
self.frontPosition = {
|
||||
x: position.x,
|
||||
y: position.y
|
||||
};
|
||||
var animTime = self.options.fadeTime + 'ms';
|
||||
|
||||
var transitStyle = {};
|
||||
transitStyle.front = u.getTransitionStyle('transition',
|
||||
['top', 'left'], animTime);
|
||||
|
||||
var styles = {front: {}};
|
||||
styles.front = {
|
||||
left: self.frontPosition.x + 'px',
|
||||
top: self.frontPosition.y + 'px'
|
||||
};
|
||||
|
||||
self.applyStyles(transitStyle);
|
||||
self.applyStyles(styles);
|
||||
|
||||
self.restTimeout = setTimeout(
|
||||
function () {
|
||||
if (typeof cb === 'function') {
|
||||
cb.call(self);
|
||||
}
|
||||
self.restCallback();
|
||||
},
|
||||
self.options.fadeTime
|
||||
);
|
||||
};
|
||||
|
||||
Nipple.prototype.restCallback = function () {
|
||||
var self = this;
|
||||
var transitStyle = {};
|
||||
transitStyle.front = u.getTransitionStyle('transition', 'none', '');
|
||||
self.applyStyles(transitStyle);
|
||||
self.trigger('rested', self.instance);
|
||||
};
|
||||
|
||||
Nipple.prototype.resetDirection = function () {
|
||||
// Fully rebuild the object to let the iteration possible.
|
||||
this.direction = {
|
||||
x: false,
|
||||
y: false,
|
||||
angle: false
|
||||
};
|
||||
};
|
||||
|
||||
Nipple.prototype.computeDirection = function (obj) {
|
||||
var rAngle = obj.angle.radian;
|
||||
var angle45 = Math.PI / 4;
|
||||
var angle90 = Math.PI / 2;
|
||||
var direction, directionX, directionY;
|
||||
|
||||
// Angular direction
|
||||
// \ UP /
|
||||
// \ /
|
||||
// LEFT RIGHT
|
||||
// / \
|
||||
// /DOWN \
|
||||
//
|
||||
if (
|
||||
rAngle > angle45 &&
|
||||
rAngle < (angle45 * 3) &&
|
||||
!obj.lockX
|
||||
) {
|
||||
direction = 'up';
|
||||
} else if (
|
||||
rAngle > -angle45 &&
|
||||
rAngle <= angle45 &&
|
||||
!obj.lockY
|
||||
) {
|
||||
direction = 'left';
|
||||
} else if (
|
||||
rAngle > (-angle45 * 3) &&
|
||||
rAngle <= -angle45 &&
|
||||
!obj.lockX
|
||||
) {
|
||||
direction = 'down';
|
||||
} else if (!obj.lockY) {
|
||||
direction = 'right';
|
||||
}
|
||||
|
||||
// Plain direction
|
||||
// UP |
|
||||
// _______ | RIGHT
|
||||
// LEFT |
|
||||
// DOWN |
|
||||
if (!obj.lockY) {
|
||||
if (rAngle > -angle90 && rAngle < angle90) {
|
||||
directionX = 'left';
|
||||
} else {
|
||||
directionX = 'right';
|
||||
}
|
||||
}
|
||||
|
||||
if (!obj.lockX) {
|
||||
if (rAngle > 0) {
|
||||
directionY = 'up';
|
||||
} else {
|
||||
directionY = 'down';
|
||||
}
|
||||
}
|
||||
|
||||
if (obj.force > this.options.threshold) {
|
||||
var oldDirection = {};
|
||||
var i;
|
||||
for (i in this.direction) {
|
||||
if (this.direction.hasOwnProperty(i)) {
|
||||
oldDirection[i] = this.direction[i];
|
||||
}
|
||||
}
|
||||
|
||||
var same = {};
|
||||
|
||||
this.direction = {
|
||||
x: directionX,
|
||||
y: directionY,
|
||||
angle: direction
|
||||
};
|
||||
|
||||
obj.direction = this.direction;
|
||||
|
||||
for (i in oldDirection) {
|
||||
if (oldDirection[i] === this.direction[i]) {
|
||||
same[i] = true;
|
||||
}
|
||||
}
|
||||
|
||||
// If all 3 directions are the same, we don't trigger anything.
|
||||
if (same.x && same.y && same.angle) {
|
||||
return obj;
|
||||
}
|
||||
|
||||
if (!same.x || !same.y) {
|
||||
this.trigger('plain', obj);
|
||||
}
|
||||
|
||||
if (!same.x) {
|
||||
this.trigger('plain:' + directionX, obj);
|
||||
}
|
||||
|
||||
if (!same.y) {
|
||||
this.trigger('plain:' + directionY, obj);
|
||||
}
|
||||
|
||||
if (!same.angle) {
|
||||
this.trigger('dir dir:' + direction, obj);
|
||||
}
|
||||
} else {
|
||||
this.resetDirection();
|
||||
}
|
||||
|
||||
return obj;
|
||||
};
|
||||
|
||||
export default Nipple;
|
||||
+147
@@ -0,0 +1,147 @@
|
||||
///////////////////////
|
||||
/// SUPER CLASS ///
|
||||
///////////////////////
|
||||
import * as u from './utils';
|
||||
|
||||
// Constants
|
||||
var isTouch = !!('ontouchstart' in window);
|
||||
var isPointer = window.PointerEvent ? true : false;
|
||||
var isMSPointer = window.MSPointerEvent ? true : false;
|
||||
var events = {
|
||||
touch: {
|
||||
start: 'touchstart',
|
||||
move: 'touchmove',
|
||||
end: 'touchend, touchcancel'
|
||||
},
|
||||
mouse: {
|
||||
start: 'mousedown',
|
||||
move: 'mousemove',
|
||||
end: 'mouseup'
|
||||
},
|
||||
pointer: {
|
||||
start: 'pointerdown',
|
||||
move: 'pointermove',
|
||||
end: 'pointerup, pointercancel'
|
||||
},
|
||||
MSPointer: {
|
||||
start: 'MSPointerDown',
|
||||
move: 'MSPointerMove',
|
||||
end: 'MSPointerUp'
|
||||
}
|
||||
};
|
||||
var toBind;
|
||||
var secondBind = {};
|
||||
if (isPointer) {
|
||||
toBind = events.pointer;
|
||||
} else if (isMSPointer) {
|
||||
toBind = events.MSPointer;
|
||||
} else if (isTouch) {
|
||||
toBind = events.touch;
|
||||
secondBind = events.mouse;
|
||||
} else {
|
||||
toBind = events.mouse;
|
||||
}
|
||||
|
||||
function Super () {}
|
||||
|
||||
// Basic event system.
|
||||
Super.prototype.on = function (arg, cb) {
|
||||
var self = this;
|
||||
var types = arg.split(/[ ,]+/g);
|
||||
var type;
|
||||
self._handlers_ = self._handlers_ || {};
|
||||
|
||||
for (var i = 0; i < types.length; i += 1) {
|
||||
type = types[i];
|
||||
self._handlers_[type] = self._handlers_[type] || [];
|
||||
self._handlers_[type].push(cb);
|
||||
}
|
||||
return self;
|
||||
};
|
||||
|
||||
Super.prototype.off = function (type, cb) {
|
||||
var self = this;
|
||||
self._handlers_ = self._handlers_ || {};
|
||||
|
||||
if (type === undefined) {
|
||||
self._handlers_ = {};
|
||||
} else if (cb === undefined) {
|
||||
self._handlers_[type] = null;
|
||||
} else if (self._handlers_[type] &&
|
||||
self._handlers_[type].indexOf(cb) >= 0) {
|
||||
self._handlers_[type].splice(self._handlers_[type].indexOf(cb), 1);
|
||||
}
|
||||
|
||||
return self;
|
||||
};
|
||||
|
||||
Super.prototype.trigger = function (arg, data) {
|
||||
var self = this;
|
||||
var types = arg.split(/[ ,]+/g);
|
||||
var type;
|
||||
self._handlers_ = self._handlers_ || {};
|
||||
|
||||
for (var i = 0; i < types.length; i += 1) {
|
||||
type = types[i];
|
||||
if (self._handlers_[type] && self._handlers_[type].length) {
|
||||
self._handlers_[type].forEach(function (handler) {
|
||||
handler.call(self, {
|
||||
type: type,
|
||||
target: self
|
||||
}, data);
|
||||
});
|
||||
}
|
||||
}
|
||||
};
|
||||
|
||||
// Configuration
|
||||
Super.prototype.config = function (options) {
|
||||
var self = this;
|
||||
self.options = self.defaults || {};
|
||||
if (options) {
|
||||
self.options = u.safeExtend(self.options, options);
|
||||
}
|
||||
};
|
||||
|
||||
// Bind internal events.
|
||||
Super.prototype.bindEvt = function (el, type) {
|
||||
var self = this;
|
||||
self._domHandlers_ = self._domHandlers_ || {};
|
||||
|
||||
self._domHandlers_[type] = function () {
|
||||
if (typeof self['on' + type] === 'function') {
|
||||
self['on' + type].apply(self, arguments);
|
||||
} else {
|
||||
// eslint-disable-next-line no-console
|
||||
console.warn('[WARNING] : Missing "on' + type + '" handler.');
|
||||
}
|
||||
};
|
||||
|
||||
u.bindEvt(el, toBind[type], self._domHandlers_[type]);
|
||||
|
||||
if (secondBind[type]) {
|
||||
// Support for both touch and mouse at the same time.
|
||||
u.bindEvt(el, secondBind[type], self._domHandlers_[type]);
|
||||
}
|
||||
|
||||
return self;
|
||||
};
|
||||
|
||||
// Unbind dom events.
|
||||
Super.prototype.unbindEvt = function (el, type) {
|
||||
var self = this;
|
||||
self._domHandlers_ = self._domHandlers_ || {};
|
||||
|
||||
u.unbindEvt(el, toBind[type], self._domHandlers_[type]);
|
||||
|
||||
if (secondBind[type]) {
|
||||
// Support for both touch and mouse at the same time.
|
||||
u.unbindEvt(el, secondBind[type], self._domHandlers_[type]);
|
||||
}
|
||||
|
||||
delete self._domHandlers_[type];
|
||||
|
||||
return this;
|
||||
};
|
||||
|
||||
export default Super;
|
||||
+175
@@ -0,0 +1,175 @@
|
||||
///////////////////////
|
||||
/// UTILS ///
|
||||
///////////////////////
|
||||
|
||||
export const distance = (p1, p2) => {
|
||||
const dx = p2.x - p1.x;
|
||||
const dy = p2.y - p1.y;
|
||||
|
||||
return Math.sqrt((dx * dx) + (dy * dy));
|
||||
};
|
||||
|
||||
export const angle = (p1, p2) => {
|
||||
const dx = p2.x - p1.x;
|
||||
const dy = p2.y - p1.y;
|
||||
|
||||
return degrees(Math.atan2(dy, dx));
|
||||
};
|
||||
|
||||
export const findCoord = (p, d, a) => {
|
||||
const b = {x: 0, y: 0};
|
||||
a = radians(a);
|
||||
b.x = p.x - d * Math.cos(a);
|
||||
b.y = p.y - d * Math.sin(a);
|
||||
return b;
|
||||
};
|
||||
|
||||
export const radians = (a) => {
|
||||
return a * (Math.PI / 180);
|
||||
};
|
||||
|
||||
export const degrees = (a) => {
|
||||
return a * (180 / Math.PI);
|
||||
};
|
||||
|
||||
export const isPressed = (evt) => {
|
||||
if (isNaN(evt.buttons)) {
|
||||
return evt.pressure !== 0;
|
||||
}
|
||||
return evt.buttons !== 0;
|
||||
};
|
||||
|
||||
export const bindEvt = (el, arg, handler) => {
|
||||
const types = arg.split(/[ ,]+/g);
|
||||
let type;
|
||||
for (let i = 0; i < types.length; i += 1) {
|
||||
type = types[i];
|
||||
if (el.addEventListener) {
|
||||
el.addEventListener(type, handler, false);
|
||||
} else if (el.attachEvent) {
|
||||
el.attachEvent(type, handler);
|
||||
}
|
||||
}
|
||||
};
|
||||
|
||||
export const unbindEvt = (el, arg, handler) => {
|
||||
const types = arg.split(/[ ,]+/g);
|
||||
let type;
|
||||
for (let i = 0; i < types.length; i += 1) {
|
||||
type = types[i];
|
||||
if (el.removeEventListener) {
|
||||
el.removeEventListener(type, handler);
|
||||
} else if (el.detachEvent) {
|
||||
el.detachEvent(type, handler);
|
||||
}
|
||||
}
|
||||
};
|
||||
|
||||
export const trigger = (el, type, data) => {
|
||||
const evt = new CustomEvent(type, data);
|
||||
el.dispatchEvent(evt);
|
||||
};
|
||||
|
||||
export const prepareEvent = (evt) => {
|
||||
evt.preventDefault();
|
||||
return evt.type.match(/^touch/) ? evt.changedTouches : evt;
|
||||
};
|
||||
|
||||
export const getScroll = () => {
|
||||
const x = (window.pageXOffset !== undefined) ?
|
||||
window.pageXOffset :
|
||||
(document.documentElement || document.body.parentNode || document.body)
|
||||
.scrollLeft;
|
||||
|
||||
const y = (window.pageYOffset !== undefined) ?
|
||||
window.pageYOffset :
|
||||
(document.documentElement || document.body.parentNode || document.body)
|
||||
.scrollTop;
|
||||
return {
|
||||
x: x,
|
||||
y: y
|
||||
};
|
||||
};
|
||||
|
||||
export const applyPosition = (el, pos) => {
|
||||
if (pos.top || pos.right || pos.bottom || pos.left) {
|
||||
el.style.top = pos.top;
|
||||
el.style.right = pos.right;
|
||||
el.style.bottom = pos.bottom;
|
||||
el.style.left = pos.left;
|
||||
} else {
|
||||
el.style.left = pos.x + 'px';
|
||||
el.style.top = pos.y + 'px';
|
||||
}
|
||||
};
|
||||
|
||||
export const getTransitionStyle = (property, values, time) => {
|
||||
const obj = configStylePropertyObject(property);
|
||||
for (let i in obj) {
|
||||
if (obj.hasOwnProperty(i)) {
|
||||
if (typeof values === 'string') {
|
||||
obj[i] = values + ' ' + time;
|
||||
} else {
|
||||
let st = '';
|
||||
for (let j = 0, max = values.length; j < max; j += 1) {
|
||||
st += values[j] + ' ' + time + ', ';
|
||||
}
|
||||
obj[i] = st.slice(0, -2);
|
||||
}
|
||||
}
|
||||
}
|
||||
return obj;
|
||||
};
|
||||
|
||||
export const getVendorStyle = (property, value) => {
|
||||
const obj = configStylePropertyObject(property);
|
||||
for (let i in obj) {
|
||||
if (obj.hasOwnProperty(i)) {
|
||||
obj[i] = value;
|
||||
}
|
||||
}
|
||||
return obj;
|
||||
};
|
||||
|
||||
export const configStylePropertyObject = (prop) => {
|
||||
const obj = {};
|
||||
obj[prop] = '';
|
||||
const vendors = ['webkit', 'Moz', 'o'];
|
||||
vendors.forEach(function (vendor) {
|
||||
obj[vendor + prop.charAt(0).toUpperCase() + prop.slice(1)] = '';
|
||||
});
|
||||
return obj;
|
||||
};
|
||||
|
||||
export const extend = (objA, objB) => {
|
||||
for (let i in objB) {
|
||||
if (objB.hasOwnProperty(i)) {
|
||||
objA[i] = objB[i];
|
||||
}
|
||||
}
|
||||
return objA;
|
||||
};
|
||||
|
||||
// Overwrite only what's already present
|
||||
export const safeExtend = (objA, objB) => {
|
||||
const obj = {};
|
||||
for (let i in objA) {
|
||||
if (objA.hasOwnProperty(i) && objB.hasOwnProperty(i)) {
|
||||
obj[i] = objB[i];
|
||||
} else if (objA.hasOwnProperty(i)) {
|
||||
obj[i] = objA[i];
|
||||
}
|
||||
}
|
||||
return obj;
|
||||
};
|
||||
|
||||
// Map for array or unique item.
|
||||
export const map = (ar, fn) => {
|
||||
if (ar.length) {
|
||||
for (let i = 0, max = ar.length; i < max; i += 1) {
|
||||
fn(ar[i]);
|
||||
}
|
||||
} else {
|
||||
fn(ar);
|
||||
}
|
||||
};
|
||||
+348
@@ -0,0 +1,348 @@
|
||||
export interface JoystickManagerOptions {
|
||||
/**
|
||||
* Defaults to `'body'`
|
||||
* The dom element in which all your joysticks will be injected.
|
||||
*
|
||||
* This zone also serve as the mouse/touch events handler.
|
||||
*
|
||||
* It represents the zone where all your joysticks will be active.
|
||||
*/
|
||||
zone?: HTMLElement;
|
||||
|
||||
/**
|
||||
* Defaults to `'white'`
|
||||
* The background color of your joystick’s elements.
|
||||
*
|
||||
* Can be any valid CSS color.
|
||||
*/
|
||||
color?: string;
|
||||
|
||||
/**
|
||||
* Defaults to `100`
|
||||
* The size in pixel of the outer circle.
|
||||
*
|
||||
* The inner circle is 50% of this size.
|
||||
*/
|
||||
size?: number;
|
||||
|
||||
/**
|
||||
* This is the strength needed to trigger a directional event.
|
||||
*
|
||||
* Basically, the center is 0 and the outer is 1.
|
||||
*
|
||||
* You need to at least go to 0.1 to trigger a directional event.
|
||||
*/
|
||||
threshold?: number;
|
||||
|
||||
/**
|
||||
* Defaults to `250`
|
||||
*
|
||||
* The time it takes for joystick to fade-out and fade-in when activated or de-activated.
|
||||
*/
|
||||
fadeTime?: number;
|
||||
|
||||
/**
|
||||
* Defaults to `false`
|
||||
*
|
||||
* Enable the multitouch capabilities.
|
||||
*
|
||||
* If, for reasons, you need to have multiple nipples into the same zone.
|
||||
*
|
||||
* Otherwise it will only get one, and all new touches won’t do a thing.
|
||||
*
|
||||
* Please note that multitouch is off when in static or semi modes.
|
||||
*/
|
||||
multitouch?: boolean;
|
||||
|
||||
/**
|
||||
* Defaults to `1`
|
||||
*
|
||||
* If you need to, you can also control the maximum number of instance that could be created.
|
||||
*
|
||||
* Obviously in a multitouch configuration.
|
||||
*/
|
||||
maxNumberOfNipples?: number;
|
||||
|
||||
/**
|
||||
* Defaults to `false`
|
||||
*
|
||||
* The library won’t draw anything in the DOM and will only trigger events with data.
|
||||
*/
|
||||
dataOnly?: boolean;
|
||||
|
||||
/**
|
||||
* Defaults to `{top: 0, left: 0}`
|
||||
*
|
||||
* An object that will determine the position of a static mode.
|
||||
*
|
||||
* You can pass any of the four top, right, bottom and left.
|
||||
*
|
||||
* They will be applied as any css property.
|
||||
*/
|
||||
position?: {
|
||||
top?: string;
|
||||
right?: string;
|
||||
bottom?: string;
|
||||
left?: string;
|
||||
};
|
||||
|
||||
/**
|
||||
* Behavioral mode for the joystick
|
||||
*
|
||||
* ### 'dynamic':
|
||||
* a new joystick is created at each new touch.
|
||||
* the joystick gets destroyed when released.
|
||||
* can be multitouch.
|
||||
*
|
||||
* ### 'semi':
|
||||
* new joystick is created at each new touch farther than options.catchDistance of any previously created joystick.
|
||||
* the joystick is faded-out when released but not destroyed.
|
||||
* when touch is made inside the options.catchDistance a new direction is triggered immediately.
|
||||
* when touch is made outside the options.catchDistance the previous joystick is destroyed and a new one is created.
|
||||
* cannot be multitouch.
|
||||
*
|
||||
* ### 'static':
|
||||
* a joystick is positioned immediately at options.position.
|
||||
* one joystick per zone.
|
||||
* each new touch triggers a new direction.
|
||||
* cannot be multitouch.
|
||||
*/
|
||||
mode?: 'dynamic' | 'semi' | 'static';
|
||||
|
||||
/**
|
||||
* Defaults to `true`
|
||||
*
|
||||
* Reset the joystick’s position when it enters the rest state.
|
||||
*/
|
||||
restJoystick?: boolean;
|
||||
|
||||
/**
|
||||
* Defaults to `0.5`
|
||||
* The opacity to apply when the joystick is in a rest position.
|
||||
*/
|
||||
restOpacity?: number;
|
||||
|
||||
/**
|
||||
* Defaults to `200`
|
||||
*
|
||||
* This is only useful in the semi mode, and determine at which distance we recycle the previous joystick.
|
||||
*/
|
||||
catchDistance?: number;
|
||||
|
||||
/**
|
||||
* Defaults to `false`
|
||||
*
|
||||
* Locks joystick’s movement to the x (horizontal) axis
|
||||
*/
|
||||
lockX?: boolean;
|
||||
|
||||
/**
|
||||
* Defaults to `false`
|
||||
*
|
||||
* Locks joystick’s movement to the y (vertical) axis
|
||||
*/
|
||||
lockY?: boolean;
|
||||
}
|
||||
|
||||
export interface Position {
|
||||
x: number;
|
||||
y: number;
|
||||
}
|
||||
|
||||
export interface JoystickOutputData {
|
||||
angle: {
|
||||
degree: number;
|
||||
radian: number;
|
||||
};
|
||||
direction: {
|
||||
angle: string;
|
||||
x: string;
|
||||
y: string;
|
||||
};
|
||||
vector: {
|
||||
x: number;
|
||||
y: number;
|
||||
};
|
||||
raw: {
|
||||
distance: number;
|
||||
position: Position;
|
||||
};
|
||||
distance: number;
|
||||
force: number;
|
||||
identifier: number;
|
||||
instance: Joystick;
|
||||
position: Position;
|
||||
pressure: number;
|
||||
}
|
||||
|
||||
export type JoystickEventTypes =
|
||||
/**
|
||||
* A joystick is activated. (the user pressed on the active zone)
|
||||
* Will pass the instance alongside the event.
|
||||
*/
|
||||
| 'start'
|
||||
|
||||
/** A joystick is de-activated. (the user released the active zone)
|
||||
* Will pass the instance alongside the event.
|
||||
*/
|
||||
| 'end'
|
||||
|
||||
/**
|
||||
* A joystick is moved
|
||||
*/
|
||||
| 'move'
|
||||
|
||||
/**
|
||||
* When a direction is reached after the threshold.
|
||||
*
|
||||
* Direction are split with a 45° angle.
|
||||
*/
|
||||
| 'dir'
|
||||
| 'dir:up'
|
||||
| 'dir:down'
|
||||
| 'dir:right'
|
||||
| 'dir:left'
|
||||
|
||||
/**
|
||||
* When a plain direction is reached after the threshold.
|
||||
* Plain directions are split with a 90° angle.
|
||||
*/
|
||||
| 'plain'
|
||||
|
||||
// plain variations
|
||||
| 'plain:up'
|
||||
| 'plain:down'
|
||||
| 'plain:right'
|
||||
| 'plain:left'
|
||||
|
||||
/**
|
||||
* Is triggered at the end of the fade-in animation.
|
||||
* Will pass the instance alongside the event.
|
||||
*
|
||||
* Won’t be trigger in a dataOnly configuration.
|
||||
*/
|
||||
| 'shown'
|
||||
|
||||
/**
|
||||
* Is triggered at the end of the fade-out animation.
|
||||
*
|
||||
* Will pass the instance alongside the event.
|
||||
*
|
||||
* Won’t be trigger in a dataOnly configuration.
|
||||
*/
|
||||
| 'hidden'
|
||||
|
||||
/**
|
||||
* Is triggered at the end of destroy.
|
||||
*
|
||||
* Will pass the instance alongside the event.
|
||||
*/
|
||||
| 'destroyed'
|
||||
|
||||
/**
|
||||
* MBP’s Force Touch, iOS’s 3D Touch, Microsoft’s pressure or MDN’s force
|
||||
*
|
||||
*Is triggered when the pressure on the joystick is changed.
|
||||
*
|
||||
*The value, between 0 and 1, is sent back alongside the event.
|
||||
*/
|
||||
| 'pressure';
|
||||
|
||||
export type ManagerOnlyEventTypes =
|
||||
/**
|
||||
* A joystick just got added.
|
||||
*
|
||||
* Will pass the instance alongside the event.
|
||||
*/
|
||||
| 'added'
|
||||
|
||||
/**
|
||||
* A joystick just got removed.
|
||||
*
|
||||
* Fired at the end of the fade-out animation.
|
||||
*
|
||||
* Will pass the instance alongside the event.
|
||||
*
|
||||
* Won’t be trigger in a dataOnly configuration.
|
||||
*/
|
||||
| 'removed';
|
||||
|
||||
export type JoystickManagerEventTypes = JoystickEventTypes | ManagerOnlyEventTypes;
|
||||
|
||||
export interface EventData {
|
||||
type: JoystickEventTypes | ManagerOnlyEventTypes;
|
||||
target: Collection;
|
||||
}
|
||||
|
||||
export class JoystickManager {
|
||||
create(options?: JoystickManagerOptions): JoystickManager;
|
||||
|
||||
on(
|
||||
type: JoystickManagerEventTypes | JoystickManagerEventTypes[],
|
||||
handler: (evt: EventData, data: JoystickOutputData) => void
|
||||
): void;
|
||||
off(
|
||||
type: JoystickManagerEventTypes | JoystickManagerEventTypes[],
|
||||
handler: (evt: EventData, data: JoystickOutputData) => void
|
||||
): void;
|
||||
get(identifier: number): Joystick;
|
||||
destroy(): void;
|
||||
}
|
||||
|
||||
export interface Collection {
|
||||
nipples: Joystick[];
|
||||
idles: Joystick[];
|
||||
actives: Joystick[];
|
||||
ids: number[];
|
||||
pressureIntervals: {};
|
||||
manager: JoystickManager;
|
||||
id: number;
|
||||
defaults: JoystickManagerOptions;
|
||||
}
|
||||
|
||||
export interface Joystick {
|
||||
on(
|
||||
type: JoystickEventTypes | JoystickEventTypes[],
|
||||
handler: (evt: EventData, data: JoystickOutputData) => void
|
||||
): void;
|
||||
off(
|
||||
type: JoystickEventTypes | JoystickEventTypes[],
|
||||
handler: (evt: EventData, data: JoystickOutputData) => void
|
||||
): void;
|
||||
el: HTMLElement;
|
||||
show(cb?: () => void): void;
|
||||
hide(cb?: () => void): void;
|
||||
add(): void;
|
||||
remove(): void;
|
||||
destroy(): void;
|
||||
identifier: number;
|
||||
trigger(
|
||||
type: JoystickEventTypes | JoystickEventTypes[],
|
||||
handler: (evt: EventData, data: any) => void
|
||||
): void;
|
||||
position: Position;
|
||||
frontPosition: Position;
|
||||
ui: {
|
||||
el: HTMLElement;
|
||||
front: HTMLElement;
|
||||
back: HTMLElement;
|
||||
};
|
||||
options: JoystickManagerOptions;
|
||||
}
|
||||
|
||||
/**
|
||||
* A JavaScript library for creating vanillaJS virtual joysticks, for touch capable interfaces.
|
||||
*/
|
||||
declare module 'nipplejs' {
|
||||
/**
|
||||
* Create a Joystick manager
|
||||
* @param options for creating a manager instance
|
||||
* @return manager instance
|
||||
*/
|
||||
function create(options: JoystickManagerOptions): JoystickManager;
|
||||
|
||||
/**
|
||||
* Library's root manger instance.
|
||||
*/
|
||||
const factory: JoystickManager;
|
||||
}
|
||||
+11
@@ -0,0 +1,11 @@
|
||||
{
|
||||
"requires": true,
|
||||
"lockfileVersion": 1,
|
||||
"dependencies": {
|
||||
"nipplejs": {
|
||||
"version": "0.8.5",
|
||||
"resolved": "https://registry.npmjs.org/nipplejs/-/nipplejs-0.8.5.tgz",
|
||||
"integrity": "sha512-2G7warzUh4jIdmzSIDRCeXJUl/QrZyJ0QwFgI0V1lM34HLNsIqEX6uY0NY4V3wBDHNsub3me1cbFb/FJpWE/5g=="
|
||||
}
|
||||
}
|
||||
}
|
||||
@@ -0,0 +1,91 @@
|
||||
header {
|
||||
background-color: #f1f1f1;
|
||||
padding: 20px;
|
||||
text-align: center;
|
||||
position: relative;
|
||||
}
|
||||
|
||||
body {
|
||||
overflow: scroll;
|
||||
}
|
||||
|
||||
|
||||
.wrapper {
|
||||
display: grid;
|
||||
grid-template-columns: 1fr 1fr 1fr;
|
||||
grid-template-rows: 1fr;
|
||||
width: 100vw;
|
||||
height: 100vh;
|
||||
}
|
||||
.button {
|
||||
border: none;
|
||||
color: white;
|
||||
text-decoration: none;
|
||||
display: inline-block;
|
||||
margin: 10px auto;
|
||||
cursor: pointer;
|
||||
width: 90%;
|
||||
box-shadow: 0 8px 16px 0 rgba(0,0,0,0.2), 0 6px 20px 0 rgba(0,0,0,0.19);
|
||||
font-size: 18px;
|
||||
font-weight: bold;
|
||||
border-radius: 8px;
|
||||
}
|
||||
|
||||
.buttonY{
|
||||
background-color: orange;
|
||||
grid-row: 1;
|
||||
}
|
||||
.buttonX{
|
||||
background-color: blue;
|
||||
grid-row: 2;
|
||||
}
|
||||
.buttonA{
|
||||
background-color: green;
|
||||
grid-row: 3;
|
||||
}
|
||||
|
||||
.buttonStart{
|
||||
background-color: red;
|
||||
grid-row: 4;
|
||||
width: 50%;
|
||||
font-size: 12px;
|
||||
|
||||
}
|
||||
|
||||
.button_container {
|
||||
position: absolute;
|
||||
display: grid;
|
||||
left: 25%;
|
||||
top: 25%;
|
||||
height: 50%;
|
||||
width: 50%;
|
||||
}
|
||||
.image_container {
|
||||
position: absolute;
|
||||
top: 20%;
|
||||
height: 80%;
|
||||
width: 80%;
|
||||
}
|
||||
.joy_container {
|
||||
height: 100%;
|
||||
width: 100%;
|
||||
}
|
||||
|
||||
.left {
|
||||
position: relative;
|
||||
background: rgba(63, 58, 55, 0.1);
|
||||
grid-column: 1;
|
||||
height: 100%;
|
||||
}
|
||||
.middle {
|
||||
position: relative;
|
||||
background: rgba(45, 48, 45, 0.1);
|
||||
grid-column: 2;
|
||||
height: 100%;
|
||||
}
|
||||
|
||||
.right {
|
||||
position: relative;
|
||||
background: rgba(63, 58, 55, 0.1);
|
||||
grid-column: 3;
|
||||
}
|
||||
@@ -0,0 +1,28 @@
|
||||
<launch>
|
||||
<node name="robot" pkg="exomy" type="robot_node.py" respawn="true" output="screen"/>
|
||||
<node name="motors" pkg="exomy" type="motor_node.py" respawn="true" output="screen" />
|
||||
<node name="joystick" pkg="exomy" type="joystick_parser_node.py" respawn="true" output="screen" />
|
||||
|
||||
<node respawn="true" pkg="joy" type="joy_node" name="joy_node">
|
||||
<param name="coalesce_interval" value="0.05"/>
|
||||
</node>
|
||||
|
||||
<node pkg="web_video_server" type="web_video_server" name="web_video_server" respawn="false" output="screen">
|
||||
<param name="default_transport" value="compressed"/>
|
||||
<param name="quality" value="50"/>
|
||||
</node>
|
||||
|
||||
<node pkg="usb_cam" type="usb_cam_node" name="pi_cam" respawn="false" output="screen">
|
||||
<param name="framerate" value="10"/>
|
||||
<param name="video_device" value="/dev/video0"/>
|
||||
<param name="image_width" value="640"/>
|
||||
<param name="image_height" value="480"/>
|
||||
<param name="pixel_format" value="yuyv"/>
|
||||
<param name="camera_frame_id" value="pi_cam"/>
|
||||
<param name="io_method" value="mmap"/>
|
||||
</node>
|
||||
|
||||
<include file="$(find rosbridge_server)/launch/rosbridge_websocket.launch"/>
|
||||
<rosparam file="$(find exomy)/config/exomy.yaml"/>
|
||||
|
||||
</launch>
|
||||
@@ -0,0 +1,2 @@
|
||||
int64[] motor_speeds
|
||||
int64[] motor_angles
|
||||
@@ -0,0 +1,5 @@
|
||||
bool connected
|
||||
bool motors_enabled
|
||||
int64 locomotion_mode
|
||||
int64 vel
|
||||
int64 steering
|
||||
@@ -0,0 +1 @@
|
||||
string state
|
||||
@@ -0,0 +1,29 @@
|
||||
<?xml version="1.0"?>
|
||||
<package format="2">
|
||||
<name>exomy</name>
|
||||
<version>1.0.1</version>
|
||||
<description>The ExoMy ROS package</description>
|
||||
|
||||
<maintainer email="max.ehrhardt@hotmail.de">Maximilian Ehrhardt</maintainer>
|
||||
<license>GPLv3</license>
|
||||
<url type="website">https://github.com/esa-prl/ExoMy</url>
|
||||
<author email="max.ehrhardt@hotmail.de">Maximilian Ehrhardt</author>
|
||||
|
||||
<buildtool_depend>catkin</buildtool_depend>
|
||||
<build_depend>rospy</build_depend>
|
||||
<build_depend>std_msgs</build_depend>
|
||||
<build_depend>sensor_msgs</build_depend>
|
||||
<build_export_depend>rospy</build_export_depend>
|
||||
<build_export_depend>std_msgs</build_export_depend>
|
||||
<build_export_depend>sensor_msgs</build_export_depend>
|
||||
<exec_depend>python-rpi.gpio</exec_depend>
|
||||
<exec_depend>rospy</exec_depend>
|
||||
<exec_depend>std_msgs</exec_depend>
|
||||
<exec_depend>sensor_msgs</exec_depend>
|
||||
|
||||
<build_depend>message_generation</build_depend>
|
||||
<exec_depend>message_runtime</exec_depend>
|
||||
|
||||
<export>
|
||||
</export>
|
||||
</package>
|
||||

Binary file not shown.
|
After Width: | Height: | Size: 527 B |

Binary file not shown.
|
After Width: | Height: | Size: 2.1 KiB |

Binary file not shown.
|
After Width: | Height: | Size: 2.5 KiB |

Binary file not shown.
|
After Width: | Height: | Size: 2.2 KiB |
@@ -0,0 +1,11 @@
|
||||
from picamera import PiCamera
|
||||
from time import sleep
|
||||
'''
|
||||
This script helps to test the functionality of the Raspberry Pi camera.
|
||||
The script must be run dicrectly on the Raspberry Pi (not in the Docker container)
|
||||
'''
|
||||
camera = PiCamera()
|
||||
|
||||
camera.start_preview()
|
||||
sleep(5)
|
||||
camera.stop_preview()
|
||||
@@ -0,0 +1,96 @@
|
||||
import Adafruit_PCA9685
|
||||
import yaml
|
||||
import time
|
||||
import os
|
||||
|
||||
config_filename = '../config/exomy.yaml'
|
||||
|
||||
|
||||
def get_driving_pins():
|
||||
pin_list = []
|
||||
with open(config_filename, 'r') as file:
|
||||
param_dict = yaml.load(file)
|
||||
|
||||
for key, value in param_dict.items():
|
||||
if('pin_drive_' in str(key)):
|
||||
pin_list.append(value)
|
||||
return pin_list
|
||||
|
||||
def get_drive_pwm_neutral():
|
||||
|
||||
with open(config_filename, 'r') as file:
|
||||
param_dict = yaml.load(file)
|
||||
|
||||
for key, value in param_dict.items():
|
||||
if('drive_pwm_neutral' in str(key)):
|
||||
return value
|
||||
|
||||
default_value = 300
|
||||
print('The parameter drive_pwm_neutral could not be found in the exomy.yaml \n')
|
||||
print('It was set to the default value: '+ default_value + '\n')
|
||||
return default_value
|
||||
|
||||
if __name__ == "__main__":
|
||||
print(
|
||||
'''
|
||||
$$$$$$$$\ $$\ $$\
|
||||
$$ _____| $$$\ $$$ |
|
||||
$$ | $$\ $$\ $$$$$$\ $$$$\ $$$$ |$$\ $$\
|
||||
$$$$$\ \$$\ $$ |$$ __$$\ $$\$$\$$ $$ |$$ | $$ |
|
||||
$$ __| \$$$$ / $$ / $$ |$$ \$$$ $$ |$$ | $$ |
|
||||
$$ | $$ $$< $$ | $$ |$$ |\$ /$$ |$$ | $$ |
|
||||
$$$$$$$$\ $$ /\$$\ \$$$$$$ |$$ | \_/ $$ |\$$$$$$$ |
|
||||
\________|\__/ \__| \______/ \__| \__| \____$$ |
|
||||
$$\ $$ |
|
||||
\$$$$$$ |
|
||||
\______/
|
||||
'''
|
||||
)
|
||||
print(
|
||||
'''
|
||||
This script helps you to set the neutral values of PWM of the driving motors correctly.
|
||||
It will send the intended signal for "not moving" to all the motors.
|
||||
On each motor you have to turn the correction screw until the motor really stands still.
|
||||
'''
|
||||
)
|
||||
|
||||
if not os.path.exists(config_filename):
|
||||
print("exomy.yaml does not exist. Finish config_motor_pins.py to generate it.")
|
||||
exit()
|
||||
|
||||
|
||||
pwm = Adafruit_PCA9685.PCA9685()
|
||||
|
||||
'''
|
||||
The drive_pwm_neutral value is determined from the exomy.yaml file.
|
||||
But it can be also calculated from the values of the PWM board and motors,
|
||||
like shown in the following calculation:
|
||||
|
||||
# For most motors a pwm frequency of 50Hz is normal
|
||||
pwm_frequency = 50.0 # Hz
|
||||
pwm.set_pwm_freq(pwm_frequency)
|
||||
|
||||
# The cycle is the inverted frequency converted to milliseconds
|
||||
cycle = 1.0/pwm_frequency * 1000.0 # 20 ms
|
||||
|
||||
# The time the pwm signal is set to on during the duty cycle
|
||||
on_time = 1.5 # ms
|
||||
|
||||
# Duty cycle is the percentage of a cycle the signal is on
|
||||
duty_cycle = on_time/cycle # 0.075
|
||||
|
||||
# The PCA 9685 board requests a 12 bit number for the duty_cycle
|
||||
value = int(duty_cycle*4096.0) # 307
|
||||
'''
|
||||
|
||||
value = get_drive_pwm_neutral()
|
||||
pin_list = get_driving_pins()
|
||||
|
||||
for pin in pin_list:
|
||||
pwm.set_pwm(pin, 0, value)
|
||||
time.sleep(0.1)
|
||||
|
||||
raw_input('Press any button if you are done to complete configuration\n')
|
||||
|
||||
for pin in pin_list:
|
||||
pwm.set_pwm(pin, 0, 0)
|
||||
@@ -0,0 +1,220 @@
|
||||
import Adafruit_PCA9685
|
||||
import time
|
||||
from shutil import copyfile
|
||||
import os
|
||||
|
||||
DRIVE_MOTOR, STEER_MOTOR = [0, 1]
|
||||
|
||||
pos_names = {
|
||||
1: 'fl',
|
||||
2: 'fr',
|
||||
3: 'cl',
|
||||
4: 'cr',
|
||||
5: 'rl',
|
||||
6: 'rr',
|
||||
}
|
||||
|
||||
pin_dict = {
|
||||
|
||||
}
|
||||
|
||||
pwm = Adafruit_PCA9685.PCA9685()
|
||||
# For most motors a pwm frequency of 50Hz is normal
|
||||
pwm_frequency = 50.0 # Hz
|
||||
pwm.set_pwm_freq(pwm_frequency)
|
||||
# The cycle is the inverted frequency converted to milliseconds
|
||||
cycle = 1.0/pwm_frequency * 1000.0 # ms
|
||||
|
||||
# The time the pwm signal is set to on during the duty cycle
|
||||
on_time_1 = 2.4 # ms
|
||||
on_time_2 = 1.5 # ms
|
||||
|
||||
# Duty cycle is the percentage of a cycle the signal is on
|
||||
duty_cycle_1 = on_time_1/cycle
|
||||
duty_cycle_2 = on_time_2/cycle
|
||||
|
||||
# The PCA 9685 board requests a 12 bit number for the duty_cycle
|
||||
value_1 = 200 #int(duty_cycle_1*4096.0)
|
||||
value_2 = 400#int(duty_cycle_2*4096.0)
|
||||
|
||||
class Motor():
|
||||
def __init__(self, pin):
|
||||
|
||||
self.pin_name = 'pin_'
|
||||
self.pin_number = pin
|
||||
|
||||
def wiggle_motor(self):
|
||||
|
||||
# Set the motor to the second value
|
||||
pwm.set_pwm(self.pin_number, 0, value_2)
|
||||
# Wait for 1 seconds
|
||||
time.sleep(1.0)
|
||||
# Set the motor to the first value
|
||||
pwm.set_pwm(self.pin_number, 0, value_1)
|
||||
# Wait for 1 seconds
|
||||
time.sleep(1.0)
|
||||
# Set the motor to neutral
|
||||
pwm.set_pwm(self.pin_number, 0, 307)
|
||||
# Wait for half seconds
|
||||
time.sleep(0.5)
|
||||
# Stop the motor
|
||||
pwm.set_pwm(self.pin_number, 0, 0)
|
||||
|
||||
def stop_motor(self):
|
||||
# Turn the motor off
|
||||
pwm.set_pwm(self.pin_number, 0, 0)
|
||||
|
||||
|
||||
def print_exomy_layout():
|
||||
print(
|
||||
'''
|
||||
1 fl-||-fr 2
|
||||
||
|
||||
3 cl-||-cr 4
|
||||
5 rl====rr 6
|
||||
'''
|
||||
)
|
||||
|
||||
|
||||
def update_config_file():
|
||||
file_name = '../config/exomy.yaml'
|
||||
template_file_name = file_name+'.template'
|
||||
|
||||
if not os.path.exists(file_name):
|
||||
copyfile(template_file_name, file_name)
|
||||
print("exomy.yaml.template was copied to exomy.yaml")
|
||||
|
||||
output = ''
|
||||
with open(file_name, 'rt') as file:
|
||||
for line in file:
|
||||
for key, value in pin_dict.items():
|
||||
if(key in line):
|
||||
line = line.replace(line.split(': ', 1)[
|
||||
1], str(value) + '\n')
|
||||
|
||||
break
|
||||
output += line
|
||||
|
||||
with open(file_name, 'w') as file:
|
||||
file.write(output)
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
print(
|
||||
'''
|
||||
$$$$$$$$\ $$\ $$\
|
||||
$$ _____| $$$\ $$$ |
|
||||
$$ | $$\ $$\ $$$$$$\ $$$$\ $$$$ |$$\ $$\
|
||||
$$$$$\ \$$\ $$ |$$ __$$\ $$\$$\$$ $$ |$$ | $$ |
|
||||
$$ __| \$$$$ / $$ / $$ |$$ \$$$ $$ |$$ | $$ |
|
||||
$$ | $$ $$< $$ | $$ |$$ |\$ /$$ |$$ | $$ |
|
||||
$$$$$$$$\ $$ /\$$\ \$$$$$$ |$$ | \_/ $$ |\$$$$$$$ |
|
||||
\________|\__/ \__| \______/ \__| \__| \____$$ |
|
||||
$$\ $$ |
|
||||
\$$$$$$ |
|
||||
\______/
|
||||
'''
|
||||
)
|
||||
print(
|
||||
'''
|
||||
###############
|
||||
Motor Configuration
|
||||
|
||||
This scripts leads you through the configuration of the motors.
|
||||
First we have to find out, to which pin of the PWM board a motor is connected.
|
||||
Look closely which motor moves and type in the answer.
|
||||
|
||||
Ensure to run the script until the end, otherwise your changes will not be saved!
|
||||
This script can always be stopped with ctrl+c and restarted.
|
||||
All other controls will be explained in the process.
|
||||
###############
|
||||
'''
|
||||
)
|
||||
|
||||
for pin_number in range(16):
|
||||
motor = Motor(pin_number)
|
||||
motor.stop_motor()
|
||||
|
||||
for pin_number in range(16):
|
||||
motor = Motor(pin_number)
|
||||
motor.wiggle_motor()
|
||||
type_selection = ''
|
||||
while(1):
|
||||
print("Pin #{}".format(pin_number))
|
||||
print(
|
||||
'Was it a steering or driving motor that moved, or should I repeat the movement? ')
|
||||
type_selection = raw_input('(d)rive (s)teer (r)epeat - (n)one (f)inish_configuration\n')
|
||||
if(type_selection == 'd'):
|
||||
motor.pin_name += 'drive_'
|
||||
print('Good job\n')
|
||||
break
|
||||
elif(type_selection == 's'):
|
||||
motor.pin_name += 'steer_'
|
||||
print('Good job\n')
|
||||
break
|
||||
elif(type_selection == 'r'):
|
||||
print('Look closely\n')
|
||||
motor.wiggle_motor()
|
||||
elif(type_selection == 'n'):
|
||||
print('Skipping pin')
|
||||
break
|
||||
elif(type_selection == 'f'):
|
||||
print('Finishing calibration at pin {}.'.format(pin_number))
|
||||
break
|
||||
else:
|
||||
print('Input must be d, s, r, n or f\n')
|
||||
|
||||
if (type_selection == 'd' or type_selection == 's'):
|
||||
while(1):
|
||||
print_exomy_layout()
|
||||
pos_selection = raw_input(
|
||||
'Type the position of the motor that moved.[1-6] or (r)epeat\n')
|
||||
if(pos_selection == 'r'):
|
||||
print('Look closely\n')
|
||||
else:
|
||||
try:
|
||||
pos = int(pos_selection)
|
||||
if(pos >= 1 and pos <= 6):
|
||||
motor.pin_name += pos_names[pos]
|
||||
break
|
||||
else:
|
||||
print('The input was not a number between 1 and 6\n')
|
||||
except ValueError:
|
||||
print('The input was not a number between 1 and 6\n')
|
||||
|
||||
pin_dict[motor.pin_name] = motor.pin_number
|
||||
print('Motor set!\n')
|
||||
print('########################################################\n')
|
||||
elif (type_selection == 'f'):
|
||||
break
|
||||
|
||||
|
||||
print('Now we will step through all the motors and check whether they have been assigned correctly.\n')
|
||||
print('Press ctrl+c if something is wrong and start the script again. \n')
|
||||
|
||||
for pin_name in pin_dict:
|
||||
print('moving {}'.format(pin_name))
|
||||
print_exomy_layout()
|
||||
|
||||
pin = pin_dict[pin_name]
|
||||
motor = Motor(pin)
|
||||
motor.wiggle_motor()
|
||||
raw_input('Press button to continue')
|
||||
|
||||
print("You assigned {}/12 motors.".format(len(pin_dict.keys())))
|
||||
|
||||
print('Write to config file.\n')
|
||||
update_config_file()
|
||||
print(
|
||||
'''
|
||||
$$$$$$$$\ $$\ $$\ $$\ $$\
|
||||
$$ _____|\__| \__| $$ | $$ |
|
||||
$$ | $$\ $$$$$$$\ $$\ $$$$$$$\ $$$$$$$\ $$$$$$\ $$$$$$$ |
|
||||
$$$$$\ $$ |$$ __$$\ $$ |$$ _____|$$ __$$\ $$ __$$\ $$ __$$ |
|
||||
$$ __| $$ |$$ | $$ |$$ |\$$$$$$\ $$ | $$ |$$$$$$$$ |$$ / $$ |
|
||||
$$ | $$ |$$ | $$ |$$ | \____$$\ $$ | $$ |$$ ____|$$ | $$ |
|
||||
$$ | $$ |$$ | $$ |$$ |$$$$$$$ |$$ | $$ |\$$$$$$$\ \$$$$$$$ |
|
||||
\__| \__|\__| \__|\__|\_______/ \__| \__| \_______| \_______|
|
||||
|
||||
''')
|
||||
|
||||
@@ -0,0 +1,147 @@
|
||||
import Adafruit_PCA9685
|
||||
import yaml
|
||||
import time
|
||||
import os
|
||||
|
||||
config_filename = '../config/exomy.yaml'
|
||||
|
||||
|
||||
def get_steering_motor_pins():
|
||||
steering_motor_pins = {}
|
||||
with open(config_filename, 'r') as file:
|
||||
param_dict = yaml.load(file)
|
||||
|
||||
for param_key, param_value in param_dict.items():
|
||||
if('pin_steer_' in str(param_key)):
|
||||
steering_motor_pins[param_key] = param_value
|
||||
return steering_motor_pins
|
||||
|
||||
def get_steering_pwm_neutral_values():
|
||||
steering_pwm_neutral_values = {}
|
||||
with open(config_filename, 'r') as file:
|
||||
param_dict = yaml.load(file)
|
||||
|
||||
for param_key, param_value in param_dict.items():
|
||||
if('steer_pwm_neutral_' in str(param_key)):
|
||||
steering_pwm_neutral_values[param_key] = param_value
|
||||
return steering_pwm_neutral_values
|
||||
|
||||
|
||||
def get_position_name(name):
|
||||
position_name = ''
|
||||
if('_fl' in name):
|
||||
position_name = 'Front Left'
|
||||
elif('_fr' in name):
|
||||
position_name = 'Front Right'
|
||||
elif('_cl' in name):
|
||||
position_name = 'Center Left'
|
||||
elif('_cr' in name):
|
||||
position_name = 'Center Right'
|
||||
elif('_rl' in name):
|
||||
position_name = 'Rear Left'
|
||||
elif('_rr' in name):
|
||||
position_name = 'Rear Right'
|
||||
|
||||
return position_name
|
||||
|
||||
|
||||
def update_config_file(steering_pwm_neutral_dict):
|
||||
output = ''
|
||||
with open(config_filename, 'rt') as file:
|
||||
for line in file:
|
||||
for key, value in steering_pwm_neutral_dict.items():
|
||||
if(key in line):
|
||||
line = line.replace(line.split(': ', 1)[
|
||||
1], str(value) + '\n')
|
||||
|
||||
break
|
||||
output += line
|
||||
|
||||
with open(config_filename, 'w') as file:
|
||||
file.write(output)
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
print(
|
||||
'''
|
||||
$$$$$$$$\ $$\ $$\
|
||||
$$ _____| $$$\ $$$ |
|
||||
$$ | $$\ $$\ $$$$$$\ $$$$\ $$$$ |$$\ $$\
|
||||
$$$$$\ \$$\ $$ |$$ __$$\ $$\$$\$$ $$ |$$ | $$ |
|
||||
$$ __| \$$$$ / $$ / $$ |$$ \$$$ $$ |$$ | $$ |
|
||||
$$ | $$ $$< $$ | $$ |$$ |\$ /$$ |$$ | $$ |
|
||||
$$$$$$$$\ $$ /\$$\ \$$$$$$ |$$ | \_/ $$ |\$$$$$$$ |
|
||||
\________|\__/ \__| \______/ \__| \__| \____$$ |
|
||||
$$\ $$ |
|
||||
\$$$$$$ |
|
||||
\______/
|
||||
'''
|
||||
)
|
||||
print(
|
||||
'''
|
||||
This script helps you to set the neutral pwm values for the steering motors.
|
||||
You will iterate over all steering motors and set them to a neutral position.
|
||||
The determined value is written to the config file.
|
||||
|
||||
Commands:
|
||||
a - Decrease value for current pin
|
||||
d - Increase value for current pin
|
||||
q - Finish setting value for current pin
|
||||
|
||||
[Every of these commands must be confirmed with the enter key]
|
||||
|
||||
ctrl+c - Exit script
|
||||
------------------------------------------------------------------------------
|
||||
'''
|
||||
)
|
||||
|
||||
if not os.path.exists(config_filename):
|
||||
print("exomy.yaml does not exist. Finish config_motor_pins.py to generate it.")
|
||||
exit()
|
||||
|
||||
pwm = Adafruit_PCA9685.PCA9685()
|
||||
# For most motors a pwm frequency of 50Hz is normal
|
||||
pwm_frequency = 50.0 # Hz
|
||||
pwm.set_pwm_freq(pwm_frequency)
|
||||
|
||||
# The cycle is the inverted frequency converted to milliseconds
|
||||
cycle = 1.0/pwm_frequency * 1000.0 # ms
|
||||
|
||||
# The time the pwm signal is set to on during the duty cycle
|
||||
on_time = 1.5 # ms
|
||||
|
||||
# Duty cycle is the percentage of a cycle the signal is on
|
||||
duty_cycle = on_time/cycle
|
||||
|
||||
# The PCA 9685 board requests a 12 bit number for the duty_cycle
|
||||
initial_value = int(duty_cycle*4096.0)
|
||||
|
||||
# Get all steering pins
|
||||
steering_motor_pins = get_steering_motor_pins()
|
||||
pwm_neutral_dict = get_steering_pwm_neutral_values()
|
||||
# Iterating over all motors and fine tune the zero value
|
||||
for pin_name, pin_value in steering_motor_pins.items():
|
||||
pwm_neutral_name = pin_name.replace('pin_steer_', 'steer_pwm_neutral_')
|
||||
pwm_neutral_value = pwm_neutral_dict[pwm_neutral_name]
|
||||
|
||||
print('Set ' + get_position_name(pin_name) + ' steering motor: \n')
|
||||
while(1):
|
||||
# Set motor
|
||||
pwm.set_pwm(pin_value, 0, pwm_neutral_value)
|
||||
time.sleep(0.1)
|
||||
print('Current value: ' + str(pwm_neutral_value) + '\n')
|
||||
input = raw_input(
|
||||
'q-set / a-decrease pwm neutral value/ d-increase pwm neutral value\n')
|
||||
if(input is 'q'):
|
||||
print('PWM neutral value for ' + get_position_name(pin_name) +
|
||||
' has been set.\n')
|
||||
break
|
||||
elif(input is 'a'):
|
||||
print('Decreased pwm neutral value')
|
||||
pwm_neutral_value-= 5
|
||||
elif(input is 'd'):
|
||||
print('Increased pwm neutral value')
|
||||
pwm_neutral_value += 5
|
||||
pwm_neutral_dict[pwm_neutral_name] = pwm_neutral_value
|
||||
update_config_file(pwm_neutral_dict)
|
||||
print("Finished configuration!!!")
|
||||
@@ -0,0 +1,94 @@
|
||||
import Adafruit_PCA9685
|
||||
import time
|
||||
import sys
|
||||
'''
|
||||
This script helps to test pwm motors with the Adafruit PCA9685 board
|
||||
Example usage:
|
||||
python motor_test.py 3
|
||||
|
||||
Performs a motor test for the motor connected to pin 3 of the PWM board
|
||||
'''
|
||||
# Check if the pin number is given as an argument
|
||||
if len(sys.argv) < 2:
|
||||
print('You must give the pin number of the motor to be tested as argument.')
|
||||
print('E.g: python motor_test.py 3')
|
||||
print('Tests the motor connected to pin 3.')
|
||||
exit()
|
||||
|
||||
# Set the pin of the motor
|
||||
pin = int(sys.argv[1])
|
||||
print('Pin: '+str(pin))
|
||||
|
||||
|
||||
pwm = Adafruit_PCA9685.PCA9685()
|
||||
# For most motors a pwm frequency of 50Hz is normal
|
||||
pwm_frequency = 50.0 #Hz
|
||||
pwm.set_pwm_freq(pwm_frequency)
|
||||
|
||||
# The cycle is the inverted frequency converted to milliseconds
|
||||
cycle = 1.0/pwm_frequency * 1000.0 #ms
|
||||
|
||||
# The time the pwm signal is set to on during the duty cycle
|
||||
on_time = 2.0 #ms
|
||||
|
||||
selection = ''
|
||||
|
||||
while(selection != '0'):
|
||||
|
||||
print("What do you want to test?")
|
||||
print("1. Min to Max oscilation")
|
||||
print('2. Incremental positioning')
|
||||
print('0. Abort')
|
||||
selection = raw_input()
|
||||
|
||||
if (int(selection) == 1):
|
||||
|
||||
min_t = 0.5 # ms
|
||||
max_t = 2.5 # ms
|
||||
mid_t = min_t+max_t/2
|
||||
|
||||
print("pulsewidth_min = {:.2f}, pulsewidth_max = {:.2f}".format(min_t, max_t))
|
||||
|
||||
# *_dc is the percentage of a cycle the signal is on
|
||||
min_dc = min_t/cycle
|
||||
max_dc = max_t/cycle
|
||||
mid_dc = mid_t/cycle
|
||||
|
||||
dc_list = [min_dc, mid_dc, max_dc, mid_dc]
|
||||
for dc in dc_list:
|
||||
pwm.set_pwm(pin, 0, int(dc*4096.0))
|
||||
time.sleep(2.0)
|
||||
|
||||
if (int(selection) == 2):
|
||||
|
||||
curr_t = 1.5 # ms
|
||||
curr_dc = curr_t/cycle
|
||||
|
||||
step_size = 0.1 # ms
|
||||
|
||||
step_size_scaling = 0.2
|
||||
|
||||
dc_selection = ''
|
||||
|
||||
while (dc_selection != '0'):
|
||||
dc_selection = raw_input('a-d: change pulsewidth | w-s: change step size | 0: back to menu\n')
|
||||
if dc_selection == 'a':
|
||||
curr_t = curr_t - step_size
|
||||
elif dc_selection == 'd':
|
||||
curr_t = curr_t + step_size
|
||||
elif dc_selection == 's':
|
||||
step_size = step_size*(1-step_size_scaling)
|
||||
elif dc_selection == 'w':
|
||||
step_size = step_size*(1+step_size_scaling)
|
||||
|
||||
curr_dc = curr_t/cycle
|
||||
|
||||
curr_pwm = int(curr_dc*4096.0)
|
||||
print("t_current:\t{0:.4f} [ms]\nstep_size:\t{1:.4f} [ms]\ncurr_pwm: {2:.2f}".format(curr_t, step_size, curr_pwm))
|
||||
|
||||
pwm.set_pwm(pin, 0, curr_pwm)
|
||||
|
||||
|
||||
|
||||
# The PCA 9685 board requests a 12 bit number for the duty_cycle
|
||||
pwm.set_pwm(pin, 0, 0)
|
||||
@@ -0,0 +1,14 @@
|
||||
import Adafruit_PCA9685
|
||||
import time
|
||||
import sys
|
||||
|
||||
'''
|
||||
This script simply stops all the motors, in case they were left in a running state.
|
||||
'''
|
||||
pwm = Adafruit_PCA9685.PCA9685()
|
||||
# For most motors a pwm frequency of 50Hz is normal
|
||||
pwm_frequency = 50.0 # Hz
|
||||
pwm.set_pwm_freq(pwm_frequency)
|
||||
|
||||
for pin_number in range(16):
|
||||
pwm.set_pwm(pin_number, 0, 0)
|
||||
@@ -0,0 +1,93 @@
|
||||
#!/usr/bin/env python
|
||||
import rospy
|
||||
from sensor_msgs.msg import Joy
|
||||
from exomy.msg import RoverCommand
|
||||
from locomotion_modes import LocomotionMode
|
||||
import math
|
||||
|
||||
# Define locomotion modes
|
||||
global locomotion_mode
|
||||
global motors_enabled
|
||||
|
||||
locomotion_mode = LocomotionMode.ACKERMANN.value
|
||||
motors_enabled = True
|
||||
|
||||
|
||||
def callback(data):
|
||||
|
||||
global locomotion_mode
|
||||
global motors_enabled
|
||||
|
||||
rover_cmd = RoverCommand()
|
||||
|
||||
# Function map for the Logitech F710 joystick
|
||||
# Button on pad | function
|
||||
# --------------|----------------------
|
||||
# A | Ackermann mode
|
||||
# X | Point turn mode
|
||||
# Y | Crabbing mode
|
||||
# Left Stick | Control speed and direction
|
||||
# START Button | Enable and disable motors
|
||||
|
||||
# Reading out joystick data
|
||||
y = data.axes[1]
|
||||
x = data.axes[0]
|
||||
|
||||
# Reading out button data to set locomotion mode
|
||||
# X Button
|
||||
if (data.buttons[0] == 1):
|
||||
locomotion_mode = LocomotionMode.POINT_TURN.value
|
||||
# A Button
|
||||
if (data.buttons[1] == 1):
|
||||
locomotion_mode = LocomotionMode.ACKERMANN.value
|
||||
# B Button
|
||||
if (data.buttons[2] == 1):
|
||||
pass
|
||||
# Y Button
|
||||
if (data.buttons[3] == 1):
|
||||
locomotion_mode = LocomotionMode.CRABBING.value
|
||||
|
||||
rover_cmd.locomotion_mode = locomotion_mode
|
||||
|
||||
# Enable and disable motors
|
||||
# START Button
|
||||
if (data.buttons[9] == 1):
|
||||
if motors_enabled is True:
|
||||
motors_enabled = False
|
||||
rospy.loginfo("Motors disabled!")
|
||||
elif motors_enabled is False:
|
||||
motors_enabled = True
|
||||
rospy.loginfo("Motors enabled!")
|
||||
else:
|
||||
rospy.logerr(
|
||||
"Exceptional value for [motors_enabled] = {}".format(motors_enabled))
|
||||
motors_enabled = False
|
||||
|
||||
rover_cmd.motors_enabled = motors_enabled
|
||||
|
||||
# The velocity is decoded as value between 0...100
|
||||
rover_cmd.vel = 100 * min(math.sqrt(x*x + y*y), 1.0)
|
||||
|
||||
# The steering is described as an angle between -180...180
|
||||
# Which describe the joystick position as follows:
|
||||
# +90
|
||||
# 0 +-180
|
||||
# -90
|
||||
#
|
||||
rover_cmd.steering = math.atan2(y, x)*180.0/math.pi
|
||||
|
||||
rover_cmd.connected = True
|
||||
|
||||
pub.publish(rover_cmd)
|
||||
|
||||
|
||||
if __name__ == '__main__':
|
||||
global pub
|
||||
|
||||
rospy.init_node('joystick_parser_node')
|
||||
rospy.loginfo('joystick_parser_node started')
|
||||
|
||||
sub = rospy.Subscriber("/joy", Joy, callback, queue_size=1)
|
||||
pub = rospy.Publisher('/rover_command', RoverCommand, queue_size=1)
|
||||
|
||||
rospy.spin()
|
||||
@@ -0,0 +1,10 @@
|
||||
#!/usr/bin/env python
|
||||
|
||||
import enum
|
||||
|
||||
|
||||
class LocomotionMode(enum.Enum):
|
||||
FAKE_ACKERMANN = 0
|
||||
ACKERMANN = 1
|
||||
POINT_TURN = 2
|
||||
CRABBING = 3
|
||||
@@ -0,0 +1,46 @@
|
||||
#!/usr/bin/env python
|
||||
import time
|
||||
import rospy
|
||||
|
||||
from exomy.msg import MotorCommands
|
||||
from motors import Motors
|
||||
|
||||
motors = Motors()
|
||||
global watchdog_timer
|
||||
|
||||
|
||||
def callback(cmds):
|
||||
motors.setSteering(cmds.motor_angles)
|
||||
motors.setDriving(cmds.motor_speeds)
|
||||
|
||||
global watchdog_timer
|
||||
watchdog_timer.shutdown()
|
||||
# If this timer runs longer than the duration specified,
|
||||
# then watchdog() is called stopping the driving motors.
|
||||
watchdog_timer = rospy.Timer(rospy.Duration(5.0), watchdog, oneshot=True)
|
||||
|
||||
|
||||
def shutdown():
|
||||
motors.stopMotors()
|
||||
|
||||
|
||||
def watchdog(event):
|
||||
rospy.loginfo("Watchdog fired. Stopping driving motors.")
|
||||
motors.stopMotors()
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
# This node waits for commands from the robot and sets the motors accordingly
|
||||
rospy.init_node("motors")
|
||||
rospy.loginfo("Starting the motors node")
|
||||
rospy.on_shutdown(shutdown)
|
||||
|
||||
global watchdog_timer
|
||||
watchdog_timer = rospy.Timer(rospy.Duration(1.0), watchdog, oneshot=True)
|
||||
|
||||
sub = rospy.Subscriber(
|
||||
"/motor_commands", MotorCommands, callback, queue_size=1)
|
||||
|
||||
rate = rospy.Rate(10)
|
||||
|
||||
rospy.spin()
|
||||
@@ -0,0 +1,124 @@
|
||||
#!/usr/bin/env python
|
||||
import rospy
|
||||
from std_msgs.msg import String
|
||||
|
||||
import time
|
||||
import numpy as np
|
||||
|
||||
import Adafruit_PCA9685
|
||||
|
||||
|
||||
class Motors():
|
||||
'''
|
||||
Motors class contains all functions to control the steering and driving
|
||||
'''
|
||||
|
||||
# Define wheel names
|
||||
FL, FR, CL, CR, RL, RR = range(0, 6)
|
||||
|
||||
# Motor commands are assuming positiv=driving_forward, negative=driving_backwards.
|
||||
# The driving direction of the left side has to be inverted for this to apply to all wheels.
|
||||
wheel_directions = [-1, 1, -1, 1, -1, 1]
|
||||
|
||||
# 1 fl-||-fr 2
|
||||
# ||
|
||||
# 3 cl-||-cr 4
|
||||
# 5 rl====rr 6
|
||||
|
||||
def __init__(self):
|
||||
|
||||
# Dictionary containing the pins of all motors
|
||||
self.pins = {
|
||||
'drive': {},
|
||||
'steer': {}
|
||||
}
|
||||
|
||||
# Set variables for the GPIO motor pins
|
||||
self.pins['drive'][self.FL] = rospy.get_param("pin_drive_fl")
|
||||
self.pins['steer'][self.FL] = rospy.get_param("pin_steer_fl")
|
||||
|
||||
self.pins['drive'][self.FR] = rospy.get_param("pin_drive_fr")
|
||||
self.pins['steer'][self.FR] = rospy.get_param("pin_steer_fr")
|
||||
|
||||
self.pins['drive'][self.CL] = rospy.get_param("pin_drive_cl")
|
||||
self.pins['steer'][self.CL] = rospy.get_param("pin_steer_cl")
|
||||
|
||||
self.pins['drive'][self.CR] = rospy.get_param("pin_drive_cr")
|
||||
self.pins['steer'][self.CR] = rospy.get_param("pin_steer_cr")
|
||||
|
||||
self.pins['drive'][self.RL] = rospy.get_param("pin_drive_rl")
|
||||
self.pins['steer'][self.RL] = rospy.get_param("pin_steer_rl")
|
||||
|
||||
self.pins['drive'][self.RR] = rospy.get_param("pin_drive_rr")
|
||||
self.pins['steer'][self.RR] = rospy.get_param("pin_steer_rr")
|
||||
|
||||
# PWM characteristics
|
||||
self.pwm = Adafruit_PCA9685.PCA9685()
|
||||
self.pwm.set_pwm_freq(50) # Hz
|
||||
|
||||
self.steering_pwm_neutral = [None] * 6
|
||||
|
||||
self.steering_pwm_neutral[self.FL] = rospy.get_param("steer_pwm_neutral_fl")
|
||||
self.steering_pwm_neutral[self.FR] = rospy.get_param("steer_pwm_neutral_fr")
|
||||
self.steering_pwm_neutral[self.CL] = rospy.get_param("steer_pwm_neutral_cl")
|
||||
self.steering_pwm_neutral[self.CR] = rospy.get_param("steer_pwm_neutral_cr")
|
||||
self.steering_pwm_neutral[self.RL] = rospy.get_param("steer_pwm_neutral_rl")
|
||||
self.steering_pwm_neutral[self.RR] = rospy.get_param("steer_pwm_neutral_rr")
|
||||
self.steering_pwm_range = rospy.get_param("steer_pwm_range")
|
||||
|
||||
self.driving_pwm_low_limit = 100
|
||||
self.driving_pwm_neutral = rospy.get_param("drive_pwm_neutral")
|
||||
self.driving_pwm_upper_limit = 500
|
||||
self.driving_pwm_range = rospy.get_param("drive_pwm_range")
|
||||
|
||||
# Set steering motors to neutral values (straight)
|
||||
for wheel_name, motor_pin in self.pins['steer'].items():
|
||||
self.pwm.set_pwm(motor_pin, 0,
|
||||
self.steering_pwm_neutral[wheel_name])
|
||||
time.sleep(0.1)
|
||||
|
||||
self.wiggle()
|
||||
|
||||
def wiggle(self):
|
||||
time.sleep(0.1)
|
||||
self.pwm.set_pwm(self.pins['steer'][self.FL], 0,
|
||||
int(self.steering_pwm_neutral[self.FL] + self.steering_pwm_range * 0.3))
|
||||
time.sleep(0.1)
|
||||
self.pwm.set_pwm(self.pins['steer'][self.FR], 0,
|
||||
int(self.steering_pwm_neutral[self.FR] + self.steering_pwm_range * 0.3))
|
||||
time.sleep(0.3)
|
||||
self.pwm.set_pwm(self.pins['steer'][self.FL], 0,
|
||||
int(self.steering_pwm_neutral[self.FL] - self.steering_pwm_range * 0.3))
|
||||
time.sleep(0.1)
|
||||
self.pwm.set_pwm(self.pins['steer'][self.FR], 0,
|
||||
int(self.steering_pwm_neutral[self.FR] - self.steering_pwm_range * 0.3))
|
||||
time.sleep(0.3)
|
||||
self.pwm.set_pwm(self.pins['steer'][self.FL], 0,
|
||||
int(self.steering_pwm_neutral[self.FL]))
|
||||
time.sleep(0.1)
|
||||
self.pwm.set_pwm(self.pins['steer'][self.FR], 0,
|
||||
int(self.steering_pwm_neutral[self.FR]))
|
||||
time.sleep(0.3)
|
||||
|
||||
def setSteering(self, steering_command):
|
||||
# Loop through pin dictionary. The items key is the wheel_name and the value the pin.
|
||||
for wheel_name, motor_pin in self.pins['steer'].items():
|
||||
duty_cycle = int(
|
||||
self.steering_pwm_neutral[wheel_name] + steering_command[wheel_name]/90.0 * self.steering_pwm_range)
|
||||
|
||||
self.pwm.set_pwm(motor_pin, 0, duty_cycle)
|
||||
|
||||
def setDriving(self, driving_command):
|
||||
# Loop through pin dictionary. The items key is the wheel_name and the value the pin.
|
||||
for wheel_name, motor_pin in self.pins['drive'].items():
|
||||
duty_cycle = int(self.driving_pwm_neutral +
|
||||
driving_command[wheel_name]/100.0 * self.driving_pwm_range * self.wheel_directions[wheel_name])
|
||||
|
||||
self.pwm.set_pwm(motor_pin, 0, duty_cycle)
|
||||
|
||||
def stopMotors(self):
|
||||
# Set driving wheels to neutral position to stop them
|
||||
duty_cycle = int(self.driving_pwm_neutral)
|
||||
|
||||
for wheel_name, motor_pin in self.pins['drive'].items():
|
||||
self.pwm.set_pwm(motor_pin, 0, duty_cycle)
|
||||
@@ -0,0 +1,41 @@
|
||||
#!/usr/bin/env python
|
||||
import time
|
||||
from exomy.msg import RoverCommand, MotorCommands, Screen
|
||||
import rospy
|
||||
from rover import Rover
|
||||
import message_filters
|
||||
|
||||
|
||||
global exomy
|
||||
exomy = Rover()
|
||||
|
||||
|
||||
def joy_callback(message):
|
||||
cmds = MotorCommands()
|
||||
|
||||
if message.motors_enabled is True:
|
||||
exomy.setLocomotionMode(message.locomotion_mode)
|
||||
|
||||
cmds.motor_angles = exomy.joystickToSteeringAngle(
|
||||
message.vel, message.steering)
|
||||
cmds.motor_speeds = exomy.joystickToVelocity(
|
||||
message.vel, message.steering)
|
||||
else:
|
||||
cmds.motor_angles = exomy.joystickToSteeringAngle(0, 0)
|
||||
cmds.motor_speeds = exomy.joystickToVelocity(0, 0)
|
||||
|
||||
robot_pub.publish(cmds)
|
||||
|
||||
|
||||
if __name__ == '__main__':
|
||||
rospy.init_node('robot_node')
|
||||
rospy.loginfo("Starting the robot node")
|
||||
global robot_pub
|
||||
joy_sub = rospy.Subscriber(
|
||||
"/rover_command", RoverCommand, joy_callback, queue_size=1)
|
||||
|
||||
rate = rospy.Rate(10)
|
||||
|
||||
robot_pub = rospy.Publisher("/motor_commands", MotorCommands, queue_size=1)
|
||||
|
||||
rospy.spin()
|
||||
@@ -0,0 +1,298 @@
|
||||
#!/usr/bin/env python
|
||||
import rospy
|
||||
import time
|
||||
import math
|
||||
import enum
|
||||
from locomotion_modes import LocomotionMode
|
||||
import numpy as np
|
||||
|
||||
|
||||
class Rover():
|
||||
'''
|
||||
Rover class contains all the math and motor control algorithms to move the rover
|
||||
'''
|
||||
|
||||
# Defining wheel names
|
||||
FL, FR, CL, CR, RL, RR = range(0, 6)
|
||||
|
||||
# Defining locomotion modes
|
||||
FAKE_ACKERMANN, ACKERMANN, POINT_TURN, CRABBING = range(0, 4)
|
||||
|
||||
def __init__(self):
|
||||
self.locomotion_mode = LocomotionMode.FAKE_ACKERMANN
|
||||
|
||||
self.wheel_x = 12.0
|
||||
self.wheel_y = 20.0
|
||||
|
||||
max_steering_angle = 45
|
||||
self.ackermann_r_min = abs(
|
||||
self.wheel_y) / math.tan(max_steering_angle * math.pi / 180.0) + self.wheel_x
|
||||
|
||||
self.ackermann_r_max = 250
|
||||
|
||||
def setLocomotionMode(self, locomotion_mode_command):
|
||||
'''
|
||||
Sets the locomotion mode
|
||||
'''
|
||||
if(self.locomotion_mode != locomotion_mode_command):
|
||||
self.locomotion_mode = locomotion_mode_command
|
||||
rospy.loginfo('Set locomotion mode to: %s',
|
||||
LocomotionMode(locomotion_mode_command).name)
|
||||
|
||||
def joystickToSteeringAngle(self, driving_command, steering_command):
|
||||
'''
|
||||
Converts the steering command [angle of joystick] to angles for the different motors
|
||||
|
||||
:param int driving_command: Drive speed command range from -100 to 100
|
||||
:param int stering_command: Turning radius command with the values 0(left) +90(forward) -90(backward) +-180(right)
|
||||
'''
|
||||
|
||||
steering_angles = [0]*6
|
||||
deg = steering_command
|
||||
|
||||
if(self.locomotion_mode == LocomotionMode.FAKE_ACKERMANN.value):
|
||||
if (driving_command == 0):
|
||||
# Stop
|
||||
steering_angles[self.FL] = 0
|
||||
steering_angles[self.FR] = 0
|
||||
steering_angles[self.CR] = 0
|
||||
steering_angles[self.CL] = 0
|
||||
steering_angles[self.RL] = 0
|
||||
steering_angles[self.RR] = 0
|
||||
return steering_angles
|
||||
|
||||
if(80 < deg < 100):
|
||||
# Drive straight forward
|
||||
steering_angles[self.FL] = 0
|
||||
steering_angles[self.FR] = 0
|
||||
steering_angles[self.CR] = 0
|
||||
steering_angles[self.CL] = 0
|
||||
steering_angles[self.RL] = 0
|
||||
steering_angles[self.RR] = 0
|
||||
elif(-80 < deg < -100):
|
||||
# Drive straight backwards
|
||||
steering_angles[self.FL] = 0
|
||||
steering_angles[self.FR] = 0
|
||||
steering_angles[self.CR] = 0
|
||||
steering_angles[self.CL] = 0
|
||||
steering_angles[self.RL] = 0
|
||||
steering_angles[self.RR] = 0
|
||||
elif(100 < deg <= 180):
|
||||
# Drive right forwards
|
||||
steering_angles[self.FL] = 45
|
||||
steering_angles[self.FR] = 45
|
||||
steering_angles[self.CR] = 0
|
||||
steering_angles[self.CL] = 0
|
||||
steering_angles[self.RL] = -45
|
||||
steering_angles[self.RR] = -45
|
||||
elif(-100 > deg >= -180):
|
||||
# Drive right backwards
|
||||
steering_angles[self.FL] = 45
|
||||
steering_angles[self.FR] = 45
|
||||
steering_angles[self.CR] = 0
|
||||
steering_angles[self.CL] = 0
|
||||
steering_angles[self.RL] = -45
|
||||
steering_angles[self.RR] = -45
|
||||
elif(80 > deg >= 0):
|
||||
# Drive left forwards
|
||||
steering_angles[self.FL] = -45
|
||||
steering_angles[self.FR] = -45
|
||||
steering_angles[self.CR] = 0
|
||||
steering_angles[self.CL] = 0
|
||||
steering_angles[self.RL] = 45
|
||||
steering_angles[self.RR] = 45
|
||||
elif(0 > deg > -80):
|
||||
# Drive left backwards
|
||||
steering_angles[self.FL] = -45
|
||||
steering_angles[self.FR] = -45
|
||||
steering_angles[self.CR] = 0
|
||||
steering_angles[self.CL] = 0
|
||||
steering_angles[self.RL] = 45
|
||||
steering_angles[self.RR] = 45
|
||||
|
||||
return steering_angles
|
||||
if(self.locomotion_mode == LocomotionMode.ACKERMANN.value):
|
||||
|
||||
# No steering if robot is not driving
|
||||
if(driving_command is 0):
|
||||
return steering_angles
|
||||
|
||||
# Scale between min and max Ackermann radius
|
||||
if math.cos(math.radians(steering_command)) == 0:
|
||||
r = self.ackermann_r_max
|
||||
else:
|
||||
r = self.ackermann_r_max - \
|
||||
abs(math.cos(math.radians(steering_command))) * \
|
||||
((self.ackermann_r_max-self.ackermann_r_min))
|
||||
|
||||
# No steering
|
||||
if r == self.ackermann_r_max:
|
||||
return steering_angles
|
||||
|
||||
inner_angle = int(math.degrees(
|
||||
math.atan(self.wheel_x/(abs(r)-self.wheel_y))))
|
||||
outer_angle = int(math.degrees(
|
||||
math.atan(self.wheel_x/(abs(r)+self.wheel_y))))
|
||||
|
||||
if steering_command > 90 or steering_command < -90:
|
||||
# Steering to the right
|
||||
steering_angles[self.FL] = outer_angle
|
||||
steering_angles[self.FR] = inner_angle
|
||||
steering_angles[self.RL] = -outer_angle
|
||||
steering_angles[self.RR] = -inner_angle
|
||||
else:
|
||||
# Steering to the left
|
||||
steering_angles[self.FL] = -inner_angle
|
||||
steering_angles[self.FR] = -outer_angle
|
||||
steering_angles[self.RL] = inner_angle
|
||||
steering_angles[self.RR] = outer_angle
|
||||
|
||||
return steering_angles
|
||||
|
||||
if(self.locomotion_mode == LocomotionMode.POINT_TURN.value):
|
||||
steering_angles[self.FL] = 45
|
||||
steering_angles[self.FR] = -45
|
||||
steering_angles[self.RL] = -45
|
||||
steering_angles[self.RR] = 45
|
||||
|
||||
return steering_angles
|
||||
if(self.locomotion_mode == LocomotionMode.CRABBING.value):
|
||||
if(driving_command != 0):
|
||||
wheel_direction = 0
|
||||
if(steering_command > 0):
|
||||
wheel_direction = steering_command - 90
|
||||
|
||||
elif(steering_command <= 0):
|
||||
wheel_direction = steering_command + 90
|
||||
|
||||
wheel_direction = np.clip(wheel_direction, -75, 75)
|
||||
|
||||
steering_angles[self.FL] = wheel_direction
|
||||
steering_angles[self.FR] = wheel_direction
|
||||
steering_angles[self.CL] = wheel_direction
|
||||
steering_angles[self.CR] = wheel_direction
|
||||
steering_angles[self.RL] = wheel_direction
|
||||
steering_angles[self.RR] = wheel_direction
|
||||
|
||||
return steering_angles
|
||||
|
||||
def joystickToVelocity(self, driving_command, steering_command):
|
||||
'''
|
||||
Converts the steering and drive command to the speeds of the individual motors
|
||||
|
||||
:param int driving_command: Drive speed command range from -100 to 100
|
||||
:param int stering_command: Turning radius command with the values 0(left) +90(forward) -90(backward) +-180(right)
|
||||
'''
|
||||
|
||||
motor_speeds = [0]*6
|
||||
if (self.locomotion_mode == LocomotionMode.FAKE_ACKERMANN.value):
|
||||
if(driving_command > 0 and steering_command >= 0):
|
||||
motor_speeds[self.FL] = 50
|
||||
motor_speeds[self.FR] = 50
|
||||
motor_speeds[self.CR] = 50
|
||||
motor_speeds[self.CL] = 50
|
||||
motor_speeds[self.RL] = 50
|
||||
motor_speeds[self.RR] = 50
|
||||
|
||||
elif(driving_command > 0 and steering_command <= 0):
|
||||
motor_speeds[self.FL] = -50
|
||||
motor_speeds[self.FR] = -50
|
||||
motor_speeds[self.CR] = -50
|
||||
motor_speeds[self.CL] = -50
|
||||
motor_speeds[self.RL] = -50
|
||||
motor_speeds[self.RR] = -50
|
||||
|
||||
return motor_speeds
|
||||
|
||||
if (self.locomotion_mode == LocomotionMode.ACKERMANN.value):
|
||||
v = driving_command
|
||||
if(steering_command < 0):
|
||||
v *= -1
|
||||
|
||||
# Scale between min and max Ackermann radius
|
||||
radius = self.ackermann_r_max - \
|
||||
abs(math.cos(math.radians(steering_command))) * \
|
||||
((self.ackermann_r_max-self.ackermann_r_min))
|
||||
|
||||
if (v == 0):
|
||||
return motor_speeds
|
||||
|
||||
if (radius == self.ackermann_r_max):
|
||||
return [v] * 6
|
||||
else:
|
||||
rmax = radius + self.wheel_x
|
||||
|
||||
a = math.pow(self.wheel_y, 2)
|
||||
b = math.pow(abs(radius) + self.wheel_x, 2)
|
||||
c = math.pow(abs(radius) - self.wheel_x, 2)
|
||||
rmax_float = float(rmax)
|
||||
|
||||
r1 = math.sqrt(a+b)
|
||||
r2 = rmax_float
|
||||
r3 = r1
|
||||
r4 = math.sqrt(a+c)
|
||||
r5 = abs(radius) - self.wheel_x
|
||||
r6 = r4
|
||||
|
||||
v1 = int(v)
|
||||
v2 = int(v*r2/r1)
|
||||
v3 = v1
|
||||
v4 = int(v*r4/r1)
|
||||
v5 = int(v*r5/r1)
|
||||
v6 = v4
|
||||
|
||||
if (steering_command > 90 or steering_command < -90):
|
||||
motor_speeds = [v1, v2, v3, v4, v5, v6]
|
||||
else:
|
||||
motor_speeds = [v6, v5, v4, v3, v2, v1]
|
||||
|
||||
return motor_speeds
|
||||
|
||||
if (self.locomotion_mode == LocomotionMode.POINT_TURN.value):
|
||||
deg = steering_command
|
||||
if(driving_command is not 0):
|
||||
# Left turn
|
||||
if(deg < 85 and deg > -85):
|
||||
motor_speeds[self.FL] = -50
|
||||
motor_speeds[self.FR] = 50
|
||||
motor_speeds[self.CL] = -50
|
||||
motor_speeds[self.CR] = 50
|
||||
motor_speeds[self.RL] = -50
|
||||
motor_speeds[self.RR] = 50
|
||||
# Right turn
|
||||
elif(deg > 95 or deg < -95):
|
||||
motor_speeds[self.FL] = 50
|
||||
motor_speeds[self.FR] = -50
|
||||
motor_speeds[self.CL] = 50
|
||||
motor_speeds[self.CR] = -50
|
||||
motor_speeds[self.RL] = 50
|
||||
motor_speeds[self.RR] = -50
|
||||
else:
|
||||
# Stop
|
||||
motor_speeds[self.FL] = 0
|
||||
motor_speeds[self.FR] = 0
|
||||
motor_speeds[self.CL] = 0
|
||||
motor_speeds[self.CR] = 0
|
||||
motor_speeds[self.RL] = 0
|
||||
motor_speeds[self.RR] = 0
|
||||
|
||||
return motor_speeds
|
||||
|
||||
if(self.locomotion_mode == LocomotionMode.CRABBING.value):
|
||||
if(driving_command > 0):
|
||||
if(steering_command > 0):
|
||||
motor_speeds[self.FL] = 50
|
||||
motor_speeds[self.FR] = 50
|
||||
motor_speeds[self.CL] = 50
|
||||
motor_speeds[self.CR] = 50
|
||||
motor_speeds[self.RL] = 50
|
||||
motor_speeds[self.RR] = 50
|
||||
elif(steering_command <= 0):
|
||||
motor_speeds[self.FL] = -50
|
||||
motor_speeds[self.FR] = -50
|
||||
motor_speeds[self.CL] = -50
|
||||
motor_speeds[self.CR] = -50
|
||||
motor_speeds[self.RL] = -50
|
||||
motor_speeds[self.RR] = -50
|
||||
|
||||
return motor_speeds
|
||||
@@ -0,0 +1,3 @@
|
||||
*.STL
|
||||
*.STEP
|
||||
*~$
|
||||
@@ -0,0 +1,14 @@
|
||||
# Changelog
|
||||
|
||||
## [v1.0.2] - 2020-07-16
|
||||
- add "Optional Parts" containing various add-ons.
|
||||
- Flexi fill indoors tires
|
||||
- Bowtie
|
||||
- Universal neck decoration mount
|
||||
- fix URL in purchasing BoM of M4x16 button head screw
|
||||
- increase height of P15_DCDC_Holddown.SLDPRT and standoffheight of P01_Chassis.SLDPRT to match screw length correctly.
|
||||
- add chamfers to holes in P20_Head.SLDPRT.
|
||||
- add SolidWorks view-cameras to A01_ExoMy.SLDASM
|
||||
|
||||
## [v1.0.0] - 2020-03-09
|
||||
- first released version of ExoMy
|
||||
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
BIN
Binary file not shown.
BIN
Binary file not shown.
Binary file not shown.
BIN
Binary file not shown.
Binary file not shown.
Binary file not shown.
@@ -0,0 +1,14 @@
|
||||
# ExoMy Fritzing project
|
||||
|
||||
This folder contains everything you need to open the ExoMy electronics as a Fritzing project.
|
||||
|
||||
## Exomy.fzz
|
||||
Is the main Project file.
|
||||
|
||||
## Exomy_bin.fzbz
|
||||
The library file that contains all the parts used for the project.
|
||||
|
||||
## parts
|
||||
All the Fritzing pars used in the project. The files are normal archives and can be opened with any archive program, to access the underlying svg files.
|
||||
## exports
|
||||
The exported views of breadboard and schematic as pdf and svg file format.
|
||||
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
+674
@@ -0,0 +1,674 @@
|
||||
GNU GENERAL PUBLIC LICENSE
|
||||
Version 3, 29 June 2007
|
||||
|
||||
Copyright (C) 2007 Free Software Foundation, Inc. <https://fsf.org/>
|
||||
Everyone is permitted to copy and distribute verbatim copies
|
||||
of this license document, but changing it is not allowed.
|
||||
|
||||
Preamble
|
||||
|
||||
The GNU General Public License is a free, copyleft license for
|
||||
software and other kinds of works.
|
||||
|
||||
The licenses for most software and other practical works are designed
|
||||
to take away your freedom to share and change the works. By contrast,
|
||||
the GNU General Public License is intended to guarantee your freedom to
|
||||
share and change all versions of a program--to make sure it remains free
|
||||
software for all its users. We, the Free Software Foundation, use the
|
||||
GNU General Public License for most of our software; it applies also to
|
||||
any other work released this way by its authors. You can apply it to
|
||||
your programs, too.
|
||||
|
||||
When we speak of free software, we are referring to freedom, not
|
||||
price. Our General Public Licenses are designed to make sure that you
|
||||
have the freedom to distribute copies of free software (and charge for
|
||||
them if you wish), that you receive source code or can get it if you
|
||||
want it, that you can change the software or use pieces of it in new
|
||||
free programs, and that you know you can do these things.
|
||||
|
||||
To protect your rights, we need to prevent others from denying you
|
||||
these rights or asking you to surrender the rights. Therefore, you have
|
||||
certain responsibilities if you distribute copies of the software, or if
|
||||
you modify it: responsibilities to respect the freedom of others.
|
||||
|
||||
For example, if you distribute copies of such a program, whether
|
||||
gratis or for a fee, you must pass on to the recipients the same
|
||||
freedoms that you received. You must make sure that they, too, receive
|
||||
or can get the source code. And you must show them these terms so they
|
||||
know their rights.
|
||||
|
||||
Developers that use the GNU GPL protect your rights with two steps:
|
||||
(1) assert copyright on the software, and (2) offer you this License
|
||||
giving you legal permission to copy, distribute and/or modify it.
|
||||
|
||||
For the developers' and authors' protection, the GPL clearly explains
|
||||
that there is no warranty for this free software. For both users' and
|
||||
authors' sake, the GPL requires that modified versions be marked as
|
||||
changed, so that their problems will not be attributed erroneously to
|
||||
authors of previous versions.
|
||||
|
||||
Some devices are designed to deny users access to install or run
|
||||
modified versions of the software inside them, although the manufacturer
|
||||
can do so. This is fundamentally incompatible with the aim of
|
||||
protecting users' freedom to change the software. The systematic
|
||||
pattern of such abuse occurs in the area of products for individuals to
|
||||
use, which is precisely where it is most unacceptable. Therefore, we
|
||||
have designed this version of the GPL to prohibit the practice for those
|
||||
products. If such problems arise substantially in other domains, we
|
||||
stand ready to extend this provision to those domains in future versions
|
||||
of the GPL, as needed to protect the freedom of users.
|
||||
|
||||
Finally, every program is threatened constantly by software patents.
|
||||
States should not allow patents to restrict development and use of
|
||||
software on general-purpose computers, but in those that do, we wish to
|
||||
avoid the special danger that patents applied to a free program could
|
||||
make it effectively proprietary. To prevent this, the GPL assures that
|
||||
patents cannot be used to render the program non-free.
|
||||
|
||||
The precise terms and conditions for copying, distribution and
|
||||
modification follow.
|
||||
|
||||
TERMS AND CONDITIONS
|
||||
|
||||
0. Definitions.
|
||||
|
||||
"This License" refers to version 3 of the GNU General Public License.
|
||||
|
||||
"Copyright" also means copyright-like laws that apply to other kinds of
|
||||
works, such as semiconductor masks.
|
||||
|
||||
"The Program" refers to any copyrightable work licensed under this
|
||||
License. Each licensee is addressed as "you". "Licensees" and
|
||||
"recipients" may be individuals or organizations.
|
||||
|
||||
To "modify" a work means to copy from or adapt all or part of the work
|
||||
in a fashion requiring copyright permission, other than the making of an
|
||||
exact copy. The resulting work is called a "modified version" of the
|
||||
earlier work or a work "based on" the earlier work.
|
||||
|
||||
A "covered work" means either the unmodified Program or a work based
|
||||
on the Program.
|
||||
|
||||
To "propagate" a work means to do anything with it that, without
|
||||
permission, would make you directly or secondarily liable for
|
||||
infringement under applicable copyright law, except executing it on a
|
||||
computer or modifying a private copy. Propagation includes copying,
|
||||
distribution (with or without modification), making available to the
|
||||
public, and in some countries other activities as well.
|
||||
|
||||
To "convey" a work means any kind of propagation that enables other
|
||||
parties to make or receive copies. Mere interaction with a user through
|
||||
a computer network, with no transfer of a copy, is not conveying.
|
||||
|
||||
An interactive user interface displays "Appropriate Legal Notices"
|
||||
to the extent that it includes a convenient and prominently visible
|
||||
feature that (1) displays an appropriate copyright notice, and (2)
|
||||
tells the user that there is no warranty for the work (except to the
|
||||
extent that warranties are provided), that licensees may convey the
|
||||
work under this License, and how to view a copy of this License. If
|
||||
the interface presents a list of user commands or options, such as a
|
||||
menu, a prominent item in the list meets this criterion.
|
||||
|
||||
1. Source Code.
|
||||
|
||||
The "source code" for a work means the preferred form of the work
|
||||
for making modifications to it. "Object code" means any non-source
|
||||
form of a work.
|
||||
|
||||
A "Standard Interface" means an interface that either is an official
|
||||
standard defined by a recognized standards body, or, in the case of
|
||||
interfaces specified for a particular programming language, one that
|
||||
is widely used among developers working in that language.
|
||||
|
||||
The "System Libraries" of an executable work include anything, other
|
||||
than the work as a whole, that (a) is included in the normal form of
|
||||
packaging a Major Component, but which is not part of that Major
|
||||
Component, and (b) serves only to enable use of the work with that
|
||||
Major Component, or to implement a Standard Interface for which an
|
||||
implementation is available to the public in source code form. A
|
||||
"Major Component", in this context, means a major essential component
|
||||
(kernel, window system, and so on) of the specific operating system
|
||||
(if any) on which the executable work runs, or a compiler used to
|
||||
produce the work, or an object code interpreter used to run it.
|
||||
|
||||
The "Corresponding Source" for a work in object code form means all
|
||||
the source code needed to generate, install, and (for an executable
|
||||
work) run the object code and to modify the work, including scripts to
|
||||
control those activities. However, it does not include the work's
|
||||
System Libraries, or general-purpose tools or generally available free
|
||||
programs which are used unmodified in performing those activities but
|
||||
which are not part of the work. For example, Corresponding Source
|
||||
includes interface definition files associated with source files for
|
||||
the work, and the source code for shared libraries and dynamically
|
||||
linked subprograms that the work is specifically designed to require,
|
||||
such as by intimate data communication or control flow between those
|
||||
subprograms and other parts of the work.
|
||||
|
||||
The Corresponding Source need not include anything that users
|
||||
can regenerate automatically from other parts of the Corresponding
|
||||
Source.
|
||||
|
||||
The Corresponding Source for a work in source code form is that
|
||||
same work.
|
||||
|
||||
2. Basic Permissions.
|
||||
|
||||
All rights granted under this License are granted for the term of
|
||||
copyright on the Program, and are irrevocable provided the stated
|
||||
conditions are met. This License explicitly affirms your unlimited
|
||||
permission to run the unmodified Program. The output from running a
|
||||
covered work is covered by this License only if the output, given its
|
||||
content, constitutes a covered work. This License acknowledges your
|
||||
rights of fair use or other equivalent, as provided by copyright law.
|
||||
|
||||
You may make, run and propagate covered works that you do not
|
||||
convey, without conditions so long as your license otherwise remains
|
||||
in force. You may convey covered works to others for the sole purpose
|
||||
of having them make modifications exclusively for you, or provide you
|
||||
with facilities for running those works, provided that you comply with
|
||||
the terms of this License in conveying all material for which you do
|
||||
not control copyright. Those thus making or running the covered works
|
||||
for you must do so exclusively on your behalf, under your direction
|
||||
and control, on terms that prohibit them from making any copies of
|
||||
your copyrighted material outside their relationship with you.
|
||||
|
||||
Conveying under any other circumstances is permitted solely under
|
||||
the conditions stated below. Sublicensing is not allowed; section 10
|
||||
makes it unnecessary.
|
||||
|
||||
3. Protecting Users' Legal Rights From Anti-Circumvention Law.
|
||||
|
||||
No covered work shall be deemed part of an effective technological
|
||||
measure under any applicable law fulfilling obligations under article
|
||||
11 of the WIPO copyright treaty adopted on 20 December 1996, or
|
||||
similar laws prohibiting or restricting circumvention of such
|
||||
measures.
|
||||
|
||||
When you convey a covered work, you waive any legal power to forbid
|
||||
circumvention of technological measures to the extent such circumvention
|
||||
is effected by exercising rights under this License with respect to
|
||||
the covered work, and you disclaim any intention to limit operation or
|
||||
modification of the work as a means of enforcing, against the work's
|
||||
users, your or third parties' legal rights to forbid circumvention of
|
||||
technological measures.
|
||||
|
||||
4. Conveying Verbatim Copies.
|
||||
|
||||
You may convey verbatim copies of the Program's source code as you
|
||||
receive it, in any medium, provided that you conspicuously and
|
||||
appropriately publish on each copy an appropriate copyright notice;
|
||||
keep intact all notices stating that this License and any
|
||||
non-permissive terms added in accord with section 7 apply to the code;
|
||||
keep intact all notices of the absence of any warranty; and give all
|
||||
recipients a copy of this License along with the Program.
|
||||
|
||||
You may charge any price or no price for each copy that you convey,
|
||||
and you may offer support or warranty protection for a fee.
|
||||
|
||||
5. Conveying Modified Source Versions.
|
||||
|
||||
You may convey a work based on the Program, or the modifications to
|
||||
produce it from the Program, in the form of source code under the
|
||||
terms of section 4, provided that you also meet all of these conditions:
|
||||
|
||||
a) The work must carry prominent notices stating that you modified
|
||||
it, and giving a relevant date.
|
||||
|
||||
b) The work must carry prominent notices stating that it is
|
||||
released under this License and any conditions added under section
|
||||
7. This requirement modifies the requirement in section 4 to
|
||||
"keep intact all notices".
|
||||
|
||||
c) You must license the entire work, as a whole, under this
|
||||
License to anyone who comes into possession of a copy. This
|
||||
License will therefore apply, along with any applicable section 7
|
||||
additional terms, to the whole of the work, and all its parts,
|
||||
regardless of how they are packaged. This License gives no
|
||||
permission to license the work in any other way, but it does not
|
||||
invalidate such permission if you have separately received it.
|
||||
|
||||
d) If the work has interactive user interfaces, each must display
|
||||
Appropriate Legal Notices; however, if the Program has interactive
|
||||
interfaces that do not display Appropriate Legal Notices, your
|
||||
work need not make them do so.
|
||||
|
||||
A compilation of a covered work with other separate and independent
|
||||
works, which are not by their nature extensions of the covered work,
|
||||
and which are not combined with it such as to form a larger program,
|
||||
in or on a volume of a storage or distribution medium, is called an
|
||||
"aggregate" if the compilation and its resulting copyright are not
|
||||
used to limit the access or legal rights of the compilation's users
|
||||
beyond what the individual works permit. Inclusion of a covered work
|
||||
in an aggregate does not cause this License to apply to the other
|
||||
parts of the aggregate.
|
||||
|
||||
6. Conveying Non-Source Forms.
|
||||
|
||||
You may convey a covered work in object code form under the terms
|
||||
of sections 4 and 5, provided that you also convey the
|
||||
machine-readable Corresponding Source under the terms of this License,
|
||||
in one of these ways:
|
||||
|
||||
a) Convey the object code in, or embodied in, a physical product
|
||||
(including a physical distribution medium), accompanied by the
|
||||
Corresponding Source fixed on a durable physical medium
|
||||
customarily used for software interchange.
|
||||
|
||||
b) Convey the object code in, or embodied in, a physical product
|
||||
(including a physical distribution medium), accompanied by a
|
||||
written offer, valid for at least three years and valid for as
|
||||
long as you offer spare parts or customer support for that product
|
||||
model, to give anyone who possesses the object code either (1) a
|
||||
copy of the Corresponding Source for all the software in the
|
||||
product that is covered by this License, on a durable physical
|
||||
medium customarily used for software interchange, for a price no
|
||||
more than your reasonable cost of physically performing this
|
||||
conveying of source, or (2) access to copy the
|
||||
Corresponding Source from a network server at no charge.
|
||||
|
||||
c) Convey individual copies of the object code with a copy of the
|
||||
written offer to provide the Corresponding Source. This
|
||||
alternative is allowed only occasionally and noncommercially, and
|
||||
only if you received the object code with such an offer, in accord
|
||||
with subsection 6b.
|
||||
|
||||
d) Convey the object code by offering access from a designated
|
||||
place (gratis or for a charge), and offer equivalent access to the
|
||||
Corresponding Source in the same way through the same place at no
|
||||
further charge. You need not require recipients to copy the
|
||||
Corresponding Source along with the object code. If the place to
|
||||
copy the object code is a network server, the Corresponding Source
|
||||
may be on a different server (operated by you or a third party)
|
||||
that supports equivalent copying facilities, provided you maintain
|
||||
clear directions next to the object code saying where to find the
|
||||
Corresponding Source. Regardless of what server hosts the
|
||||
Corresponding Source, you remain obligated to ensure that it is
|
||||
available for as long as needed to satisfy these requirements.
|
||||
|
||||
e) Convey the object code using peer-to-peer transmission, provided
|
||||
you inform other peers where the object code and Corresponding
|
||||
Source of the work are being offered to the general public at no
|
||||
charge under subsection 6d.
|
||||
|
||||
A separable portion of the object code, whose source code is excluded
|
||||
from the Corresponding Source as a System Library, need not be
|
||||
included in conveying the object code work.
|
||||
|
||||
A "User Product" is either (1) a "consumer product", which means any
|
||||
tangible personal property which is normally used for personal, family,
|
||||
or household purposes, or (2) anything designed or sold for incorporation
|
||||
into a dwelling. In determining whether a product is a consumer product,
|
||||
doubtful cases shall be resolved in favor of coverage. For a particular
|
||||
product received by a particular user, "normally used" refers to a
|
||||
typical or common use of that class of product, regardless of the status
|
||||
of the particular user or of the way in which the particular user
|
||||
actually uses, or expects or is expected to use, the product. A product
|
||||
is a consumer product regardless of whether the product has substantial
|
||||
commercial, industrial or non-consumer uses, unless such uses represent
|
||||
the only significant mode of use of the product.
|
||||
|
||||
"Installation Information" for a User Product means any methods,
|
||||
procedures, authorization keys, or other information required to install
|
||||
and execute modified versions of a covered work in that User Product from
|
||||
a modified version of its Corresponding Source. The information must
|
||||
suffice to ensure that the continued functioning of the modified object
|
||||
code is in no case prevented or interfered with solely because
|
||||
modification has been made.
|
||||
|
||||
If you convey an object code work under this section in, or with, or
|
||||
specifically for use in, a User Product, and the conveying occurs as
|
||||
part of a transaction in which the right of possession and use of the
|
||||
User Product is transferred to the recipient in perpetuity or for a
|
||||
fixed term (regardless of how the transaction is characterized), the
|
||||
Corresponding Source conveyed under this section must be accompanied
|
||||
by the Installation Information. But this requirement does not apply
|
||||
if neither you nor any third party retains the ability to install
|
||||
modified object code on the User Product (for example, the work has
|
||||
been installed in ROM).
|
||||
|
||||
The requirement to provide Installation Information does not include a
|
||||
requirement to continue to provide support service, warranty, or updates
|
||||
for a work that has been modified or installed by the recipient, or for
|
||||
the User Product in which it has been modified or installed. Access to a
|
||||
network may be denied when the modification itself materially and
|
||||
adversely affects the operation of the network or violates the rules and
|
||||
protocols for communication across the network.
|
||||
|
||||
Corresponding Source conveyed, and Installation Information provided,
|
||||
in accord with this section must be in a format that is publicly
|
||||
documented (and with an implementation available to the public in
|
||||
source code form), and must require no special password or key for
|
||||
unpacking, reading or copying.
|
||||
|
||||
7. Additional Terms.
|
||||
|
||||
"Additional permissions" are terms that supplement the terms of this
|
||||
License by making exceptions from one or more of its conditions.
|
||||
Additional permissions that are applicable to the entire Program shall
|
||||
be treated as though they were included in this License, to the extent
|
||||
that they are valid under applicable law. If additional permissions
|
||||
apply only to part of the Program, that part may be used separately
|
||||
under those permissions, but the entire Program remains governed by
|
||||
this License without regard to the additional permissions.
|
||||
|
||||
When you convey a copy of a covered work, you may at your option
|
||||
remove any additional permissions from that copy, or from any part of
|
||||
it. (Additional permissions may be written to require their own
|
||||
removal in certain cases when you modify the work.) You may place
|
||||
additional permissions on material, added by you to a covered work,
|
||||
for which you have or can give appropriate copyright permission.
|
||||
|
||||
Notwithstanding any other provision of this License, for material you
|
||||
add to a covered work, you may (if authorized by the copyright holders of
|
||||
that material) supplement the terms of this License with terms:
|
||||
|
||||
a) Disclaiming warranty or limiting liability differently from the
|
||||
terms of sections 15 and 16 of this License; or
|
||||
|
||||
b) Requiring preservation of specified reasonable legal notices or
|
||||
author attributions in that material or in the Appropriate Legal
|
||||
Notices displayed by works containing it; or
|
||||
|
||||
c) Prohibiting misrepresentation of the origin of that material, or
|
||||
requiring that modified versions of such material be marked in
|
||||
reasonable ways as different from the original version; or
|
||||
|
||||
d) Limiting the use for publicity purposes of names of licensors or
|
||||
authors of the material; or
|
||||
|
||||
e) Declining to grant rights under trademark law for use of some
|
||||
trade names, trademarks, or service marks; or
|
||||
|
||||
f) Requiring indemnification of licensors and authors of that
|
||||
material by anyone who conveys the material (or modified versions of
|
||||
it) with contractual assumptions of liability to the recipient, for
|
||||
any liability that these contractual assumptions directly impose on
|
||||
those licensors and authors.
|
||||
|
||||
All other non-permissive additional terms are considered "further
|
||||
restrictions" within the meaning of section 10. If the Program as you
|
||||
received it, or any part of it, contains a notice stating that it is
|
||||
governed by this License along with a term that is a further
|
||||
restriction, you may remove that term. If a license document contains
|
||||
a further restriction but permits relicensing or conveying under this
|
||||
License, you may add to a covered work material governed by the terms
|
||||
of that license document, provided that the further restriction does
|
||||
not survive such relicensing or conveying.
|
||||
|
||||
If you add terms to a covered work in accord with this section, you
|
||||
must place, in the relevant source files, a statement of the
|
||||
additional terms that apply to those files, or a notice indicating
|
||||
where to find the applicable terms.
|
||||
|
||||
Additional terms, permissive or non-permissive, may be stated in the
|
||||
form of a separately written license, or stated as exceptions;
|
||||
the above requirements apply either way.
|
||||
|
||||
8. Termination.
|
||||
|
||||
You may not propagate or modify a covered work except as expressly
|
||||
provided under this License. Any attempt otherwise to propagate or
|
||||
modify it is void, and will automatically terminate your rights under
|
||||
this License (including any patent licenses granted under the third
|
||||
paragraph of section 11).
|
||||
|
||||
However, if you cease all violation of this License, then your
|
||||
license from a particular copyright holder is reinstated (a)
|
||||
provisionally, unless and until the copyright holder explicitly and
|
||||
finally terminates your license, and (b) permanently, if the copyright
|
||||
holder fails to notify you of the violation by some reasonable means
|
||||
prior to 60 days after the cessation.
|
||||
|
||||
Moreover, your license from a particular copyright holder is
|
||||
reinstated permanently if the copyright holder notifies you of the
|
||||
violation by some reasonable means, this is the first time you have
|
||||
received notice of violation of this License (for any work) from that
|
||||
copyright holder, and you cure the violation prior to 30 days after
|
||||
your receipt of the notice.
|
||||
|
||||
Termination of your rights under this section does not terminate the
|
||||
licenses of parties who have received copies or rights from you under
|
||||
this License. If your rights have been terminated and not permanently
|
||||
reinstated, you do not qualify to receive new licenses for the same
|
||||
material under section 10.
|
||||
|
||||
9. Acceptance Not Required for Having Copies.
|
||||
|
||||
You are not required to accept this License in order to receive or
|
||||
run a copy of the Program. Ancillary propagation of a covered work
|
||||
occurring solely as a consequence of using peer-to-peer transmission
|
||||
to receive a copy likewise does not require acceptance. However,
|
||||
nothing other than this License grants you permission to propagate or
|
||||
modify any covered work. These actions infringe copyright if you do
|
||||
not accept this License. Therefore, by modifying or propagating a
|
||||
covered work, you indicate your acceptance of this License to do so.
|
||||
|
||||
10. Automatic Licensing of Downstream Recipients.
|
||||
|
||||
Each time you convey a covered work, the recipient automatically
|
||||
receives a license from the original licensors, to run, modify and
|
||||
propagate that work, subject to this License. You are not responsible
|
||||
for enforcing compliance by third parties with this License.
|
||||
|
||||
An "entity transaction" is a transaction transferring control of an
|
||||
organization, or substantially all assets of one, or subdividing an
|
||||
organization, or merging organizations. If propagation of a covered
|
||||
work results from an entity transaction, each party to that
|
||||
transaction who receives a copy of the work also receives whatever
|
||||
licenses to the work the party's predecessor in interest had or could
|
||||
give under the previous paragraph, plus a right to possession of the
|
||||
Corresponding Source of the work from the predecessor in interest, if
|
||||
the predecessor has it or can get it with reasonable efforts.
|
||||
|
||||
You may not impose any further restrictions on the exercise of the
|
||||
rights granted or affirmed under this License. For example, you may
|
||||
not impose a license fee, royalty, or other charge for exercise of
|
||||
rights granted under this License, and you may not initiate litigation
|
||||
(including a cross-claim or counterclaim in a lawsuit) alleging that
|
||||
any patent claim is infringed by making, using, selling, offering for
|
||||
sale, or importing the Program or any portion of it.
|
||||
|
||||
11. Patents.
|
||||
|
||||
A "contributor" is a copyright holder who authorizes use under this
|
||||
License of the Program or a work on which the Program is based. The
|
||||
work thus licensed is called the contributor's "contributor version".
|
||||
|
||||
A contributor's "essential patent claims" are all patent claims
|
||||
owned or controlled by the contributor, whether already acquired or
|
||||
hereafter acquired, that would be infringed by some manner, permitted
|
||||
by this License, of making, using, or selling its contributor version,
|
||||
but do not include claims that would be infringed only as a
|
||||
consequence of further modification of the contributor version. For
|
||||
purposes of this definition, "control" includes the right to grant
|
||||
patent sublicenses in a manner consistent with the requirements of
|
||||
this License.
|
||||
|
||||
Each contributor grants you a non-exclusive, worldwide, royalty-free
|
||||
patent license under the contributor's essential patent claims, to
|
||||
make, use, sell, offer for sale, import and otherwise run, modify and
|
||||
propagate the contents of its contributor version.
|
||||
|
||||
In the following three paragraphs, a "patent license" is any express
|
||||
agreement or commitment, however denominated, not to enforce a patent
|
||||
(such as an express permission to practice a patent or covenant not to
|
||||
sue for patent infringement). To "grant" such a patent license to a
|
||||
party means to make such an agreement or commitment not to enforce a
|
||||
patent against the party.
|
||||
|
||||
If you convey a covered work, knowingly relying on a patent license,
|
||||
and the Corresponding Source of the work is not available for anyone
|
||||
to copy, free of charge and under the terms of this License, through a
|
||||
publicly available network server or other readily accessible means,
|
||||
then you must either (1) cause the Corresponding Source to be so
|
||||
available, or (2) arrange to deprive yourself of the benefit of the
|
||||
patent license for this particular work, or (3) arrange, in a manner
|
||||
consistent with the requirements of this License, to extend the patent
|
||||
license to downstream recipients. "Knowingly relying" means you have
|
||||
actual knowledge that, but for the patent license, your conveying the
|
||||
covered work in a country, or your recipient's use of the covered work
|
||||
in a country, would infringe one or more identifiable patents in that
|
||||
country that you have reason to believe are valid.
|
||||
|
||||
If, pursuant to or in connection with a single transaction or
|
||||
arrangement, you convey, or propagate by procuring conveyance of, a
|
||||
covered work, and grant a patent license to some of the parties
|
||||
receiving the covered work authorizing them to use, propagate, modify
|
||||
or convey a specific copy of the covered work, then the patent license
|
||||
you grant is automatically extended to all recipients of the covered
|
||||
work and works based on it.
|
||||
|
||||
A patent license is "discriminatory" if it does not include within
|
||||
the scope of its coverage, prohibits the exercise of, or is
|
||||
conditioned on the non-exercise of one or more of the rights that are
|
||||
specifically granted under this License. You may not convey a covered
|
||||
work if you are a party to an arrangement with a third party that is
|
||||
in the business of distributing software, under which you make payment
|
||||
to the third party based on the extent of your activity of conveying
|
||||
the work, and under which the third party grants, to any of the
|
||||
parties who would receive the covered work from you, a discriminatory
|
||||
patent license (a) in connection with copies of the covered work
|
||||
conveyed by you (or copies made from those copies), or (b) primarily
|
||||
for and in connection with specific products or compilations that
|
||||
contain the covered work, unless you entered into that arrangement,
|
||||
or that patent license was granted, prior to 28 March 2007.
|
||||
|
||||
Nothing in this License shall be construed as excluding or limiting
|
||||
any implied license or other defenses to infringement that may
|
||||
otherwise be available to you under applicable patent law.
|
||||
|
||||
12. No Surrender of Others' Freedom.
|
||||
|
||||
If conditions are imposed on you (whether by court order, agreement or
|
||||
otherwise) that contradict the conditions of this License, they do not
|
||||
excuse you from the conditions of this License. If you cannot convey a
|
||||
covered work so as to satisfy simultaneously your obligations under this
|
||||
License and any other pertinent obligations, then as a consequence you may
|
||||
not convey it at all. For example, if you agree to terms that obligate you
|
||||
to collect a royalty for further conveying from those to whom you convey
|
||||
the Program, the only way you could satisfy both those terms and this
|
||||
License would be to refrain entirely from conveying the Program.
|
||||
|
||||
13. Use with the GNU Affero General Public License.
|
||||
|
||||
Notwithstanding any other provision of this License, you have
|
||||
permission to link or combine any covered work with a work licensed
|
||||
under version 3 of the GNU Affero General Public License into a single
|
||||
combined work, and to convey the resulting work. The terms of this
|
||||
License will continue to apply to the part which is the covered work,
|
||||
but the special requirements of the GNU Affero General Public License,
|
||||
section 13, concerning interaction through a network will apply to the
|
||||
combination as such.
|
||||
|
||||
14. Revised Versions of this License.
|
||||
|
||||
The Free Software Foundation may publish revised and/or new versions of
|
||||
the GNU General Public License from time to time. Such new versions will
|
||||
be similar in spirit to the present version, but may differ in detail to
|
||||
address new problems or concerns.
|
||||
|
||||
Each version is given a distinguishing version number. If the
|
||||
Program specifies that a certain numbered version of the GNU General
|
||||
Public License "or any later version" applies to it, you have the
|
||||
option of following the terms and conditions either of that numbered
|
||||
version or of any later version published by the Free Software
|
||||
Foundation. If the Program does not specify a version number of the
|
||||
GNU General Public License, you may choose any version ever published
|
||||
by the Free Software Foundation.
|
||||
|
||||
If the Program specifies that a proxy can decide which future
|
||||
versions of the GNU General Public License can be used, that proxy's
|
||||
public statement of acceptance of a version permanently authorizes you
|
||||
to choose that version for the Program.
|
||||
|
||||
Later license versions may give you additional or different
|
||||
permissions. However, no additional obligations are imposed on any
|
||||
author or copyright holder as a result of your choosing to follow a
|
||||
later version.
|
||||
|
||||
15. Disclaimer of Warranty.
|
||||
|
||||
THERE IS NO WARRANTY FOR THE PROGRAM, TO THE EXTENT PERMITTED BY
|
||||
APPLICABLE LAW. EXCEPT WHEN OTHERWISE STATED IN WRITING THE COPYRIGHT
|
||||
HOLDERS AND/OR OTHER PARTIES PROVIDE THE PROGRAM "AS IS" WITHOUT WARRANTY
|
||||
OF ANY KIND, EITHER EXPRESSED OR IMPLIED, INCLUDING, BUT NOT LIMITED TO,
|
||||
THE IMPLIED WARRANTIES OF MERCHANTABILITY AND FITNESS FOR A PARTICULAR
|
||||
PURPOSE. THE ENTIRE RISK AS TO THE QUALITY AND PERFORMANCE OF THE PROGRAM
|
||||
IS WITH YOU. SHOULD THE PROGRAM PROVE DEFECTIVE, YOU ASSUME THE COST OF
|
||||
ALL NECESSARY SERVICING, REPAIR OR CORRECTION.
|
||||
|
||||
16. Limitation of Liability.
|
||||
|
||||
IN NO EVENT UNLESS REQUIRED BY APPLICABLE LAW OR AGREED TO IN WRITING
|
||||
WILL ANY COPYRIGHT HOLDER, OR ANY OTHER PARTY WHO MODIFIES AND/OR CONVEYS
|
||||
THE PROGRAM AS PERMITTED ABOVE, BE LIABLE TO YOU FOR DAMAGES, INCLUDING ANY
|
||||
GENERAL, SPECIAL, INCIDENTAL OR CONSEQUENTIAL DAMAGES ARISING OUT OF THE
|
||||
USE OR INABILITY TO USE THE PROGRAM (INCLUDING BUT NOT LIMITED TO LOSS OF
|
||||
DATA OR DATA BEING RENDERED INACCURATE OR LOSSES SUSTAINED BY YOU OR THIRD
|
||||
PARTIES OR A FAILURE OF THE PROGRAM TO OPERATE WITH ANY OTHER PROGRAMS),
|
||||
EVEN IF SUCH HOLDER OR OTHER PARTY HAS BEEN ADVISED OF THE POSSIBILITY OF
|
||||
SUCH DAMAGES.
|
||||
|
||||
17. Interpretation of Sections 15 and 16.
|
||||
|
||||
If the disclaimer of warranty and limitation of liability provided
|
||||
above cannot be given local legal effect according to their terms,
|
||||
reviewing courts shall apply local law that most closely approximates
|
||||
an absolute waiver of all civil liability in connection with the
|
||||
Program, unless a warranty or assumption of liability accompanies a
|
||||
copy of the Program in return for a fee.
|
||||
|
||||
END OF TERMS AND CONDITIONS
|
||||
|
||||
How to Apply These Terms to Your New Programs
|
||||
|
||||
If you develop a new program, and you want it to be of the greatest
|
||||
possible use to the public, the best way to achieve this is to make it
|
||||
free software which everyone can redistribute and change under these terms.
|
||||
|
||||
To do so, attach the following notices to the program. It is safest
|
||||
to attach them to the start of each source file to most effectively
|
||||
state the exclusion of warranty; and each file should have at least
|
||||
the "copyright" line and a pointer to where the full notice is found.
|
||||
|
||||
<one line to give the program's name and a brief idea of what it does.>
|
||||
Copyright (C) <year> <name of author>
|
||||
|
||||
This program is free software: you can redistribute it and/or modify
|
||||
it under the terms of the GNU General Public License as published by
|
||||
the Free Software Foundation, either version 3 of the License, or
|
||||
(at your option) any later version.
|
||||
|
||||
This program is distributed in the hope that it will be useful,
|
||||
but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||
MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||
GNU General Public License for more details.
|
||||
|
||||
You should have received a copy of the GNU General Public License
|
||||
along with this program. If not, see <https://www.gnu.org/licenses/>.
|
||||
|
||||
Also add information on how to contact you by electronic and paper mail.
|
||||
|
||||
If the program does terminal interaction, make it output a short
|
||||
notice like this when it starts in an interactive mode:
|
||||
|
||||
<program> Copyright (C) <year> <name of author>
|
||||
This program comes with ABSOLUTELY NO WARRANTY; for details type `show w'.
|
||||
This is free software, and you are welcome to redistribute it
|
||||
under certain conditions; type `show c' for details.
|
||||
|
||||
The hypothetical commands `show w' and `show c' should show the appropriate
|
||||
parts of the General Public License. Of course, your program's commands
|
||||
might be different; for a GUI interface, you would use an "about box".
|
||||
|
||||
You should also get your employer (if you work as a programmer) or school,
|
||||
if any, to sign a "copyright disclaimer" for the program, if necessary.
|
||||
For more information on this, and how to apply and follow the GNU GPL, see
|
||||
<https://www.gnu.org/licenses/>.
|
||||
|
||||
The GNU General Public License does not permit incorporating your program
|
||||
into proprietary programs. If your program is a subroutine library, you
|
||||
may consider it more useful to permit linking proprietary applications with
|
||||
the library. If this is what you want to do, use the GNU Lesser General
|
||||
Public License instead of this License. But first, please read
|
||||
<https://www.gnu.org/licenses/why-not-lgpl.html>.
|
||||
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
Binary file not shown.
@@ -0,0 +1 @@
|
||||
https://de.misumi-ec.com/vona2/detail/221000551163/
|
||||
@@ -0,0 +1 @@
|
||||
https://de.misumi-ec.com/vona2/detail/110300241010/
|
||||
Binary file not shown.
@@ -0,0 +1,27 @@
|
||||
README by Miro Voellmy 10.02.2020
|
||||
|
||||
Use this folder as a collection for commonly used screws.
|
||||
|
||||
!!!DO NOT RENAME SCREWS OR FOLDERS!!!
|
||||
!!!Otherwise assemblies, that use the screws will brake!!!
|
||||
|
||||
How to add screws:
|
||||
1.
|
||||
Go to link specified in folder (Socket, Button, etc):
|
||||
|
||||
OR
|
||||
Find a new screw type from:
|
||||
https://de.misumi-ec.com/
|
||||
|
||||
OR
|
||||
Model it yourself
|
||||
|
||||
(1.5)
|
||||
Create new folder for screw type and document link, as done in the other folders.
|
||||
|
||||
2.
|
||||
Find fitting screw.
|
||||
Screws manufactured by MISUMI are preferred. The resulting CAD file can be generated and will be much smaller as it contains a parasolid instead of all the SolidWorks features.
|
||||
|
||||
3.
|
||||
Download CAD (with account) and put the single *.SLDPRT file into the fitting location.
|
||||
Binary file not shown.
Some files were not shown because too many files have changed in this diff Show More
Reference in New Issue
Block a user